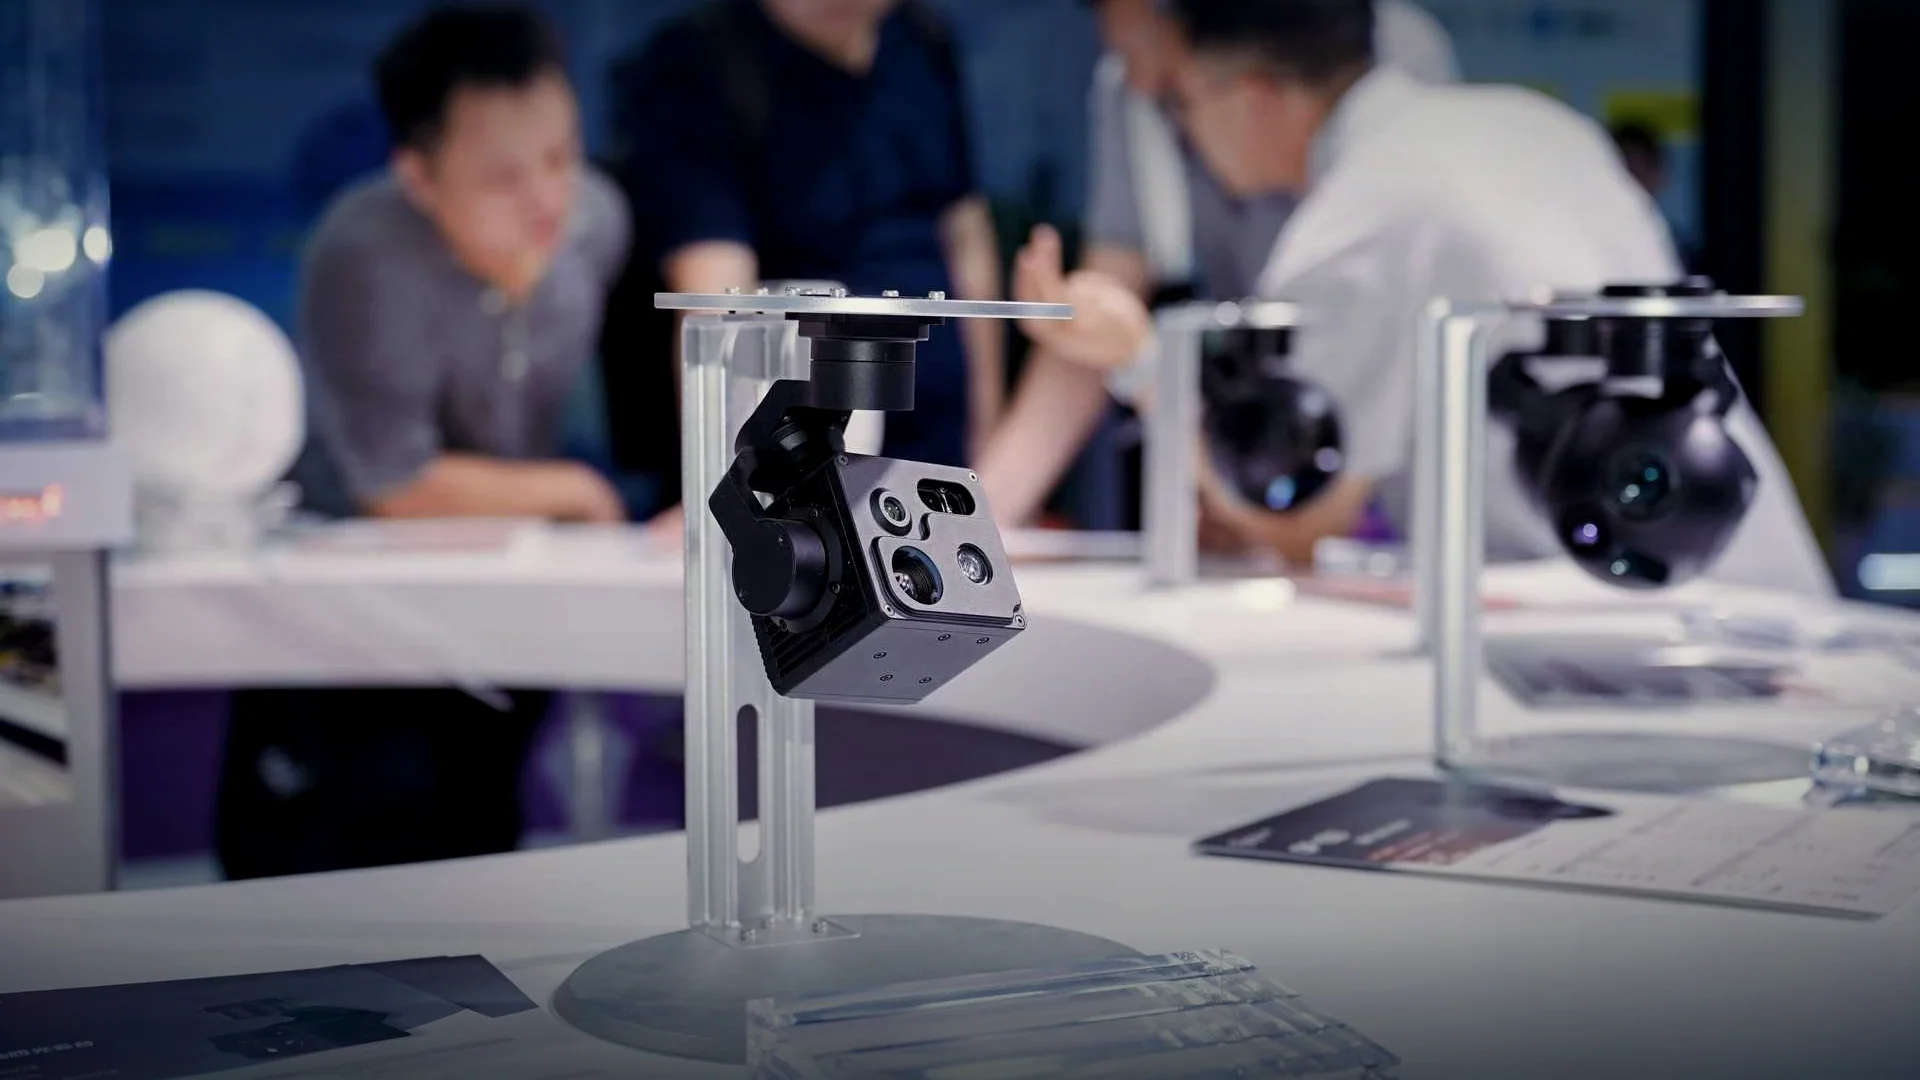
HQ-85Q two-axis gimbal camera with 3 km LRF
Category: 2-Axis Gimbal Cameras
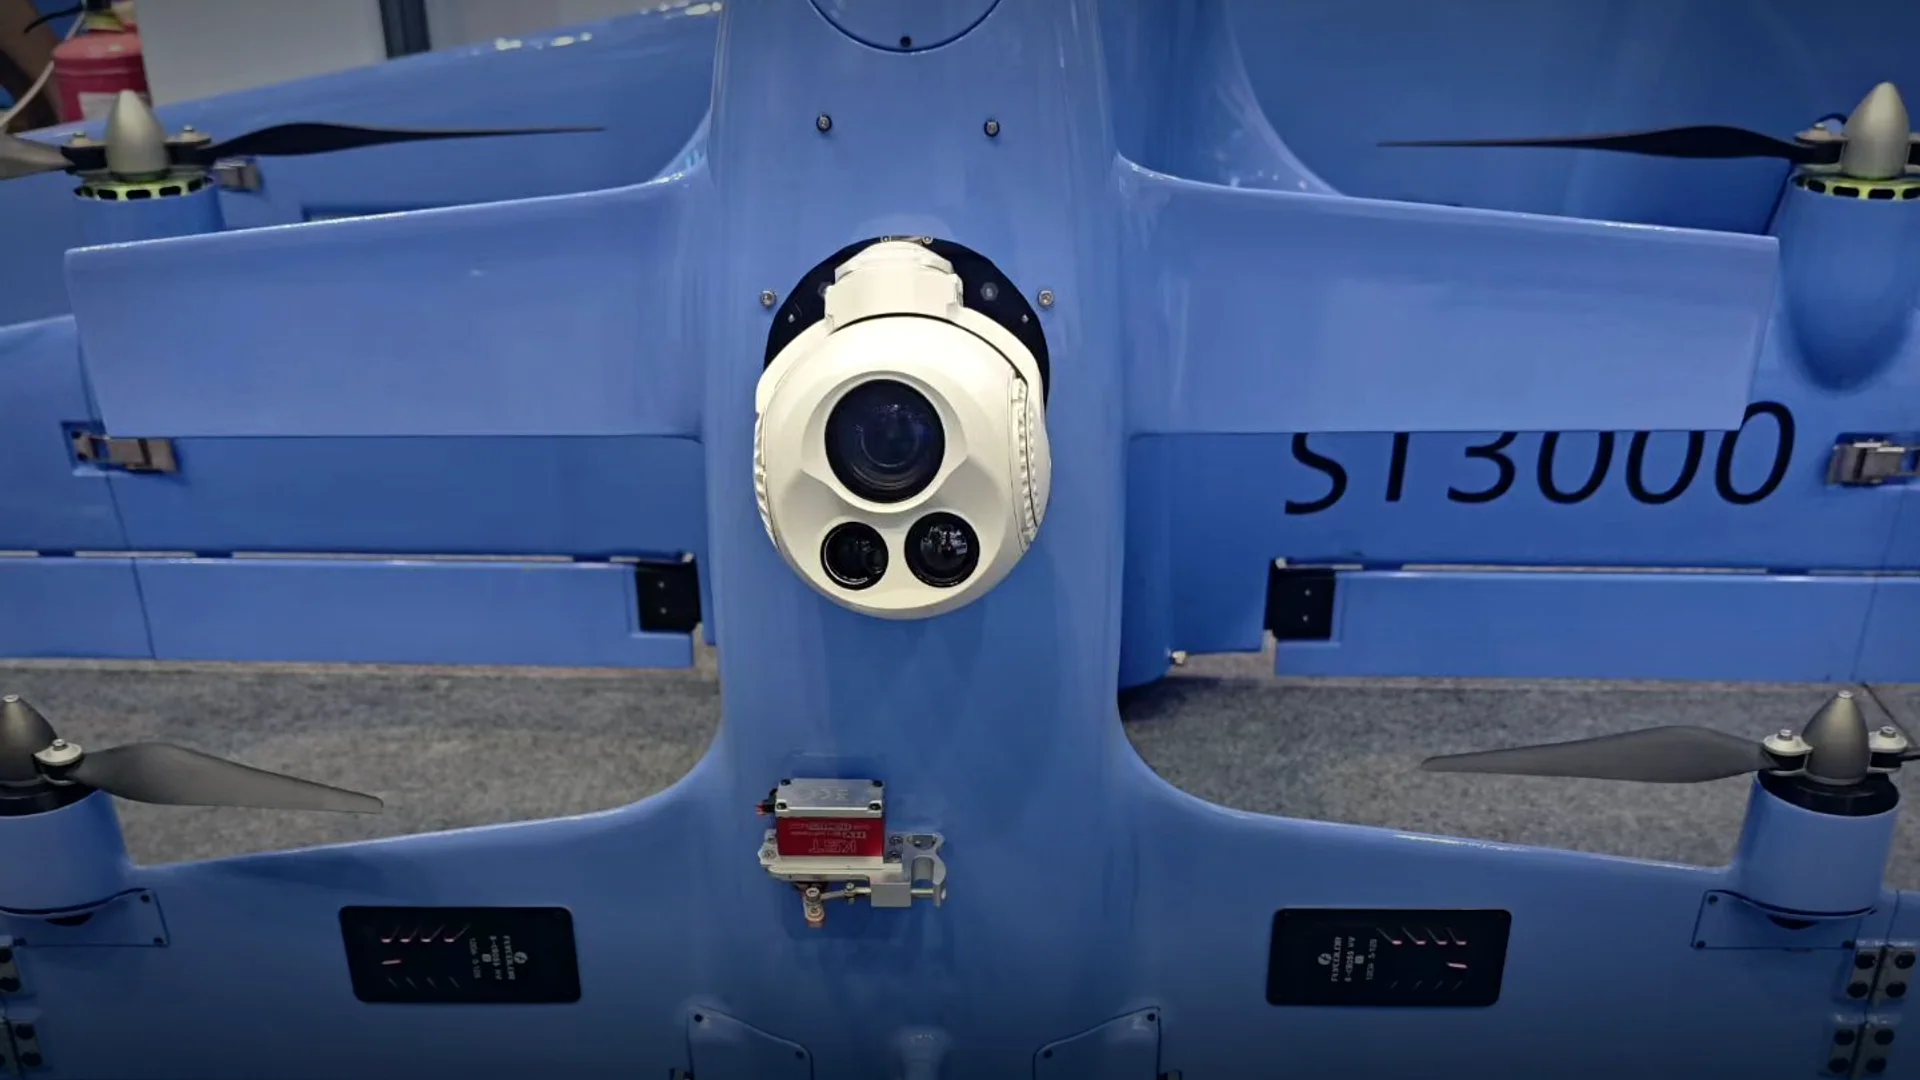
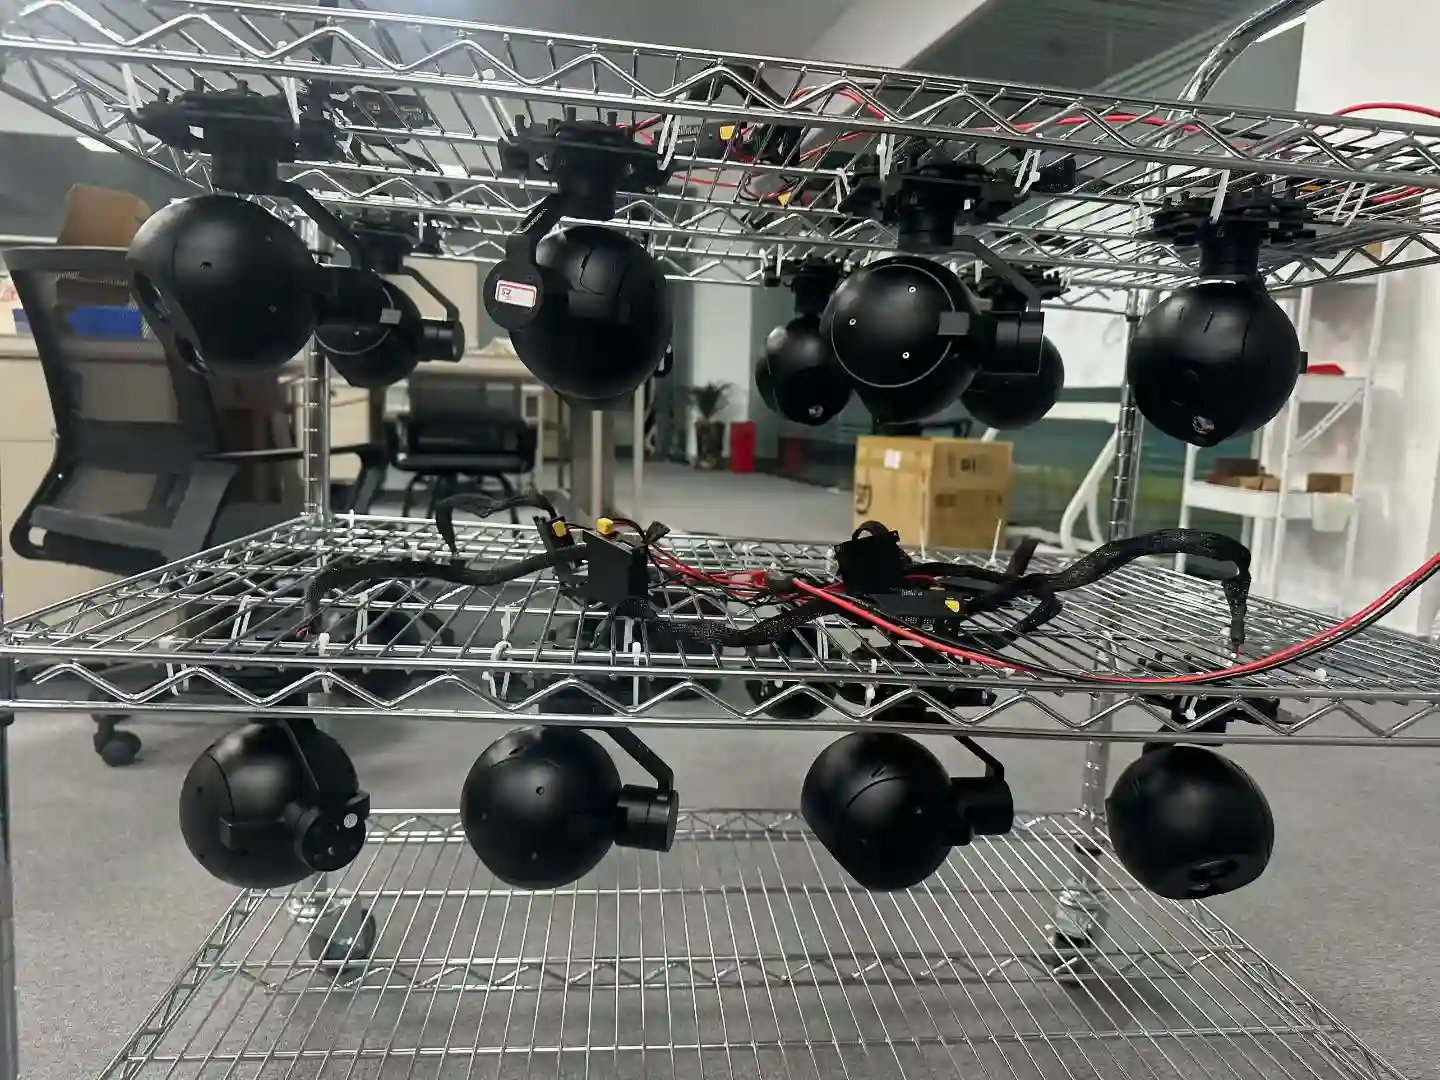
A two-axis gimbal camera that packages EO (electro-optical), IR, LRF into a 500 g head measuring Φ85 × 110 mm. Adds 3 km laser ranging to a two-axis platform for crews that need coordinates, not just imagery.
- Weight 500 g
- Two-axis stabilised
- EO Dual 1920 × 1080
- Thermal 640 × 512
- LRF 15 m – 3 km (± 1 m)
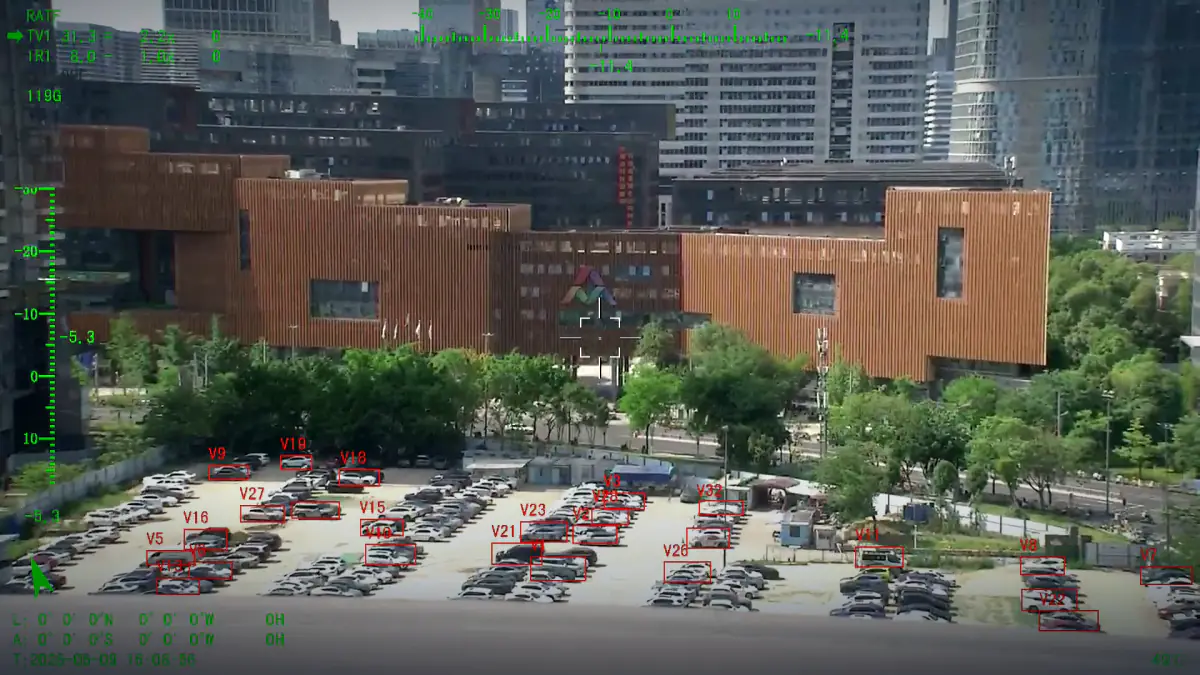
- AI detection & tracking
- CE / RoHS documentation available on request
- Export compliance statement available on request
- Calibration and test report supplied with every unit
What the HQ-85Q is
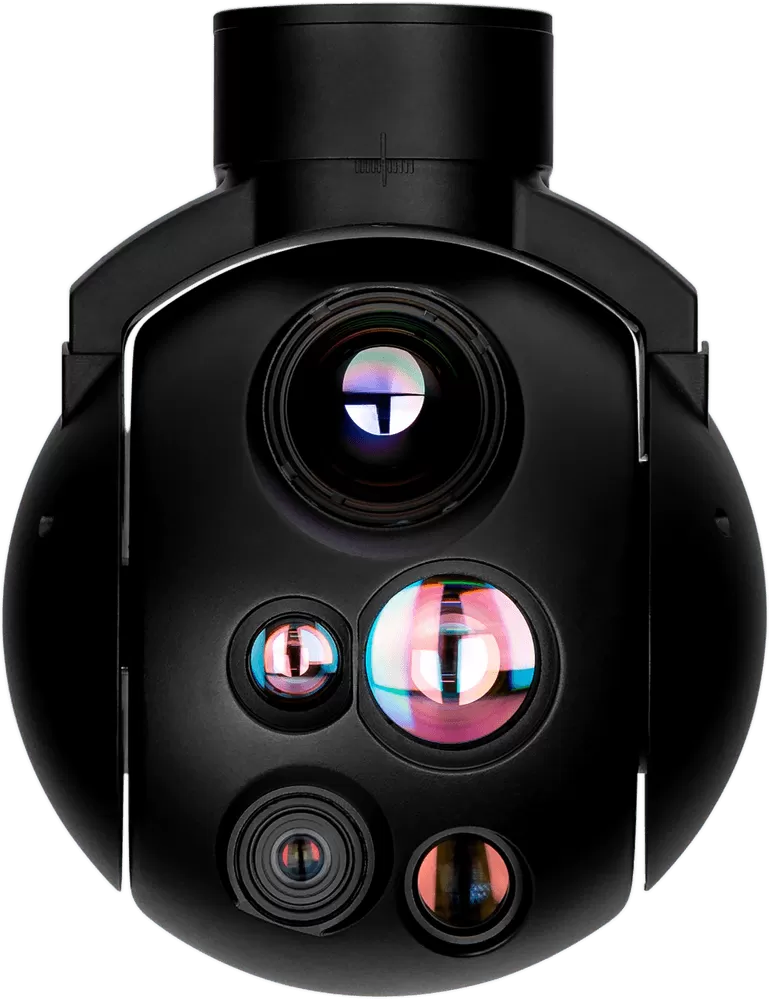
The HQ-85Q puts four things in a 500 g two-axis head: daylight lenses at 8 mm and 25 mm, a 640 × 512 thermal core on 25 mm, and a rangefinder reaching 3 km. The envelope is Φ85 × 110 mm and the draw is 20 W / 50 W. The bet behind the layout is that a crew working a nearby object wants coordinates more than it wants a long lens. Daylight detection is 0.34 km on a person and 2.1 km on a vehicle, thermal is 0.7 km and 3.1 km, and the laser converts either contact into a distance the ground station can turn into a position.
Two daylight fields, one thermal frame, one laser
Each channel answers a different question; the rangefinder answers with a number.
EO / visible
Dual 1920 × 1080, 8 mm + 25 mm
0.34 km person, 2.1 km vehicle, on either lens.
Thermal / IR
640 × 512, 25 mm fixed
0.7 km person, 3.1 km vehicle. Uncooled LWIR, NETD ≤ 40 mK.
Laser rangefinder
15 m – 3 km (± 1 m)
Eye-safe. Readings feed the coordinate solution, not just the display.
Switching between 8 mm and 25 mm
Two separate groups, not a zoom, so the change is a switch with no travel to sit through while a target moves. 8 mm holds a wide field for the approach and for keeping the aircraft clear of what it is watching; 25 mm puts a longer focal length on the same spot. Detection is quoted once for the pair at 0.34 km on a person and 2.1 km on a vehicle, and that short figure is honest: this head reads what is close, it does not find what is far.
3 km of ranging on a two-axis mount
15 m – 3 km at ± 1 m from a head weighing half a kilogram. The near end makes it useful on a structure: a mast or a gantry at 15 m is a valid target, not an error. Two axes suffice: aircraft attitude supplies the geometry, the head keeps the spot on target.
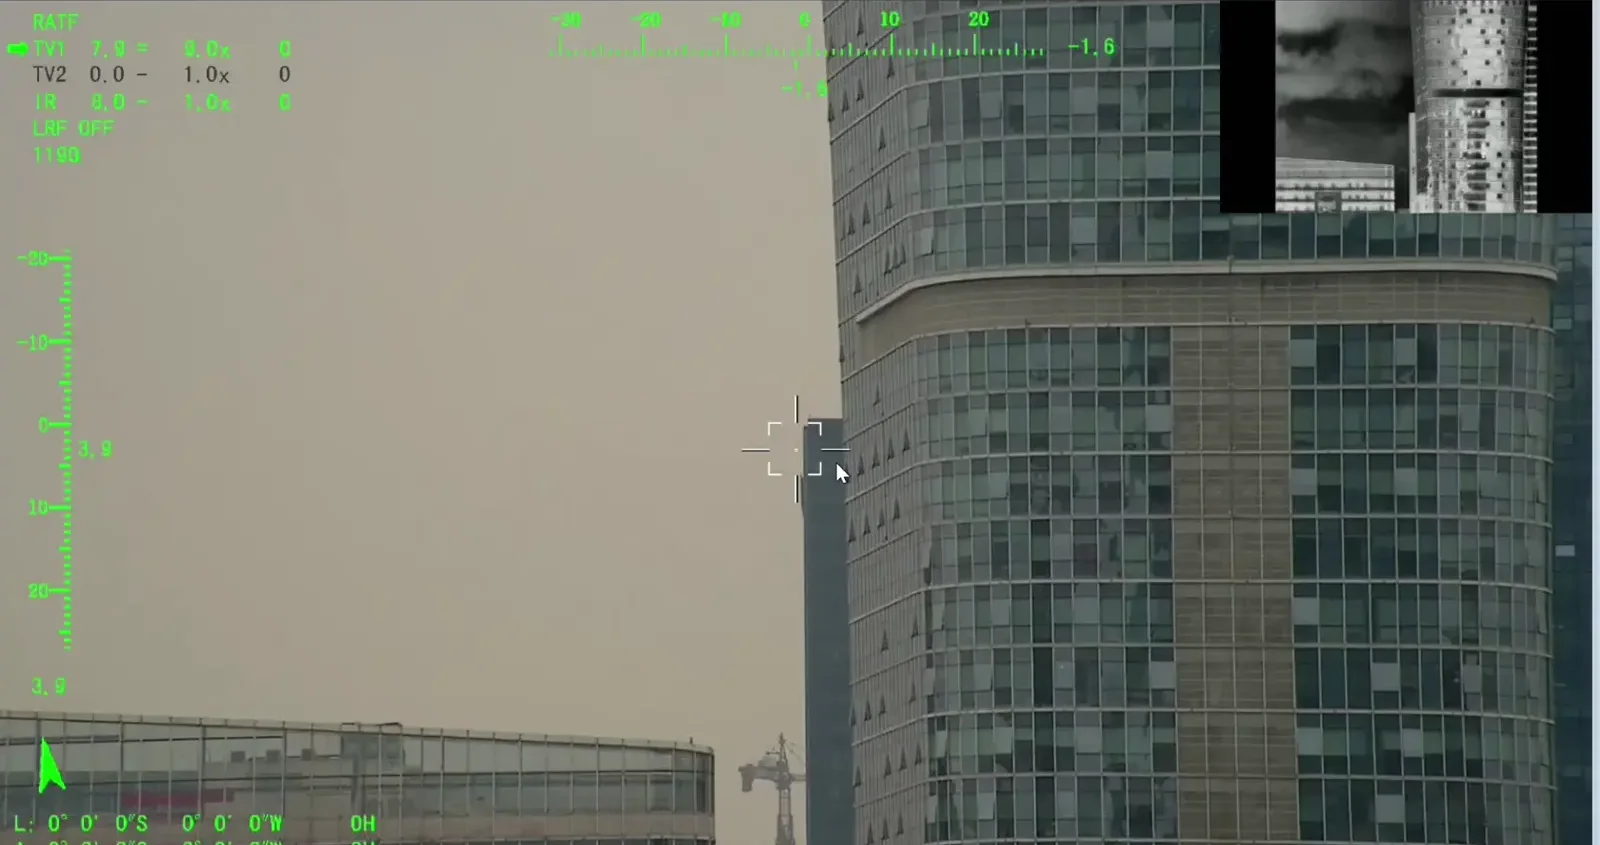
The thermal core that carries the night
640 × 512 behind 25 mm, uncooled, aligned to the daylight pair so a contact found after dark lands where it sits in the daytime frame.
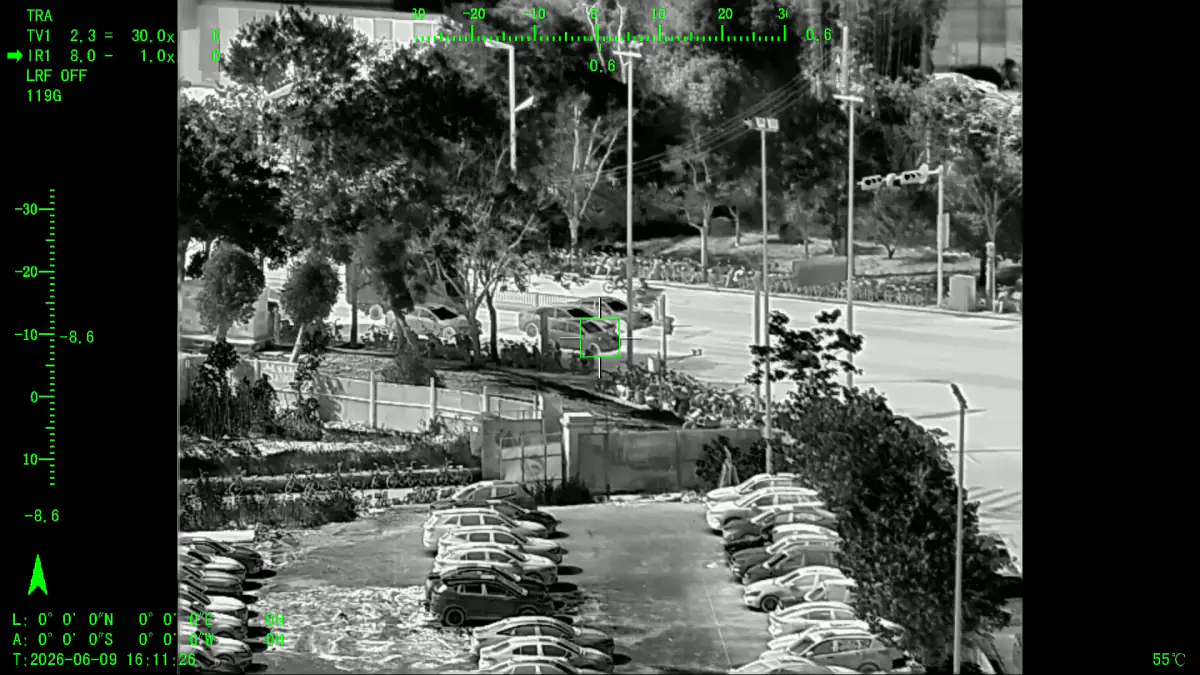
Daylight searches, thermal takes the night pass, and the laser turns either of them into something a map can record.
Stabilisation and mechanical design
Two axes on 500 g
Pitch and yaw are stabilised on direct-drive brushless motors with high-resolution encoding and no gear train between motor and frame. Roll is delegated to the aircraft, which is what keeps the head at 500 g with three sensors inside. Boresight holds to ≤ 100 μrad (1σ) and the loop accepts ≥ 60°/s before it runs out of authority.
Φ85 × 110 mm, 20 W / 50 W
The envelope is Φ85 × 110 mm. The head takes 11–28 VDC and draws 20 W / 50 W. Both figures are catalogue limits rather than targets, so the mount and the power budget can be fixed before a prototype exists to measure.
Detection and tracking at the edge
Autonomy inside the turret
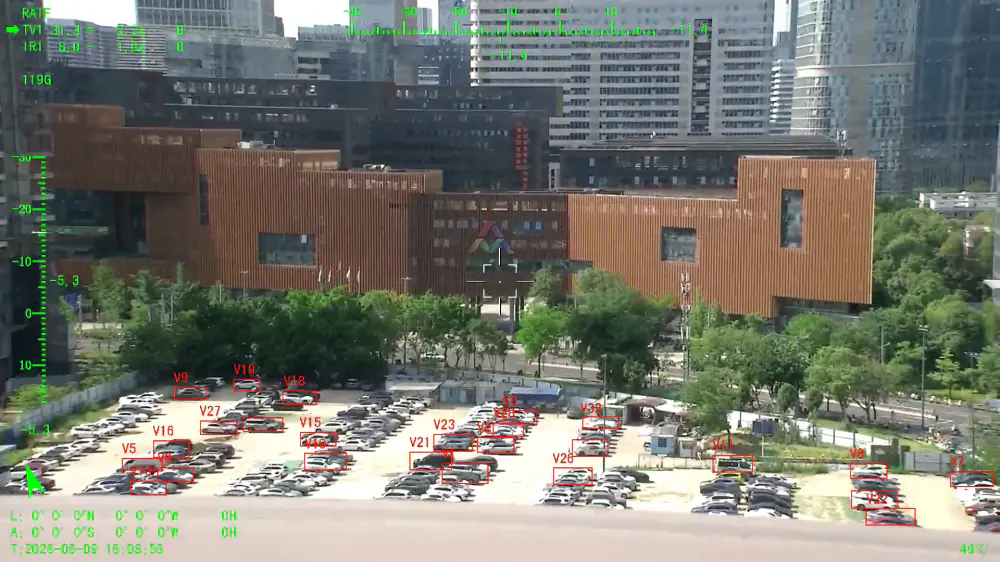
The classifier sits on the payload, not on a ground machine. That keeps bounding boxes live when throughput drops and leaves the aircraft without a second computer to power. Twenty tracks can run at once, with one under active lock.
Where the laser meets the tracker
The lock is what the rangefinder is pointed at, and a target that slips behind a mast is re-acquired by anti-occlusion logic rather than dropped. Ranging and recording both continue through a link failure, so a coordinate measured on a bad pass is still in the log afterwards.
Airframe integration
Half a kilogram and three sensors: what the aircraft supplies and what arrives in the box.
Mount
Quick-release face on a vibration-isolated base, plus adapter plates where the bolt circle differs. Φ85 × 110 mm and 500 g are the numbers the bracket is drawn against, and at that mass a small multirotor or a hand-launched airframe takes it without a dedicated hard point.
Electrical and video
11–28 VDC in; RS-422, RS-232 or TTL for commands, SBUS or MAVLink at the autopilot; H.264 or H.265 over 100 Mbps Ethernet into 128 GB on board; dust and rotor-wash sealing; −20 °C to +60 °C running, −40 °C to +70 °C stored. This is the range layer, set out on the technology pages rather than repeated model by model.
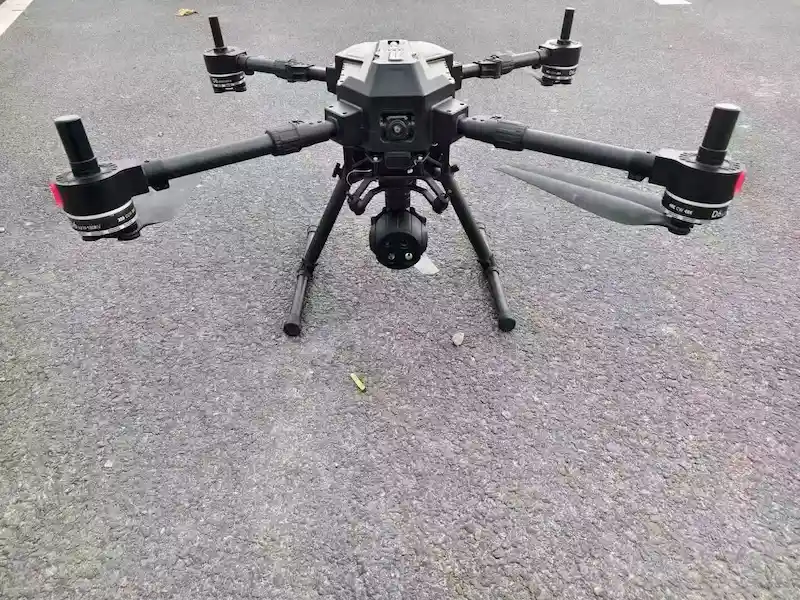
On the aircraft
Half a kilogram on a small multirotor. One harness carries power, commands and video; the mount takes the vibration.
The crate for the maiden head holds five papers: control protocol, video pipeline note, three-view outline with connector pinout, calibration record and test report. Export screening treats paper and hardware alike.
Where the HQ-85Q is used
Three tasks where 3 km of ranging matters more than a long focal length.
- Structure and mast inspection
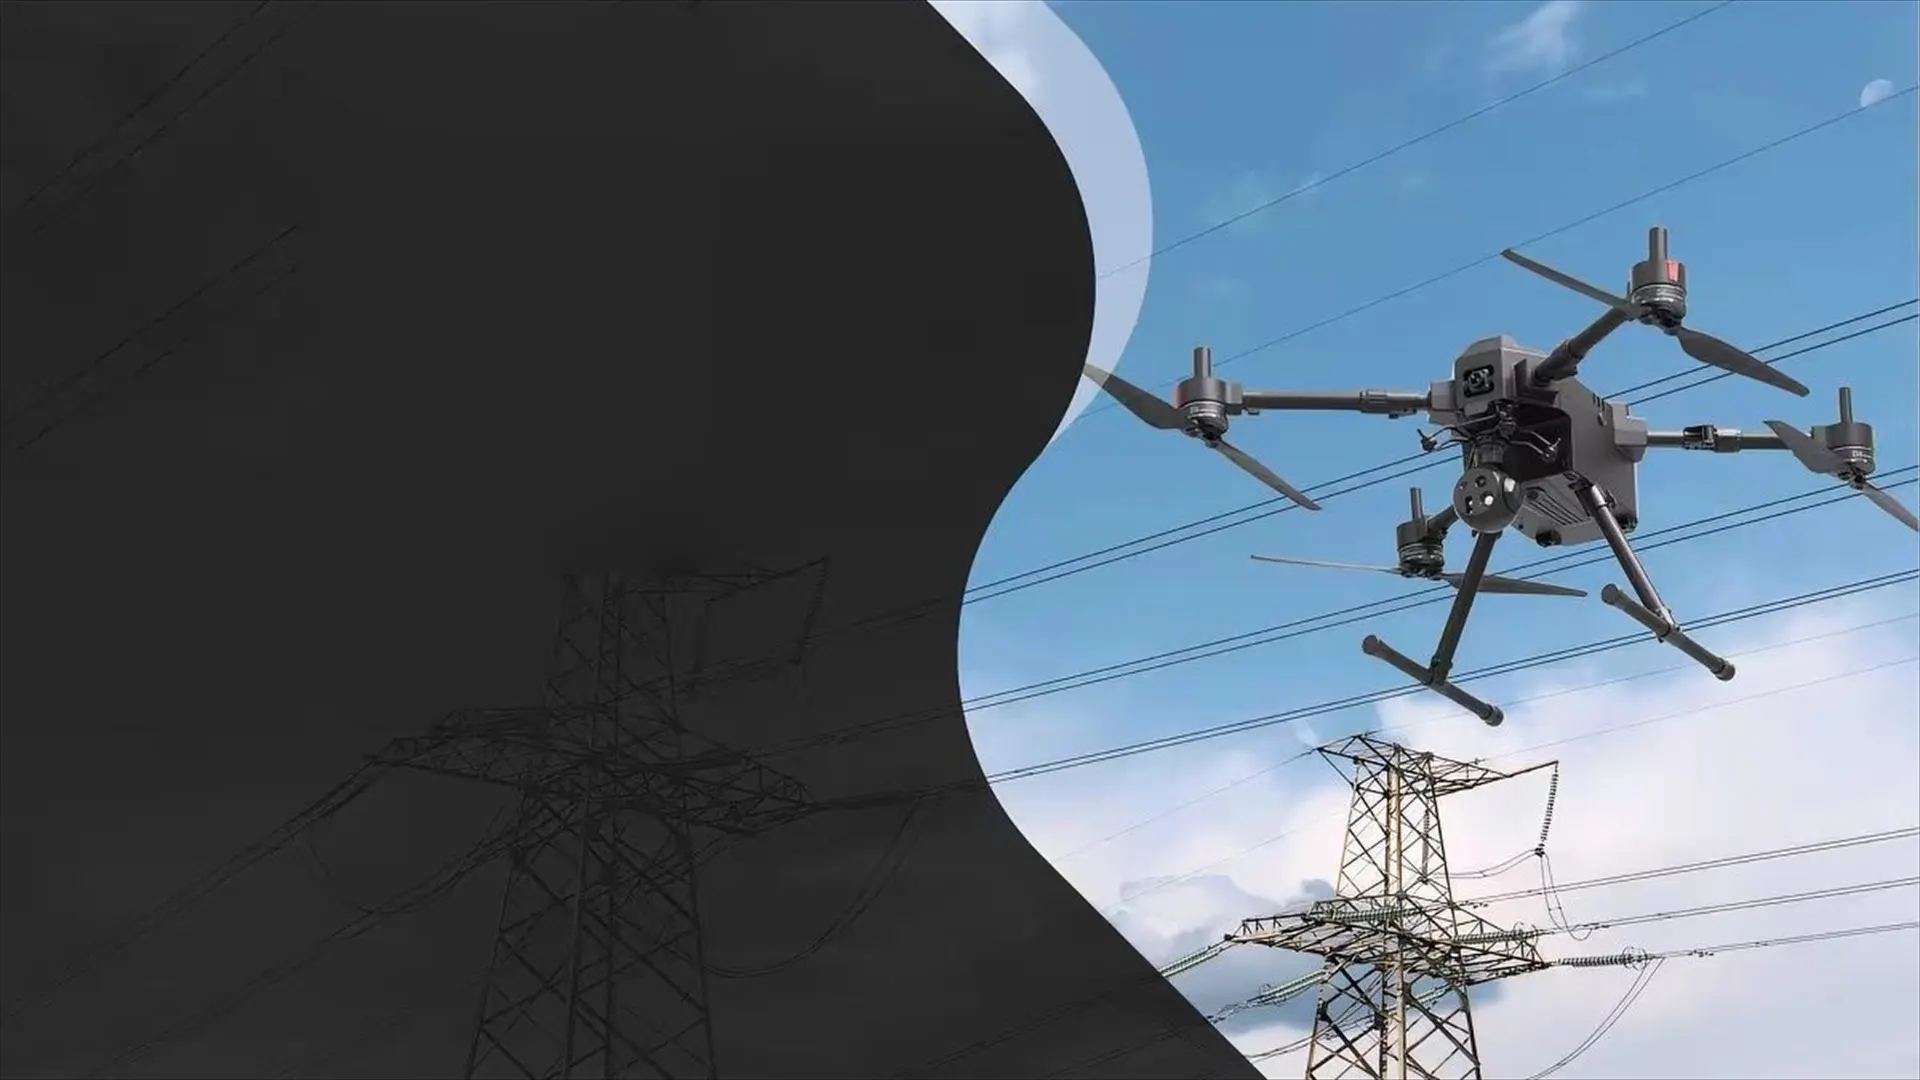
Most of what a mast or gantry crew measures sits within a few hundred metres, and the number that has to be right is the distance. The 8 mm lens frames the structure, 25 mm reads a fitting, and the 15 m – 3 km rangefinder puts a measured distance on a joint without a second pass. At 500 g the aircraft can hold station close enough for the near end of that range to be useful.
- Compound and site security
A site perimeter is a close problem: a person at 0.7 km on the thermal is already inside the area a guard needs to know about. The thermal core covers the dark hours, the 25 mm lens supplies detail once a contact is flagged, and the laser turns a sighting at a fence line into a position another team can drive to.
- Incident georeferencing
First responders need a position as much as a description. A contact picked up on either imaging channel can be ranged at ± 1 m out to 3 km and handed on as a coordinate, which is a different product from a timestamped picture. Two axes suffice because the head only keeps the laser spot on the target while aircraft attitude supplies the rest.
Full specifications
| Model | HQ-85Q |
| Series | Gimbal Camera Series (HQ series) |
| Stabilisation | Two-axis gyro-stabilised, ≤ 100 μrad |
| Sensor configuration | EO + IR + LRF |
| Visible channel | Dual 1920 × 1080, 8 mm + 25 mm |
| Thermal channel | 640 × 512, 25 mm fixed |
| Laser rangefinder | 15 m – 3 km (± 1 m) |
| Weight | ≤500 g |
| Dimensions | ≤Φ85 × 110 mm |
| Power consumption | 20 W / 50 W |
| Detection (EO) | 0.34 km person / 2.1 km vehicle |
| Detection (IR) | 0.7 km person / 3.1 km vehicle |
Detection distances follow the standard 1.7 m person / 2.3 m vehicle convention. Rows marked as shared are common across the HQ series.
Control software: Windows as standard. An Android version can be customised for OEM/ODM projects.
Shared across the HQ series
- Video output: Ethernet, H.264 / H.265
- Gimbal control: RS-422 / RS-232 / TTL, SBUS, MAVLink
- Input voltage: 11–28 VDC
- Operating temperature: −20 °C to +60 °C
- Sealing: Sealed housing for dust, wind and rotor wash
- Recording: On-board recording, imagery retained if the link drops
- AI module: Onboard detection, classification and multi-target tracking
- Mounting: Quick-release interface, adapters available for OEM (original equipment manufacturer) airframes
Three-view outline drawing with connector pinout, available on request.
Other 2-axis gimbal cameras
Two compact two-axis heads for airframes with limited payload space. The control protocol and the video path are the same as the rest of the range.
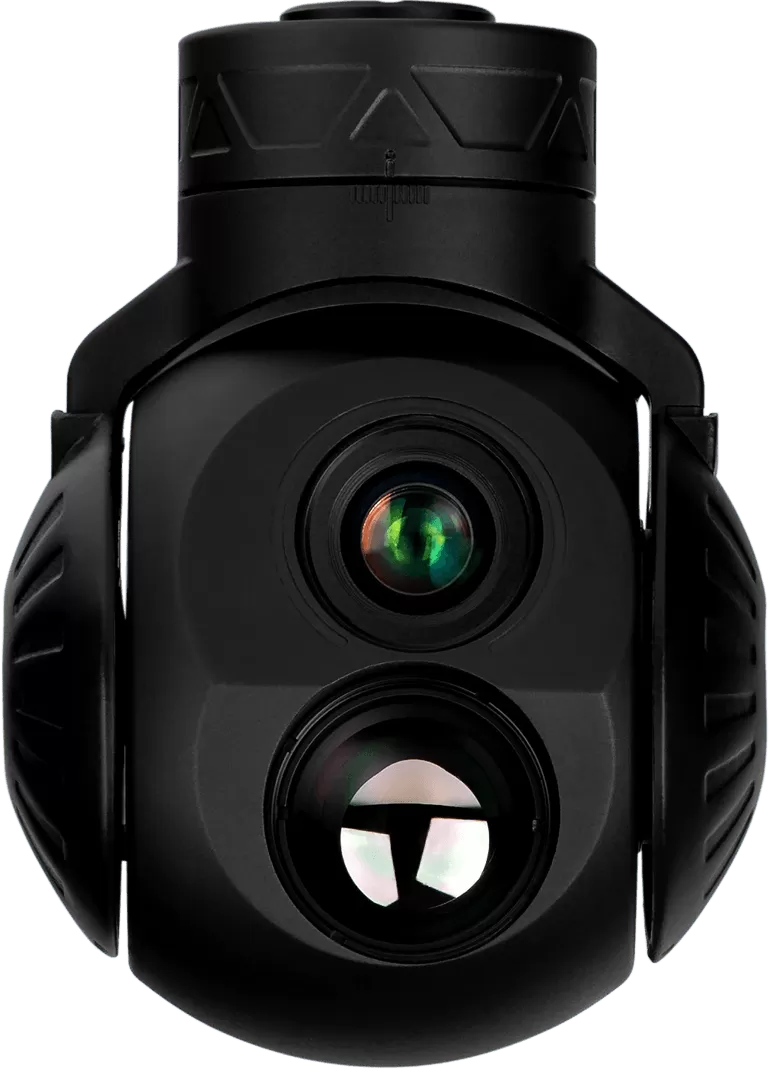
HQ series · 2-axis · EO + IR
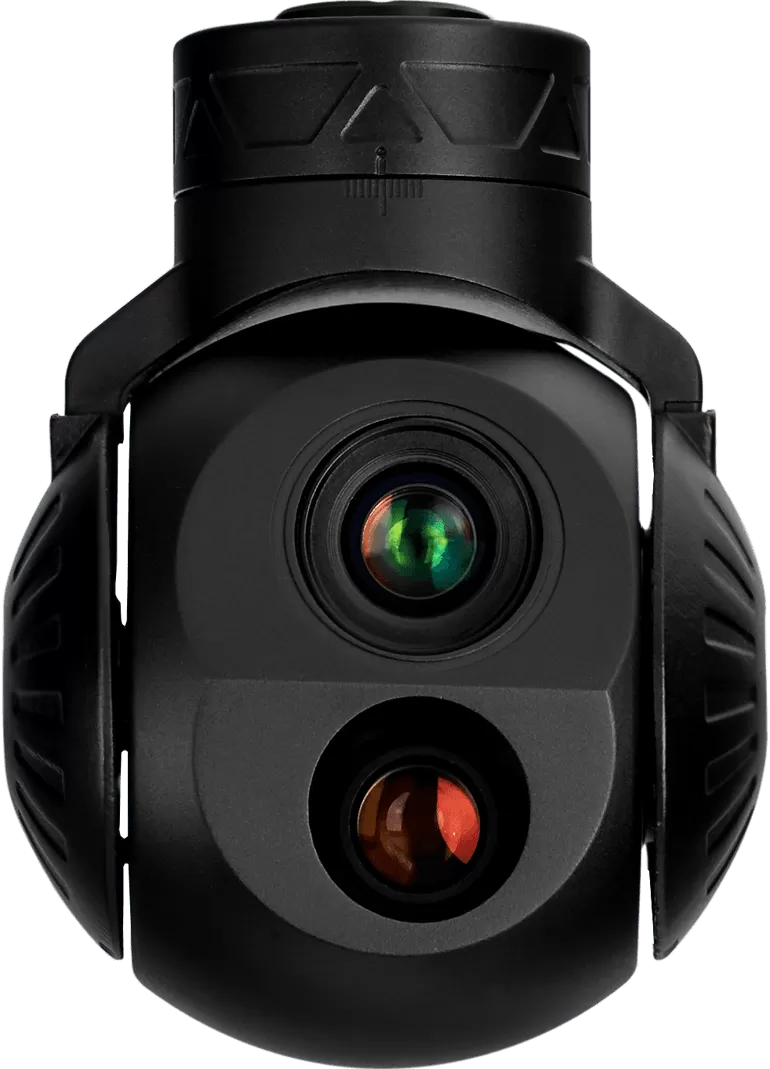
HQ-64DA UAV Camera Gimbal OEM
The lightest dual-sensor head in the range — 2K daylight plus thermal on 260 g.
- Weight
- ≤260 g
- Visible
- 2688 × 1520, 8.5 mm fixed
- Thermal
- 640 × 512, 19 mm fixed
HQ series · 2-axis · EO
HQ-64DB Drone Camera Payload OEM
Two fixed visible cameras — a wide and a narrow channel — at the lowest weight in the series.
- Weight
- ≤240 g
- Visible
- Dual 2688 × 1520, 8.5 mm + 25 mm
- Thermal
- —
Questions engineers ask about the HQ-85Q
At what range does the HQ-85Q detect a target?
The daylight pair reaches 0.34 km to a person and 2.1 km to a vehicle; the thermal core reaches 0.7 km and 3.1 km. Those follow the standard 1.7 m person and 2.3 m vehicle targets, and recognition or identification requires closing in; the datasheet carries the shorter figures.
What are the order terms and the delivery time?
Stock configurations begin at a single unit and custom ones at 100. A head held in stock leaves the shelf as it is, so the calendar is transport time; a bespoke or volume batch gets its date in the quotation, which is also where the T/T terms sit. Warranty runs one year from delivery.
Do the two daylight lenses share one sensor?
No, they are separate 1920 × 1080 arrays behind 8 mm and 25 mm groups. Two fixed optics behave like a switch: no travel to lose a target in, nothing to drift under vibration, and the narrow view changes focal length rather than image quality. A zoom barrel would cost mass and volume on a 500 g head already carrying a thermal core and a laser.
What does 3 km of ranging give a two-axis head?
A coordinate. The rangefinder runs 15 m – 3 km at ± 1 m, eye-safe at 1535 nm, and the reading feeds the calculation instead of staying a number drawn on the video. Pitch and yaw keep the spot on the target; aircraft attitude supplies the rest of the geometry.
Designed and manufactured by HITS
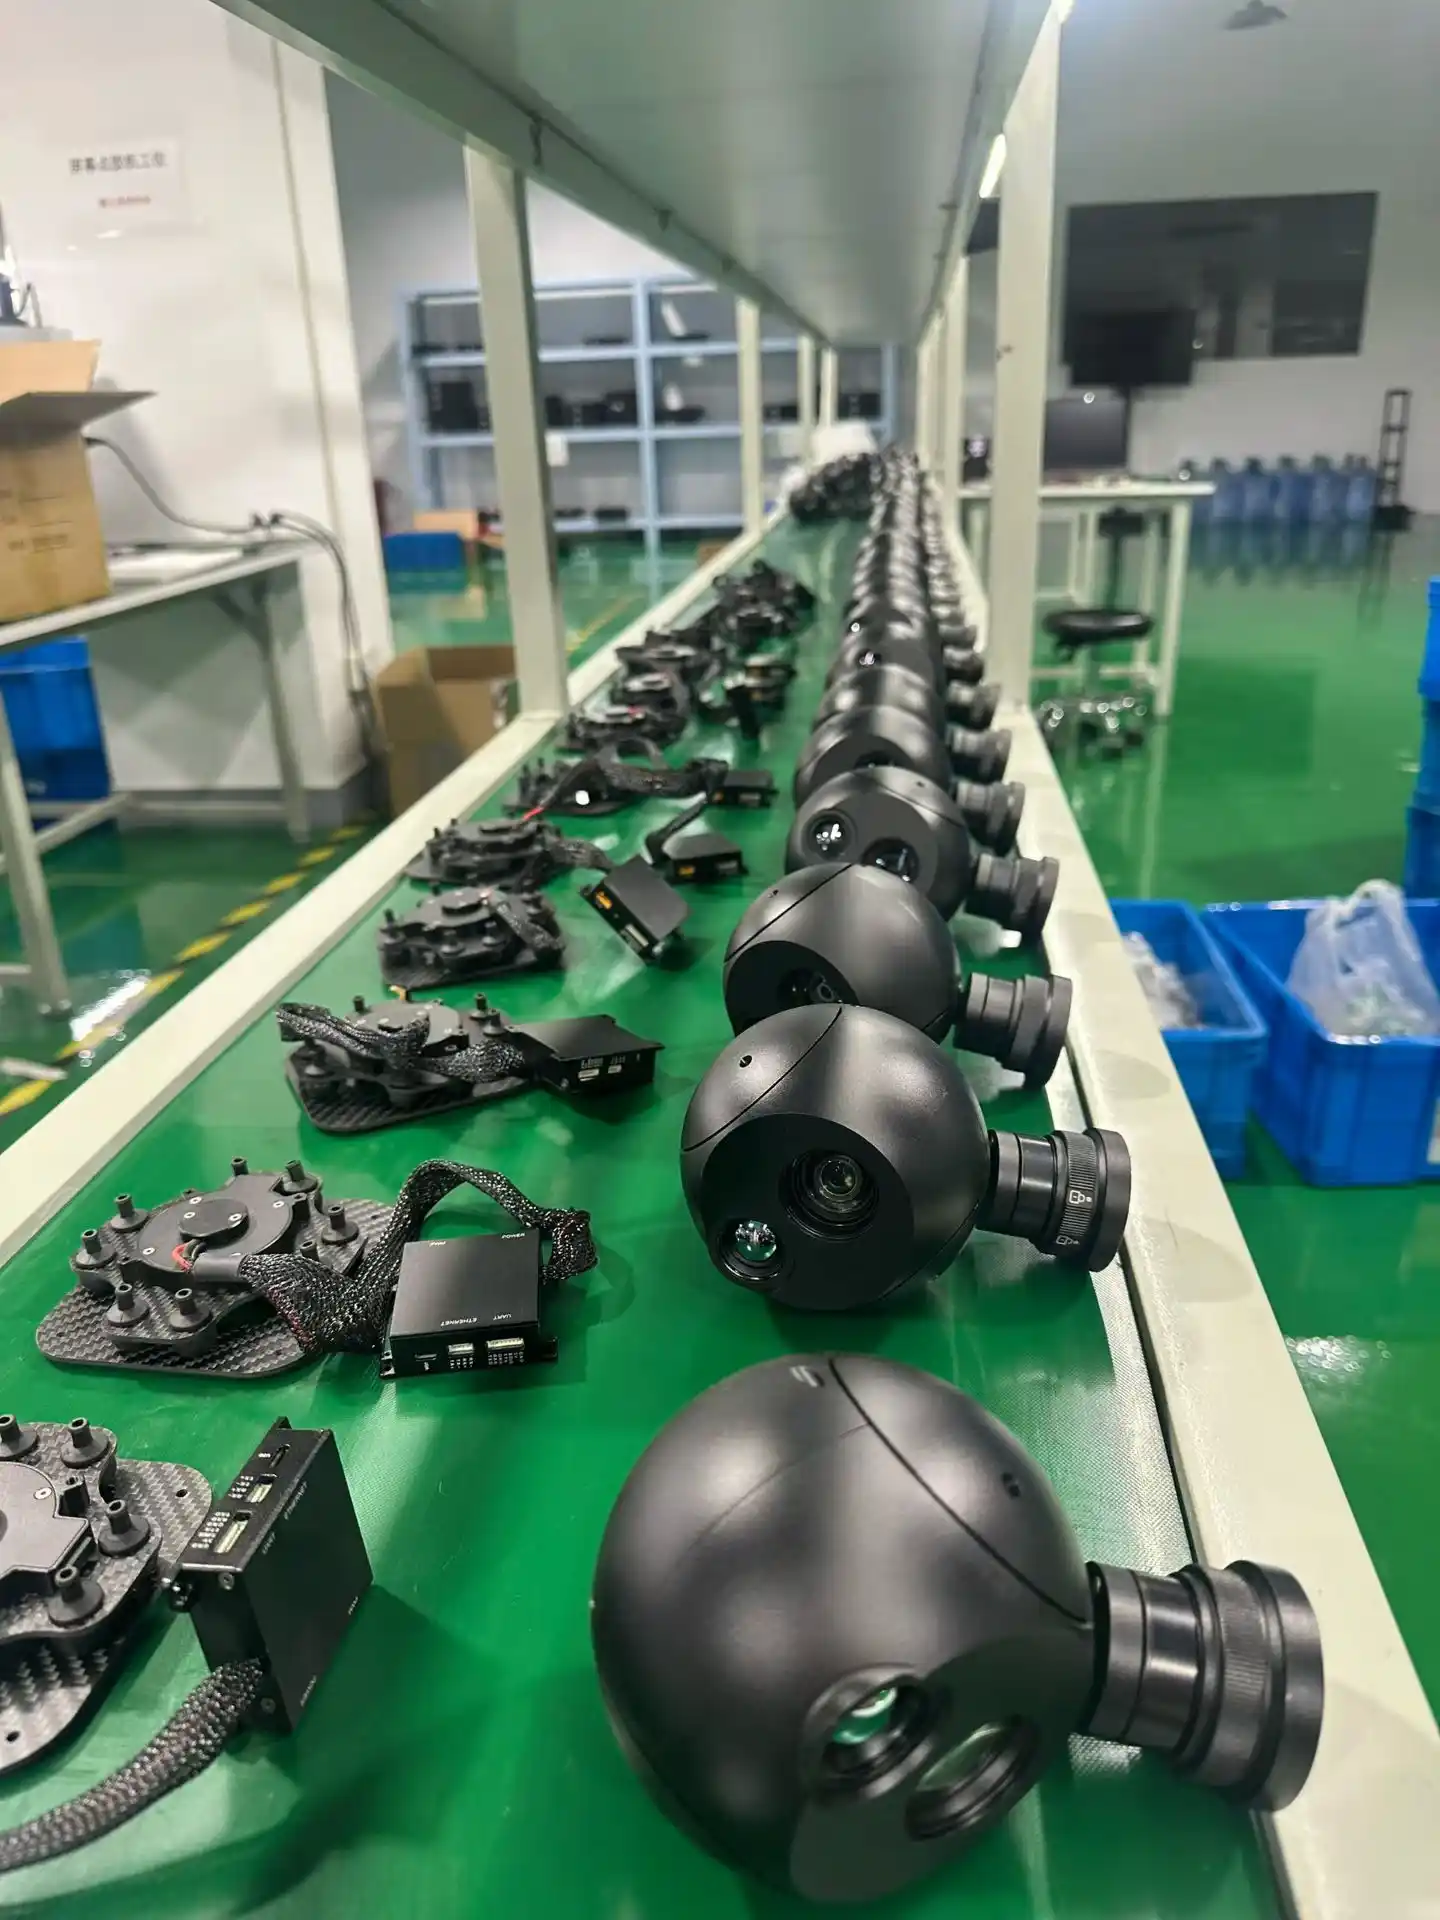
Optics, servo hardware, stabilisation firmware and the AI tracking module are developed in house, and every unit is assembled, calibrated and environmentally tested on our own line before it ships.
Request a quotation for the HQ-85Q
Tell us the platform, the range you need to identify and how many units you are planning. Every configuration is quoted individually, so you get a written price against your own requirement rather than a list figure that does not fit it. We answer within one working day.
Explore all product categories
Nine routes into the range: by stabilisation, by sensor set, or by payload class. Each category page compares the models and links to the full specification.
15 models · 240 g – 5 kg
Gimbal Cameras
Two- and three-axis stabilised heads with EO, thermal and laser options.
View category →
3 models · 240 – 500 g
2-Axis Gimbal Cameras
The lightest HQ heads: fixed or dual-FOV optics on a compact two-axis mount.
View category →
12 models · 400 g – 5 kg
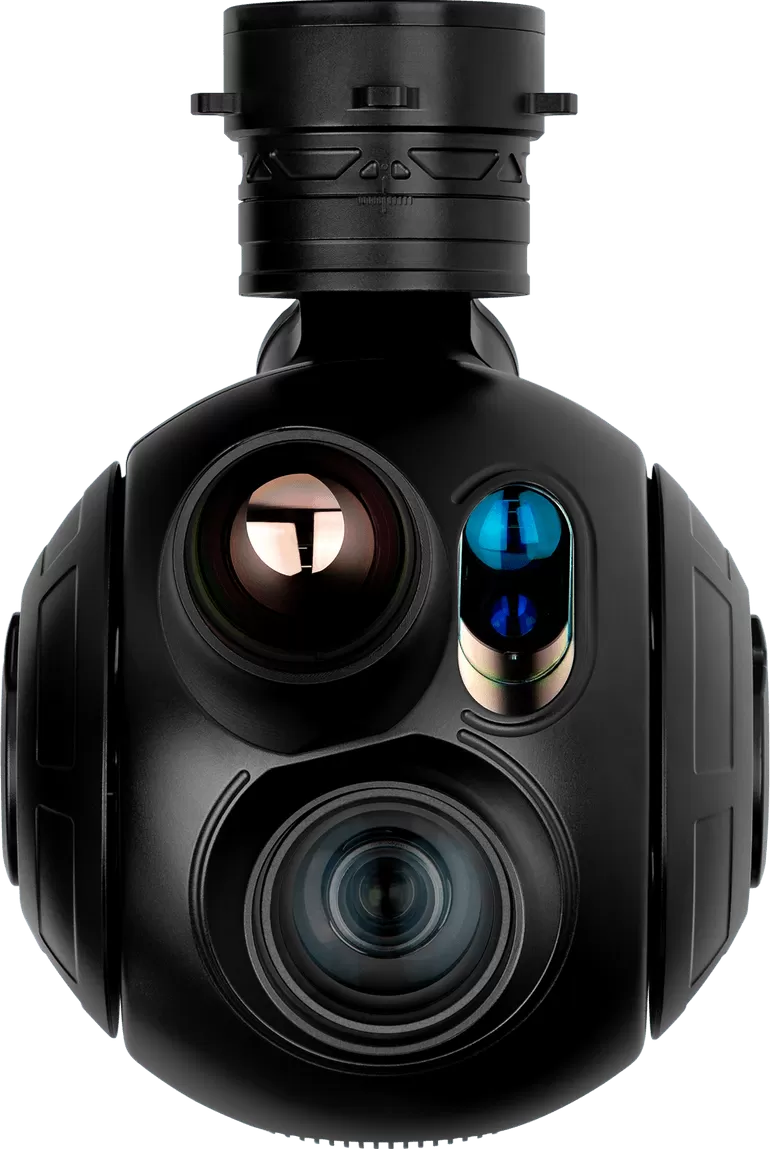
3-Axis Gimbal Cameras
Roll-stabilised heads with longer zoom ranges and heavier payload capacity.
View category →
8 models · 1.6 – 10 kg
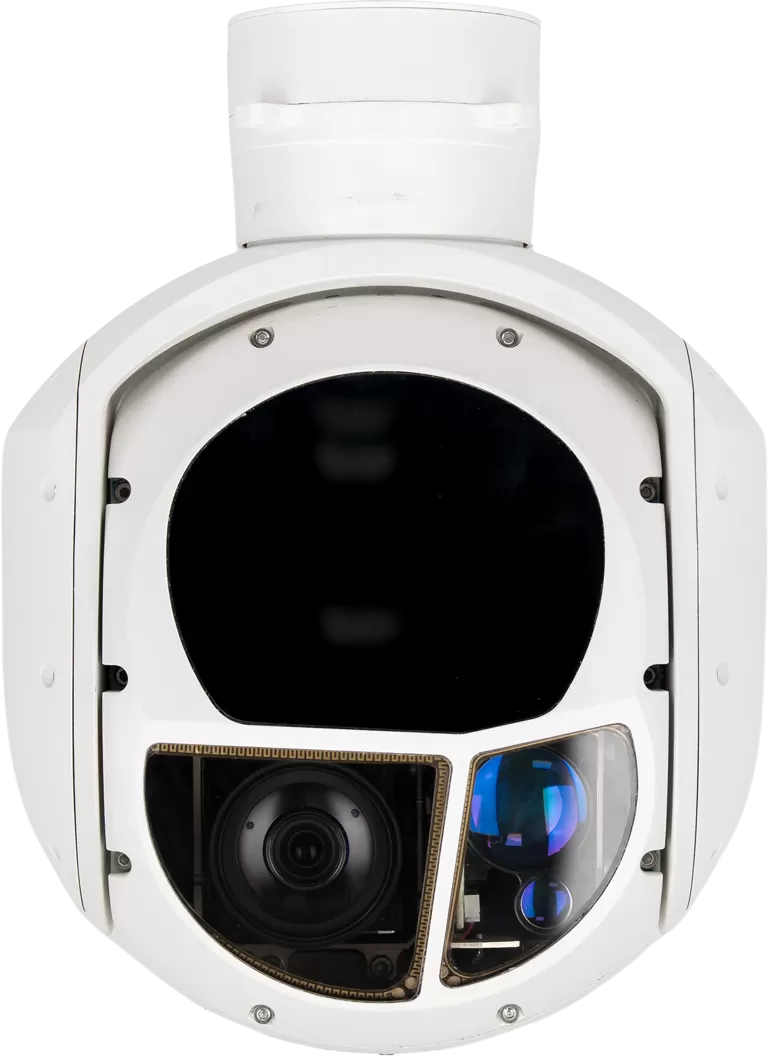
EO/IR Pod Systems
Larger multi-sensor pods with 30x–55x zoom, thermal imaging and laser ranging to 15 km.
View category →
4 models · 2.5 – 22 kg
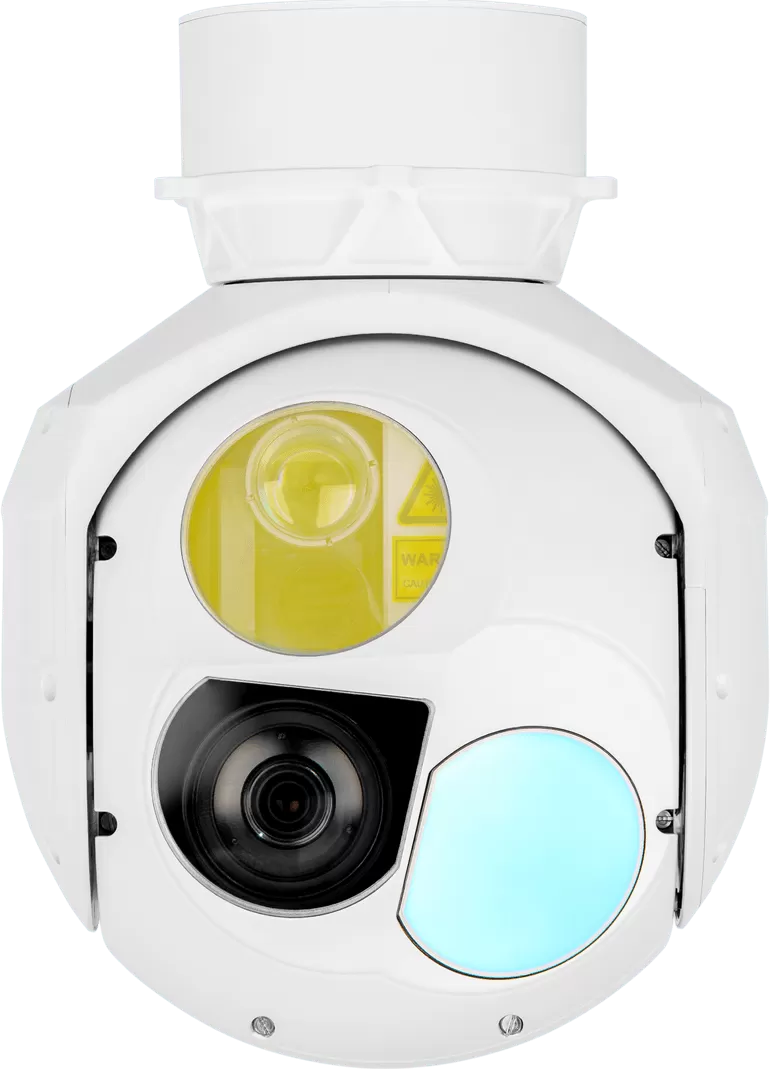
Laser Designator Pods
Targeting pods that add 1064 nm designation to the same imaging and stabilisation architecture.
View category →
Sensor guide
Thermal Cameras
Detector, lens and range: how uncooled LWIR payloads are specified for UAVs.
View category →
Sensor guide
Infrared Cameras
How to match an IR detector, lens and interface before choosing a gimbal.
View category →
Sensor guide
EO Cameras
Visible-channel sensors, zoom lenses and the resolution needed at range.
View category →
Sensor guide
EO/IR Cameras
Boresight, sensor pairing and the trade-offs of a dual-sensor head.
View category →