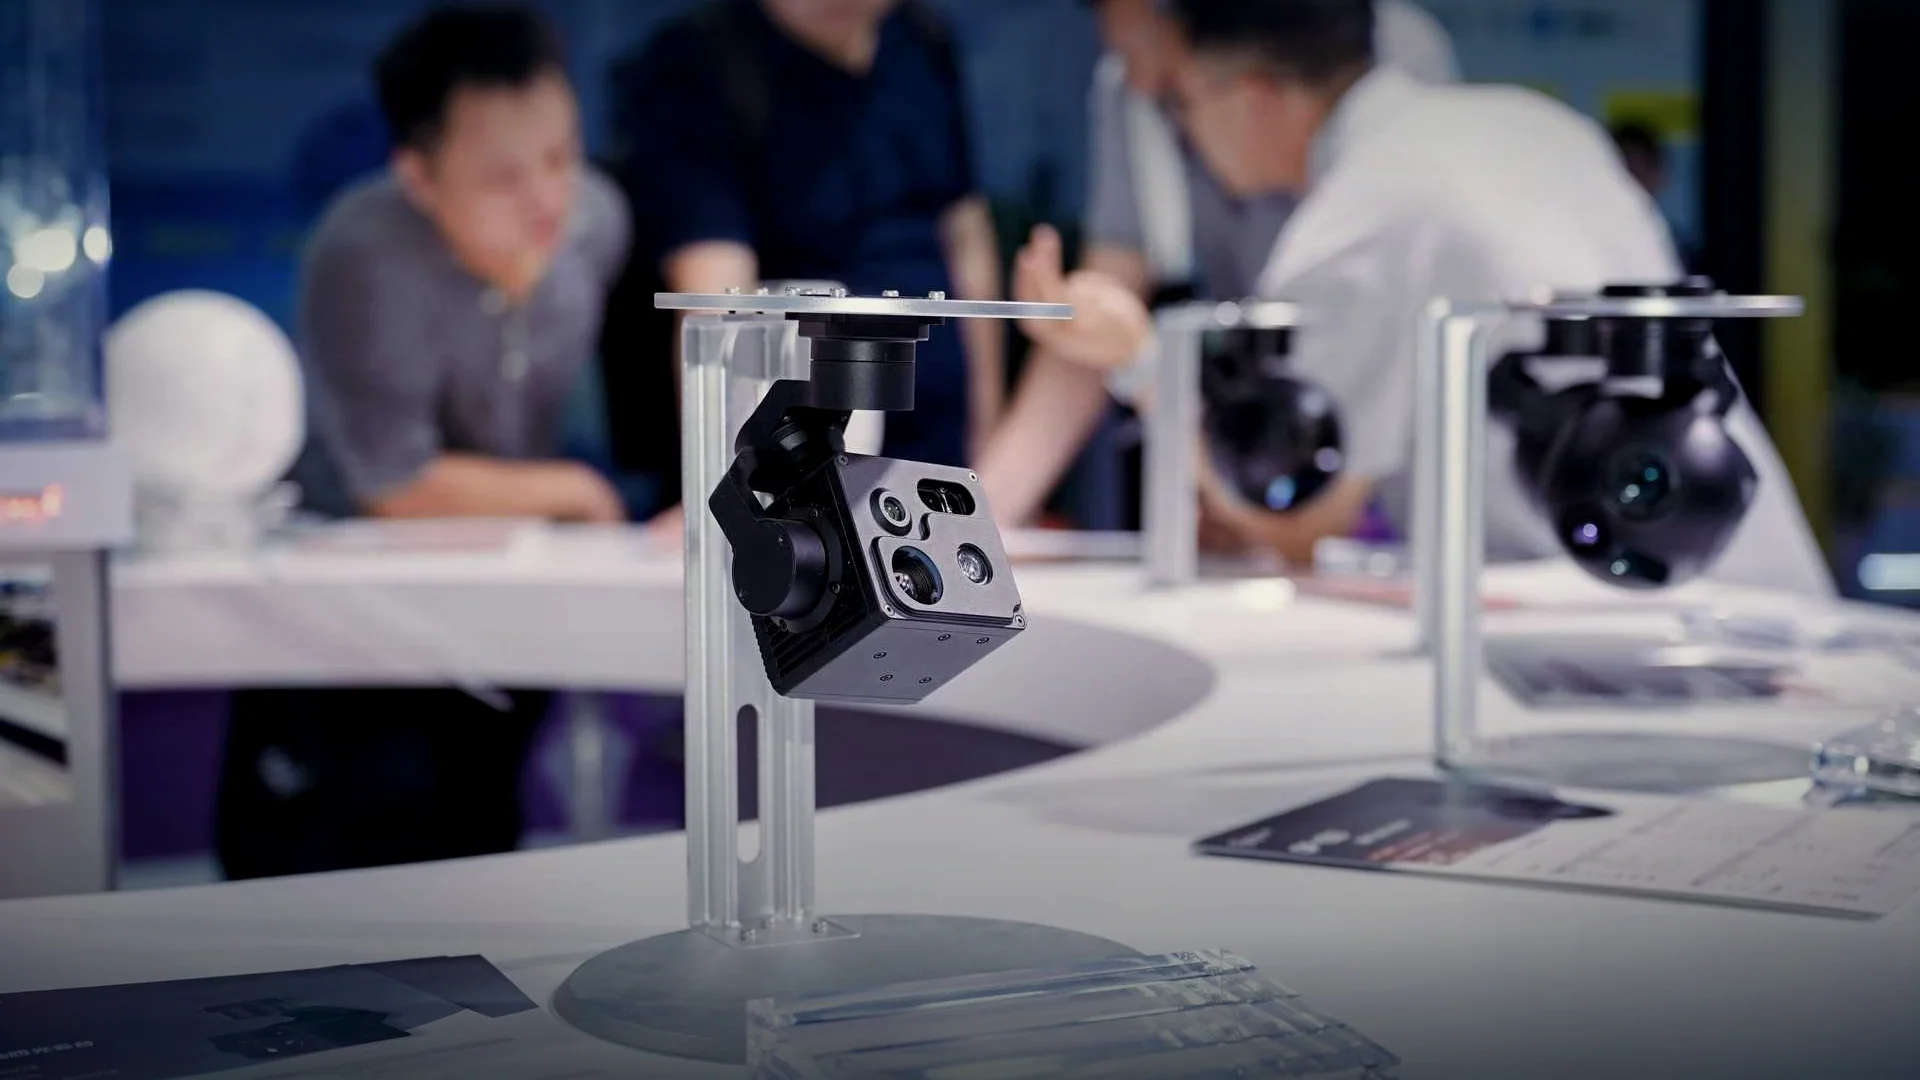
HQ-125S three-axis gimbal camera
Category: 3-Axis Gimbal Cameras
A thermal-only head with a 1280 × 1024 sensor — the highest thermal resolution in the series. Because it uses the same stabilisation stack and control protocol as the rest of the HQ series, it can share a mount and a cable run with other heads in the range.
- Weight 1 kg
- Three-axis stabilised
- Thermal 1280 × 1024
- AI detection & tracking
- CE / RoHS documentation available on request
- Export compliance statement available on request
- Calibration and test report supplied with every unit
What the HQ-125S is
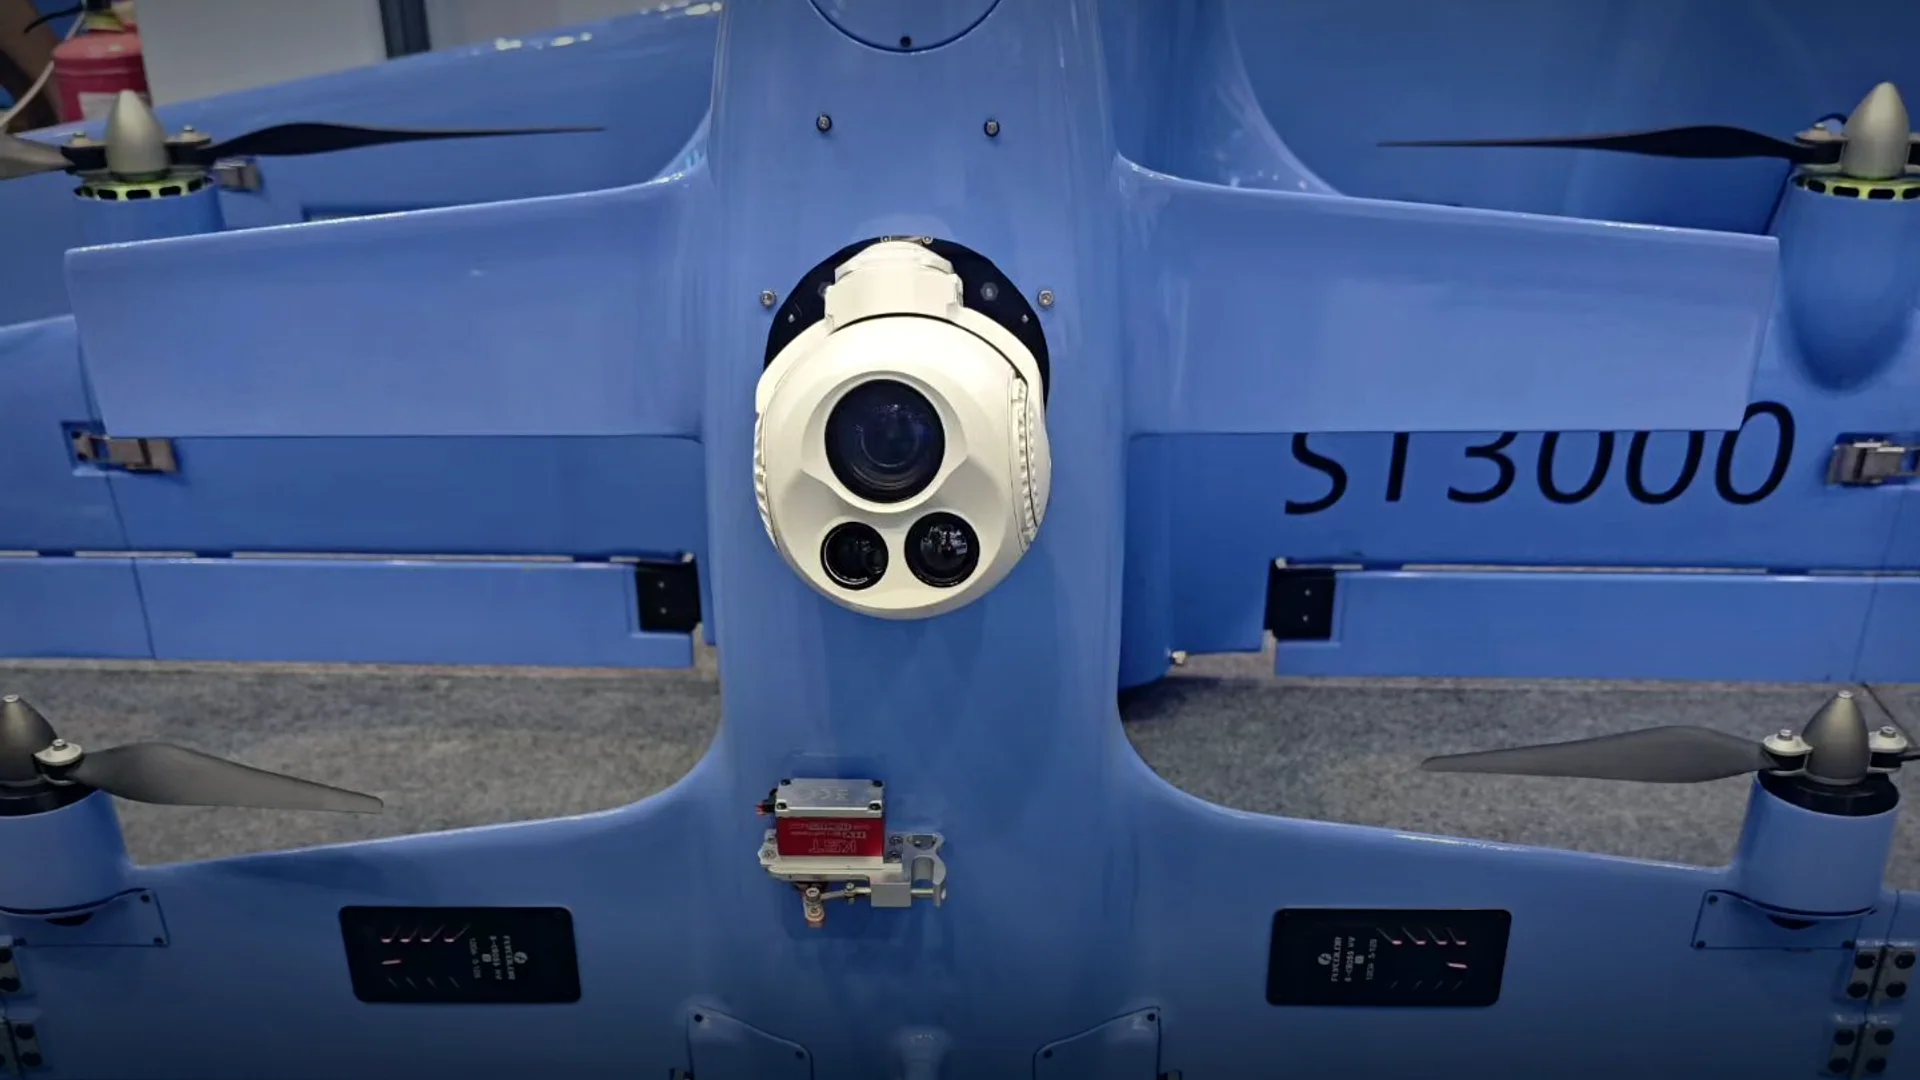
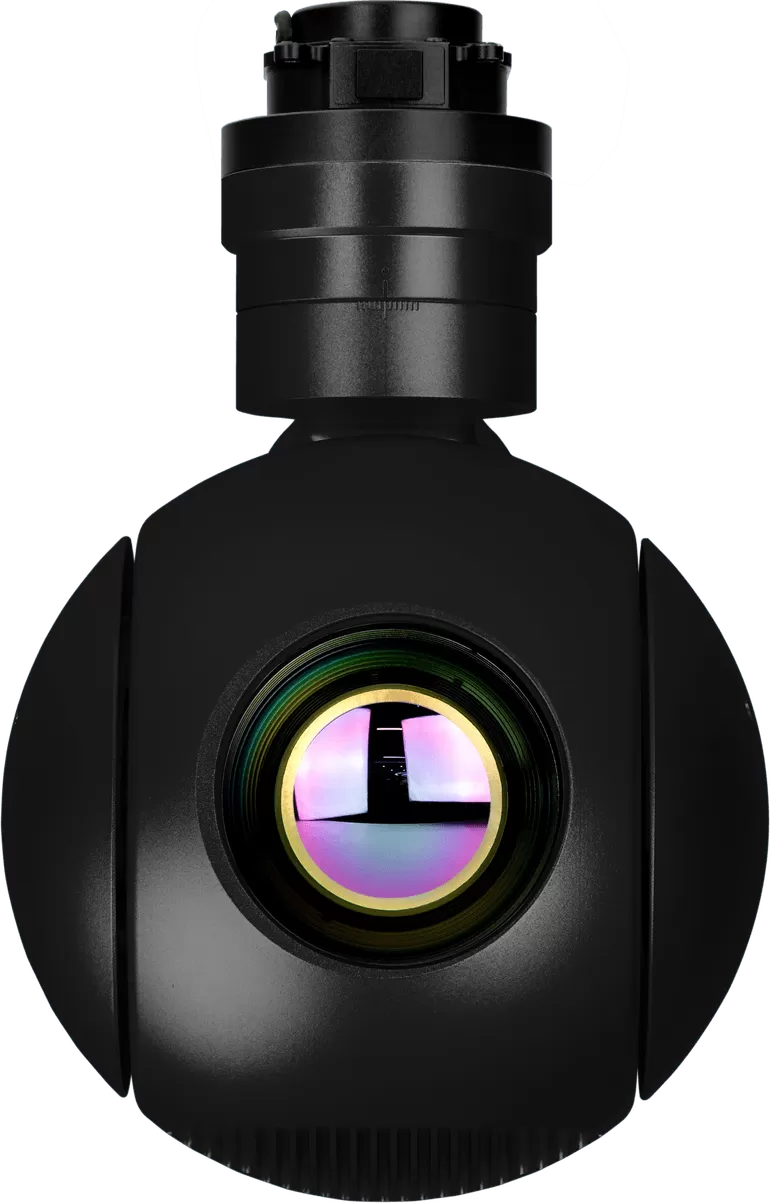
The HQ-125S is the only head in the range with a thermal core and nothing beside it, and the core is a 1280 × 1024 array behind a 50 mm fixed lens. Three axes carry it inside Φ125 × 177 mm at 1 kg, on 20 W / 30 W. Nothing here produces a daylight picture, which is the point: one detector, one lens, one file, 1.4 km detection on a person and 6 km on a vehicle at any hour. Where a dual-sensor head splits mass between optic and core, this one spends all of it on the core.
One detector, and why it is a big one
No visible channel, no laser, no zoom. What is left is a high-resolution thermal path on a stabilised mount.
Thermal / IR
1280 × 1024, 50 mm fixed
Person 1.4 km, vehicle 6 km. Uncooled LWIR at NETD ≤ 40 mK.
Why 1280 × 1024 rather than 640 × 512
Pixel count decides how much scene the operator holds and how far a target travels before it becomes a smudge. With 1280 × 1024 samples behind a 50 mm lens the frame covers ground and still resolves a body inside it, which is where 1.4 km on a person and 6 km on a vehicle come from. A 640 × 512 core matches it only with a far longer lens, and then the frame stops covering ground.
The 50 mm lens, fixed
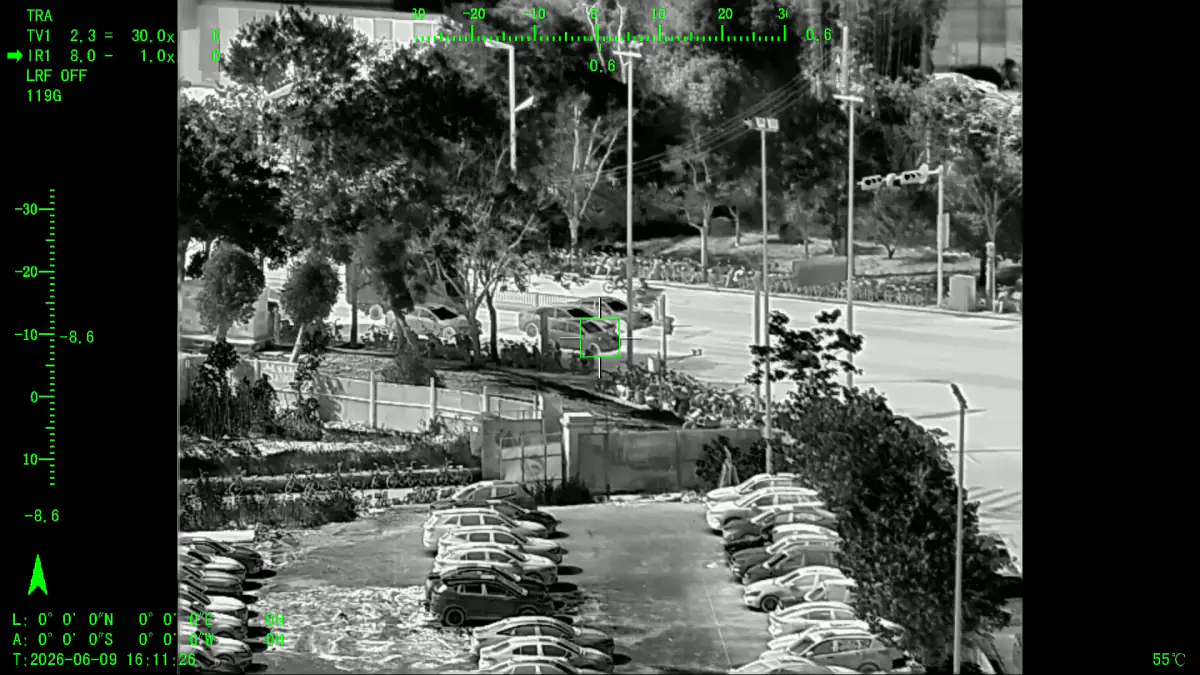
Fixed rather than zoomed, which works at this resolution: the frame is wide enough to search with and detailed enough to read into, so one setting serves both jobs. A fixed group also holds alignment through vibration. Detection is 1.4 km on a person and 6 km on a vehicle, and a warm object stays visible through smoke that would end a visible channel outright.
When a thermal-only head beats a dual-sensor one
Three cases. When the task runs at night and a daylight channel is dead weight. When the operator wants one product rather than two, since a single stream is one file, one feed and no boresight. And when the mass saved by dropping the visible path belongs on the detector instead, which is what happens here. A dual-sensor head answers where daytime identification is part of the task; this one answers where it is not.
The limit, stated plainly: without a visible channel, daylight identification rests on heat against background. Where a face or a colour matters, this is not the head.
Stabilisation and mechanical design
Three axes for one detector
Yaw, pitch and roll are all stabilised, each on a brushless motor fixed to its axis, encoding in the loop and no reduction gear to introduce lash. Roll correction matters more here than on a dual-sensor head: a thermal frame gives fewer cues that the horizon has tilted. Boresight holds within ≤ 100 μrad (1σ) at ≥ 60°/s.
1 kg in Φ125 × 177 mm
The head is 1 kg in Φ125 × 177 mm, a volume driven by the 50 mm lens rather than the electronics. It takes 11–28 VDC on a 20 W / 30 W draw, less than a three-sensor head this size, because one detector runs.
Detection and tracking at the edge
A detector tuned to a thermal picture
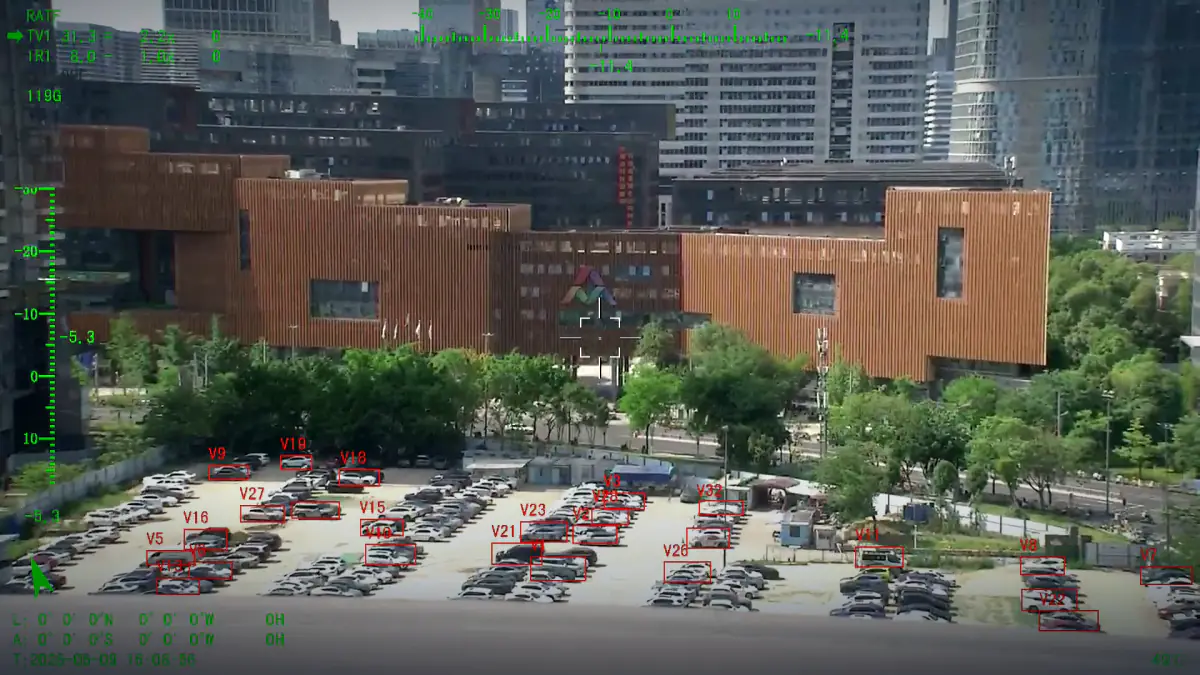
The module inside the head finds people, vehicles, vessels and aircraft in the heat frame alone, with no daylight image to assist. Processing stays on the payload, so boxes survive a thin link; twenty tracks can run at once with one actively locked.
What a night operator depends on
The lock survives rotation and scale change and returns after occlusion, whether a body passed behind a wall or a vehicle behind a treeline. Recording is internal, so a night pass is on file regardless of what the station saw live.
Airframe integration
A single-sensor head at 1 kg: mount, bus and the documents that come with it.
Mount and mass
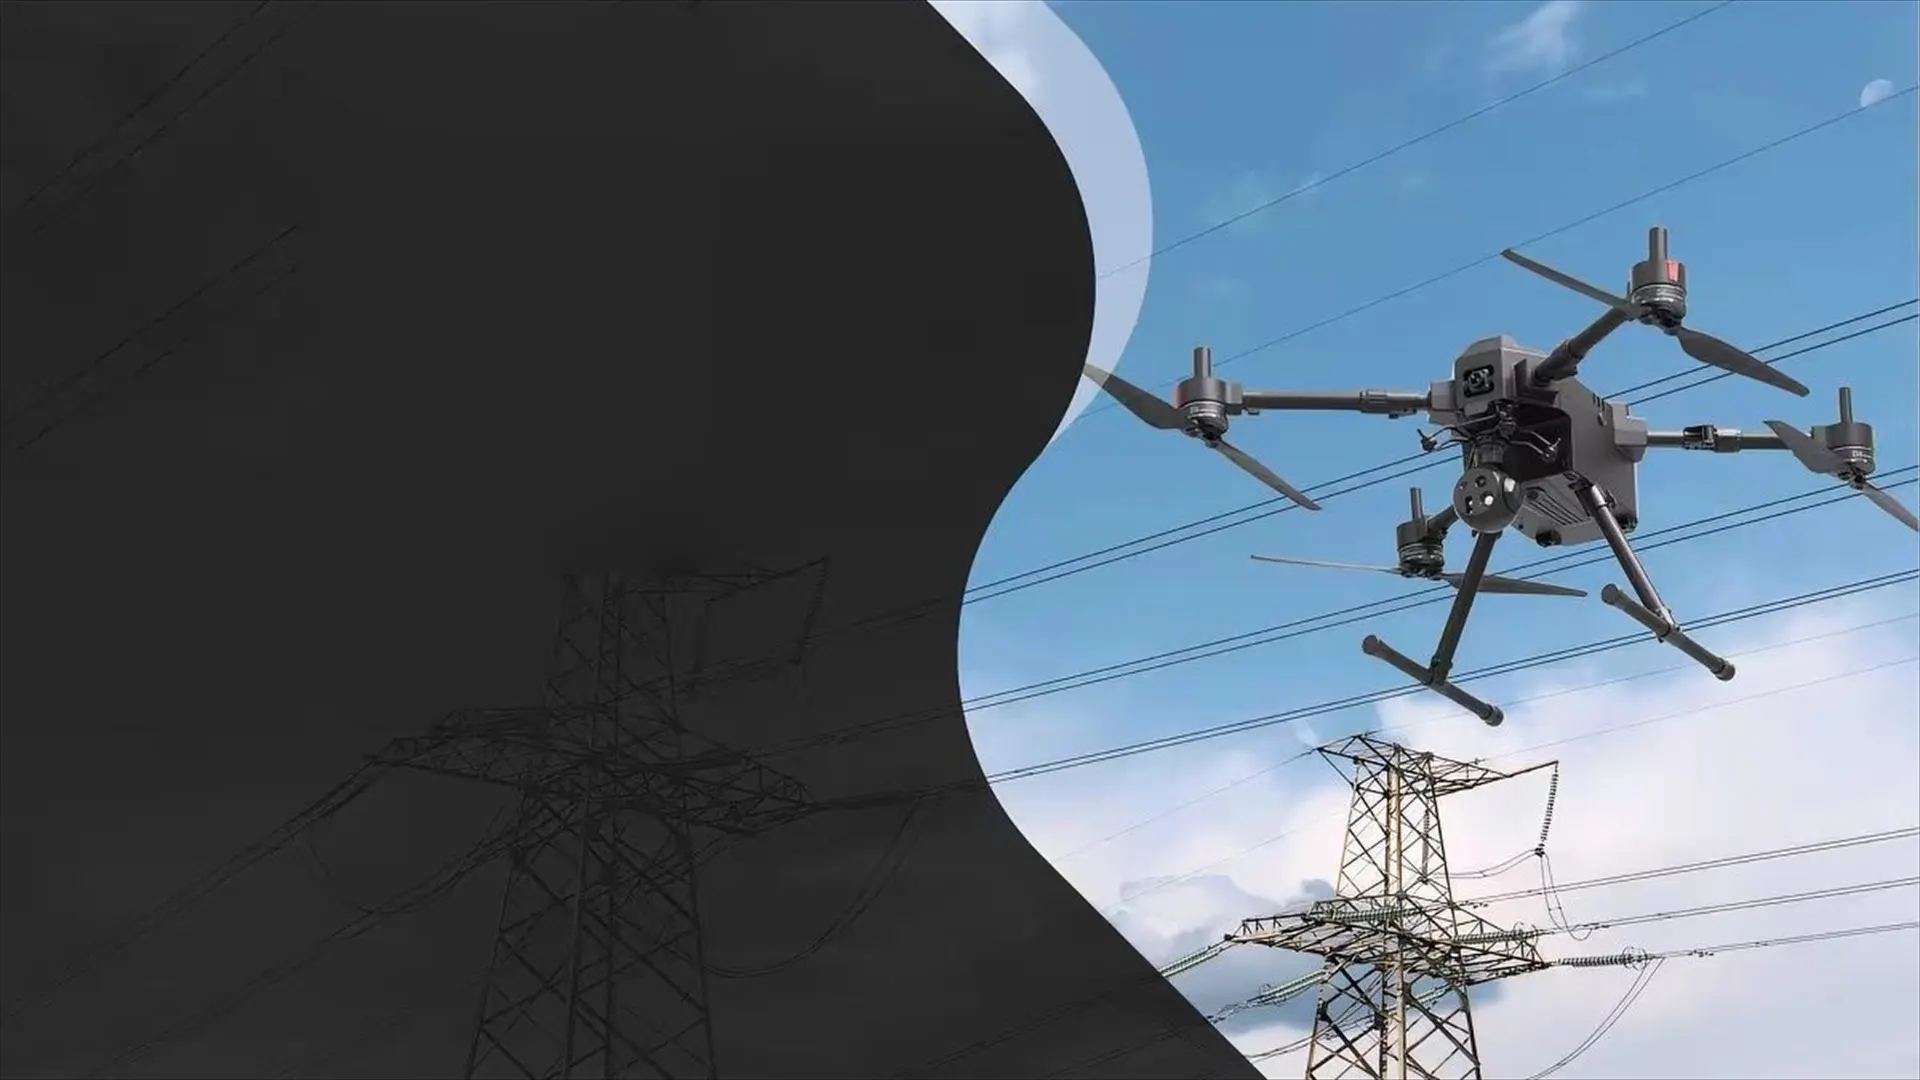
A vibration-isolated base carries the quick-release face, and adapter plates cover a different bolt circle. Both catalogue figures, 1 kg and Φ125 × 177 mm, go into the bracket stress case, so a multirotor, fixed-wing aircraft or small helicopter mounts the head without anything bespoke.
Bus, environment, paperwork
Feed it 11 to 28 VDC. Control takes RS-422, RS-232 or TTL, with SBUS and MAVLink where the autopilot uses them. Video is H.264 or H.265 at 100 Mbps over Ethernet, written to 128 GB inside the head. Dust and rotor-wash sealing; −20 °C to +60 °C working and −40 °C to +70 °C stored. One shared layer for the whole range, set out on the technology pages.
Where the mass goes
One detector, one lens, three axes. Nothing in that volume is waiting on a channel the mission never uses.
Protocol, pipeline note, outline with pinout, calibration record and test report all travel with the first head, and export screening covers them too.
Where the HQ-125S is used
Three tasks that are thermal from start to finish, with no daylight phase to serve.
- Night search lines
A search flown after dark has no use for a daylight optic, and every gram spent on one is a gram not spent on the detector. The 1280 × 1024 array behind 50 mm finds a person at 1.4 km and a vehicle at 6 km, and the pixel count lets the crew widen the search line without losing the ability to look into the frame once something turns up.
- Warm-plant inspection
On a plant the question is which connection, bearing or joint runs hotter than its neighbours, and a heat picture answers it alone. One high-resolution thermal channel compares more cleanly than a fused view, because every pixel came from the same detector under the same settings. One file per flight also keeps the archive comparable.
- Fire front and hotspot mapping
Smoke defeats a visible channel long before a thermal one. The 1280 × 1024 core holds a wide frame with resolution to place a hotspot inside it, the tracker follows a moving edge, and 1.4 km detection on a person keeps a crew clear of the front. At 1 kg and 20 W / 30 W, endurance survives.
Full specifications
| Model | HQ-125S |
| Series | Gimbal Camera Series (HQ series) |
| Stabilisation | Three-axis gyro-stabilised, ≤ 100 μrad |
| Sensor configuration | IR |
| Thermal channel | 1280 × 1024, 50 mm fixed |
| Weight | ≤1 kg |
| Dimensions | ≤Φ125 × 177 mm |
| Power consumption | 20 W / 30 W |
| Detection (IR) | 1.4 km person / 6 km vehicle |
Detection distances follow the standard 1.7 m person / 2.3 m vehicle convention. Rows marked as shared are common across the HQ series.
Control software: Windows as standard. An Android version can be customised for OEM/ODM projects.
Shared across the HQ series
- Video output: Ethernet, H.264 / H.265
- Gimbal control: RS-422 / RS-232 / TTL, SBUS, MAVLink
- Input voltage: 11–28 VDC
- Operating temperature: −20 °C to +60 °C
- Sealing: Sealed housing for dust, wind and rotor wash
- Recording: On-board recording, imagery retained if the link drops
- AI module: Onboard detection, classification and multi-target tracking
- Mounting: Quick-release interface, adapters available for OEM airframes
Three-view outline drawing with connector pinout, available on request.
Other 3-axis gimbal cameras
Same three-axis platform, same control protocol and same mounting pattern, so moving between these models is a change of optics rather than a re-integration.
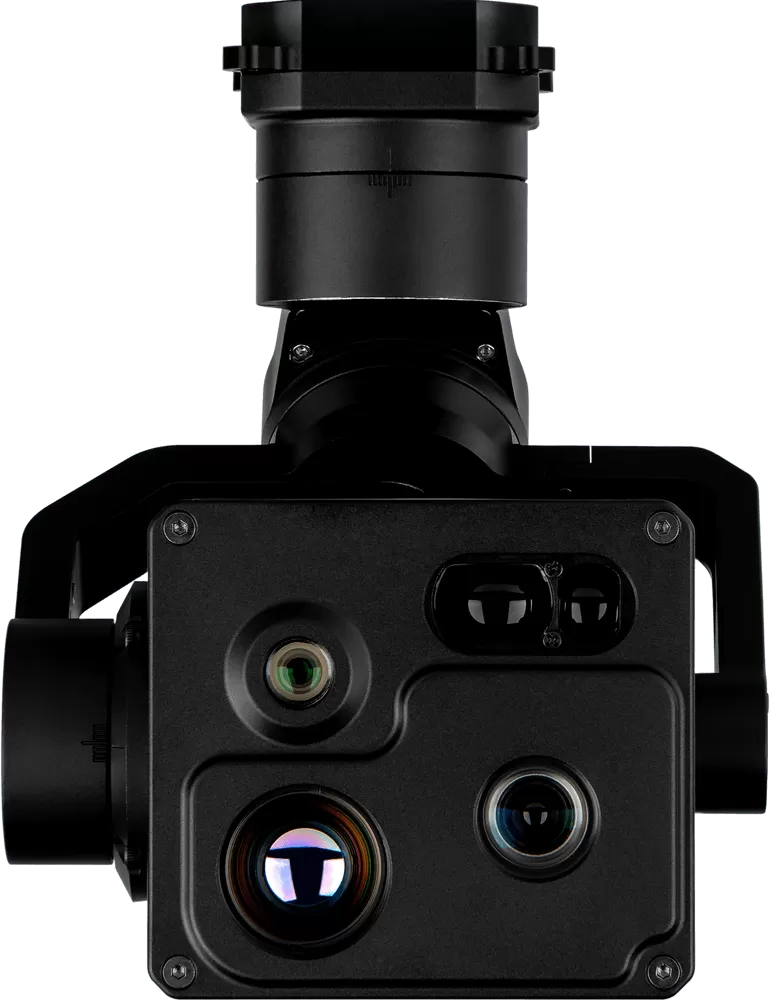
HQ series · 3-axis · EO + IR + LRF
HQ-95Q customized UAV Camera Gimbal
Four optical channels and a quick-release mount on the lightest three-axis head we build.
- Weight
- ≤400 g
- Visible
- Dual 8000 × 6000, 9.5 mm + continuous zoom 15.3 – 49.7 mm
- Laser
- 5 m – 1.5 km (± 1 m)
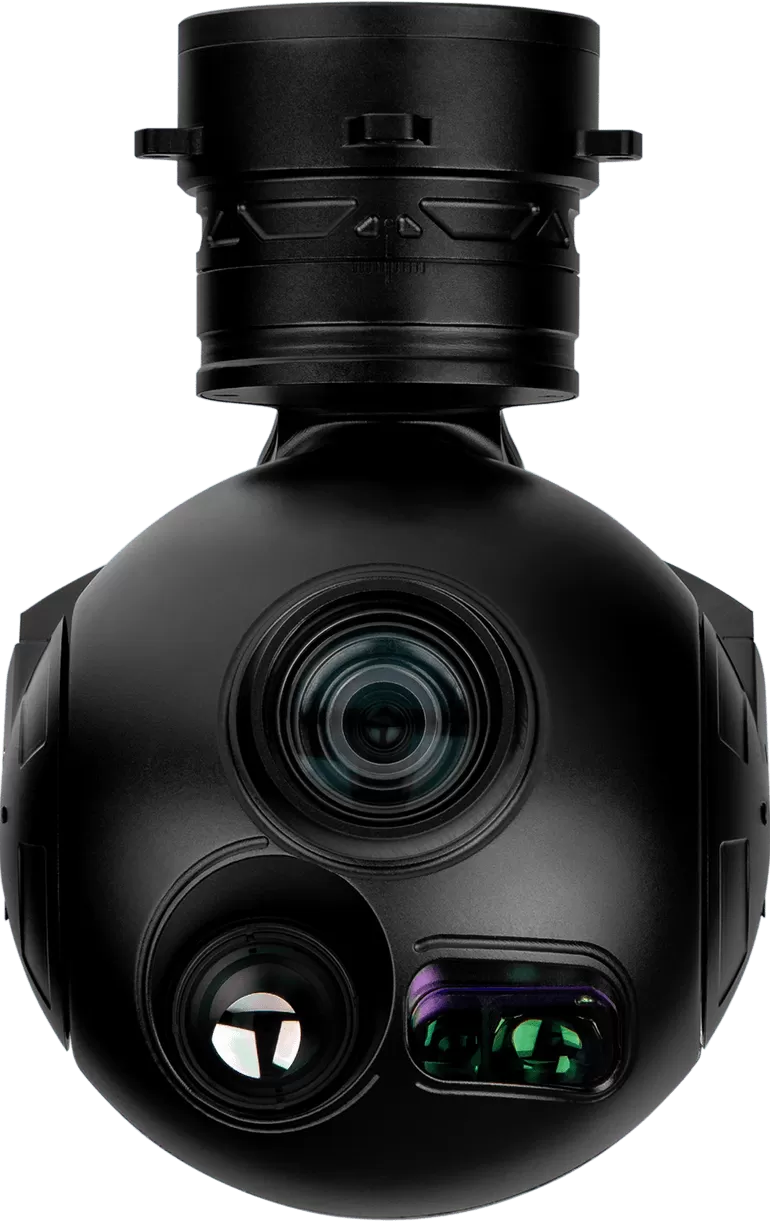
HQ series · 3-axis · EO + IR + LRF
HQ-100T Gimbal Camera Manufacturer
The same 800 g three-axis head as the 100D, with a 1.5 km laser rangefinder added.
- Weight
- ≤800 g
- Visible
- 1920 × 1080, 10x zoom 4.7 – 47 mm
- Laser
- 5 m – 1.5 km (± 1 m)
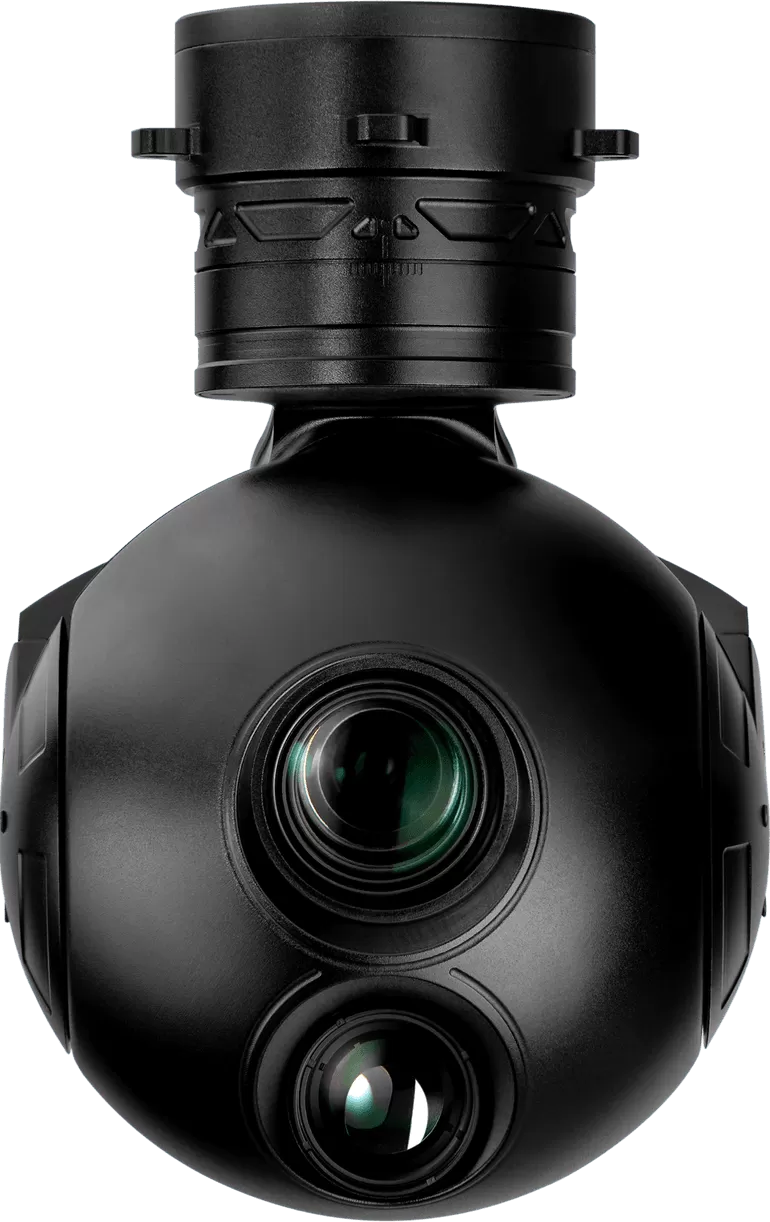
HQ series · 3-axis · EO + IR
HQ-100D Gimbal Camera OEM
The entry point to full roll-stabilised zoom and thermal imaging under a kilogram.
- Weight
- ≤800 g
- Visible
- 1920 × 1080, 10x zoom 4.7 – 47 mm
- Thermal
- 640 × 512, 19 mm fixed
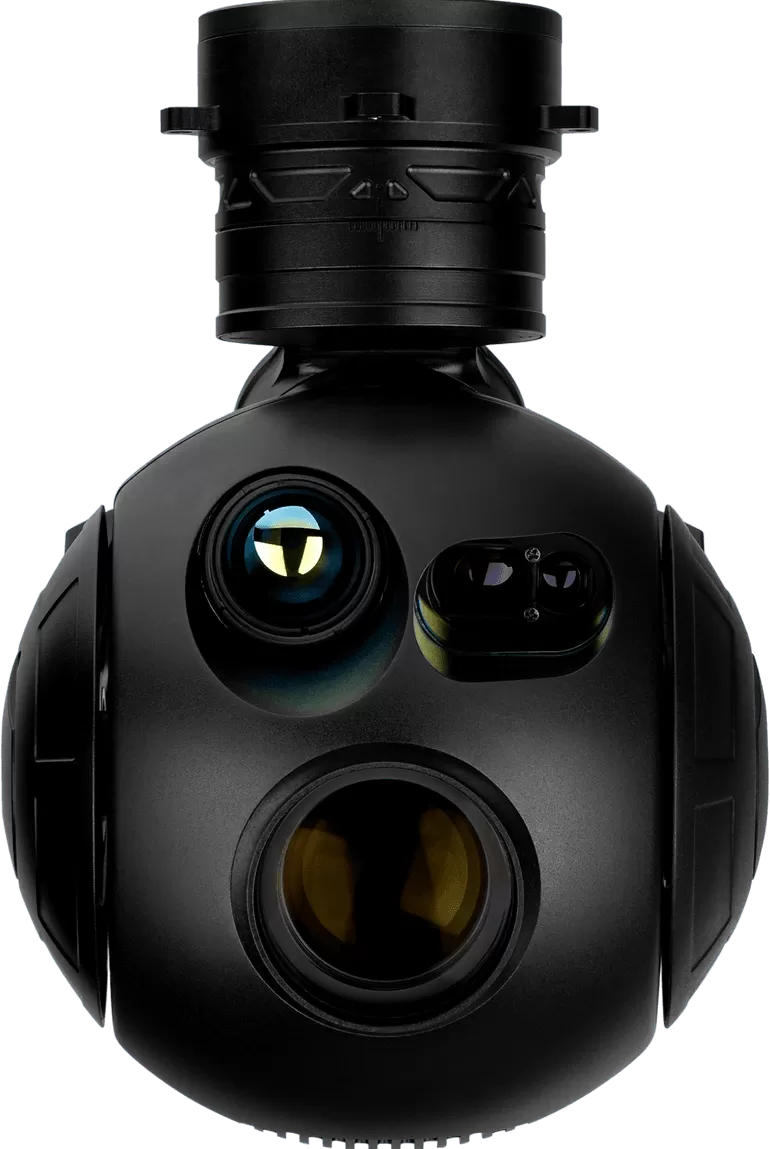
HQ series · 3-axis · EO + IR + LRF
HQ-115T Gimbal Camera Manufacturer
The one-kilogram workhorse: 30x zoom, thermal imaging and a 1.5 km rangefinder.
- Weight
- ≤1 kg
- Visible
- 1920 × 1080, 30x zoom 4.3 – 129 mm
- Laser
- 5 m – 1.5 km (± 1 m)
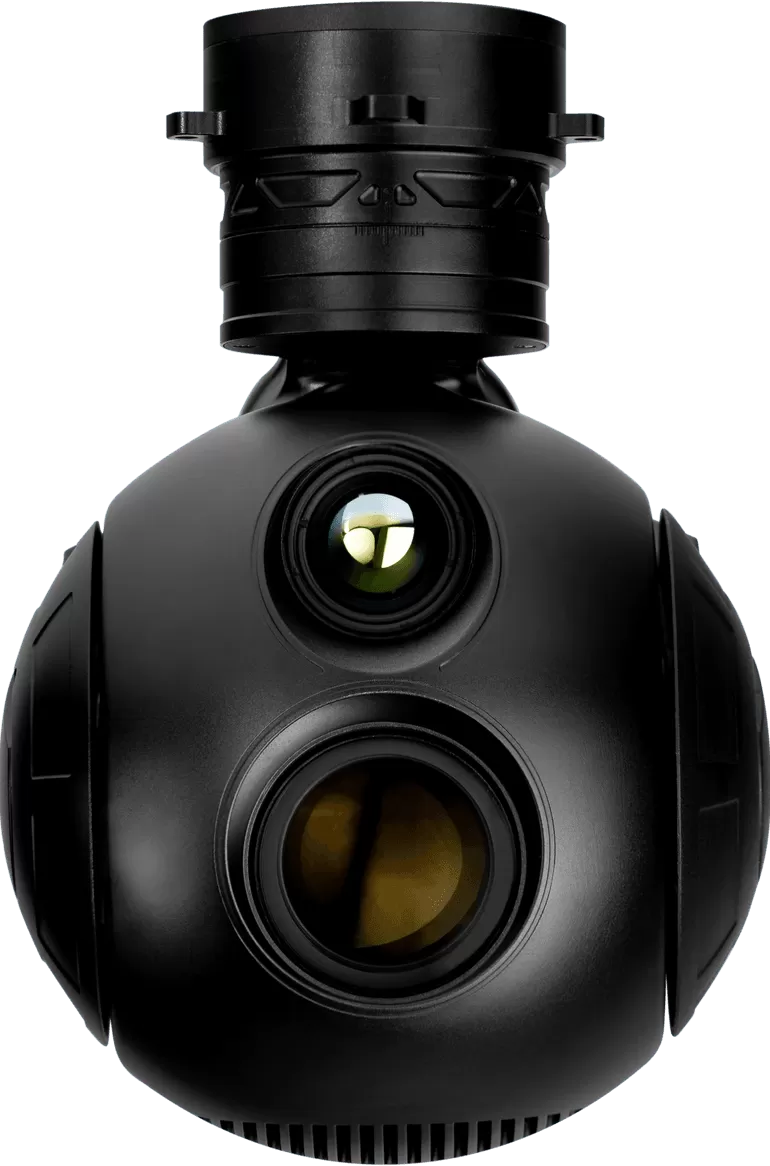
HQ series · 3-axis · EO + IR
HQ-115D UAV Gimbal Camera OEM
30x zoom and thermal imaging on a one-kilogram head with no ranging requirement.
- Weight
- ≤1 kg
- Visible
- 1920 × 1080, 30x zoom 4.3 – 129 mm
- Thermal
- 640 × 512, 25 mm fixed
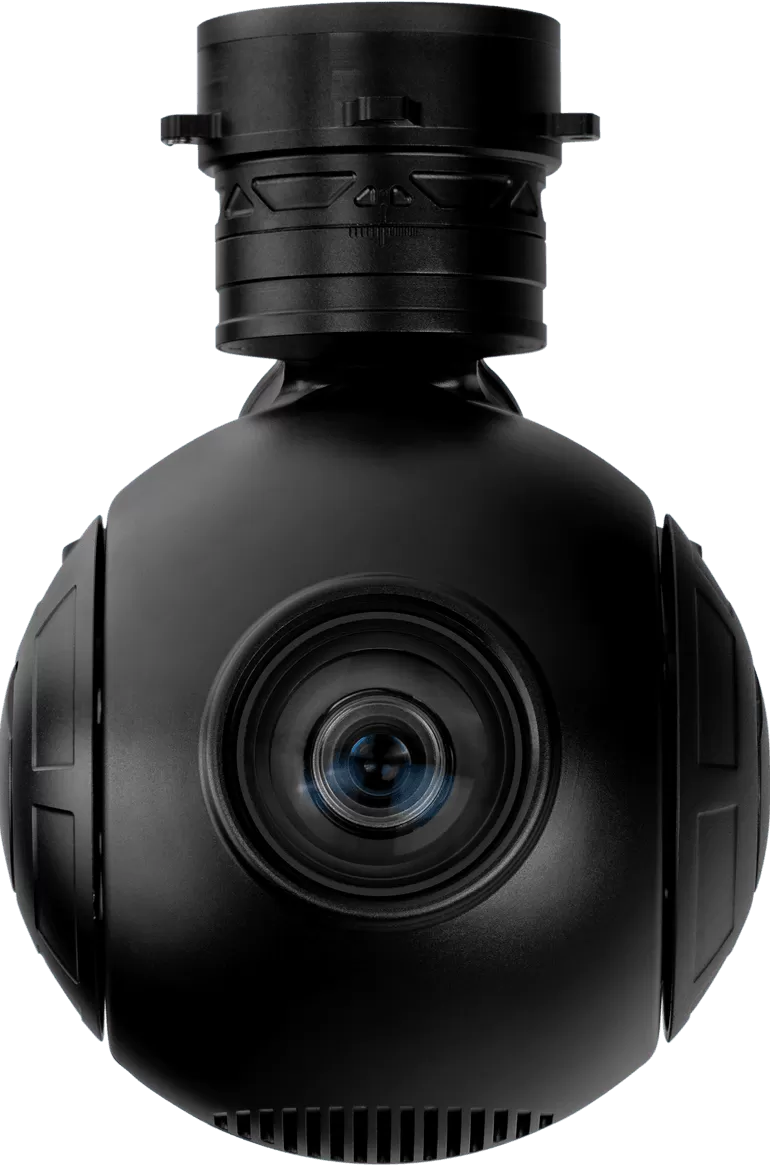
HQ series · 3-axis · EO
HQ-115S Drone Camera Gimbal Direct Factory
A 40x daylight optic alone, for daylight-only surveillance where the weight budget rules out a thermal channel.
- Weight
- ≤1 kg
- Visible
- 1920 × 1080, 40x zoom 4.25 – 170 mm
- Thermal
- —
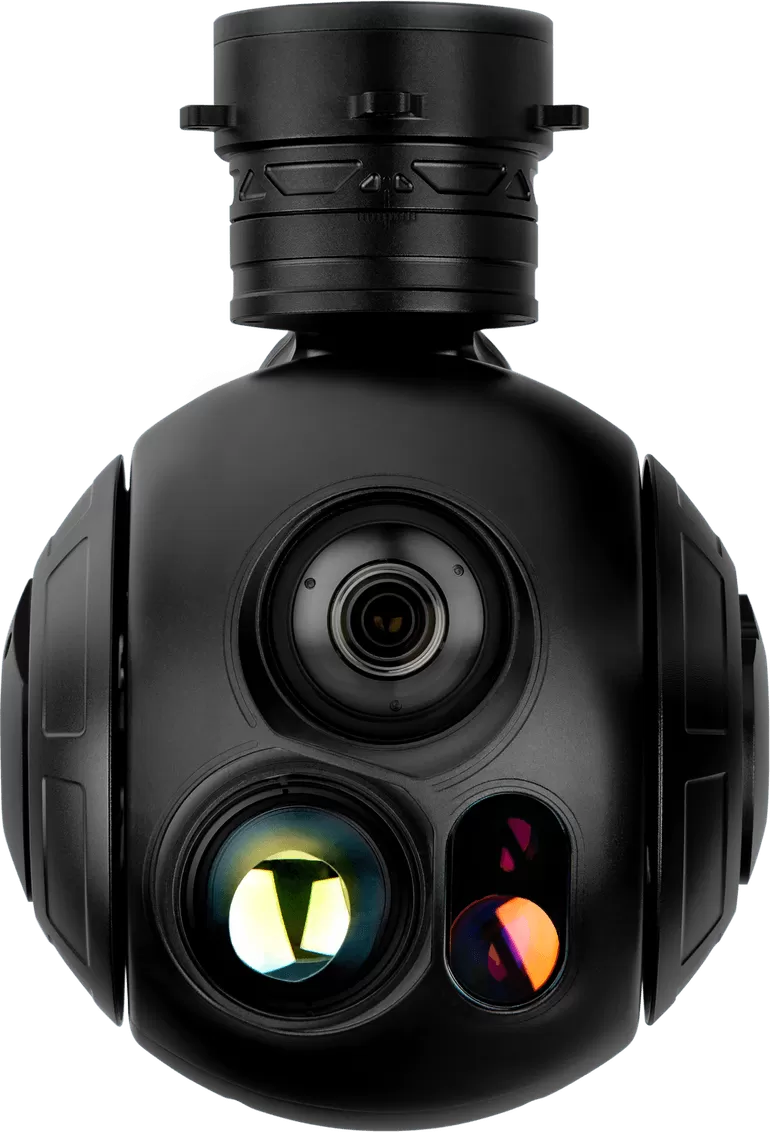
HQ series · 3-axis · EO + IR + LRF
HQ-125TB Gimbal Camera Supplier
Balanced mid-range turret: 30x zoom, a long thermal lens and 3 km ranging.
- Weight
- ≤1.2 kg
- Visible
- 1920 × 1080, 30x zoom 4.3 – 129 mm
- Laser
- 15 m – 3 km (± 1 m)
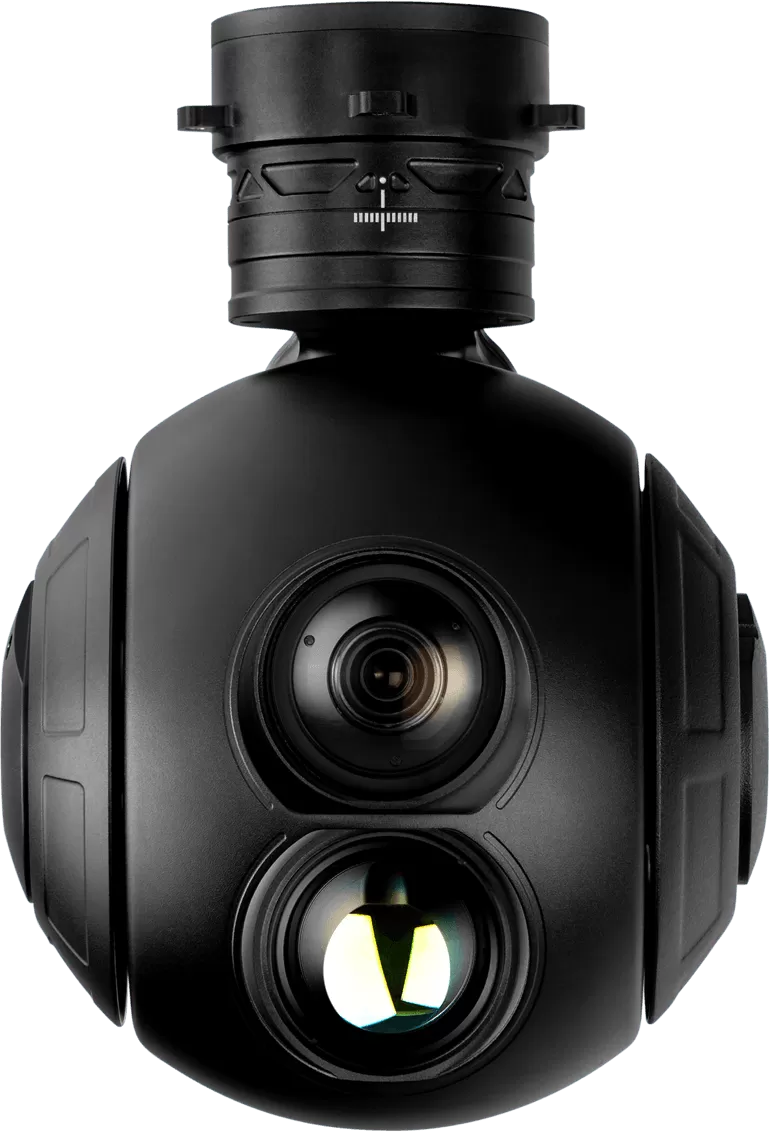
HQ series · 3-axis · EO + IR
HQ-125DB UAV Camera Gimbal ODM
The longer 35 mm thermal lens paired with 30x zoom, without the rangefinder.
- Weight
- ≤1.1 kg
- Visible
- 1920 × 1080, 30x zoom 4.3 – 129 mm
- Thermal
- 640 × 512, 35 mm fixed
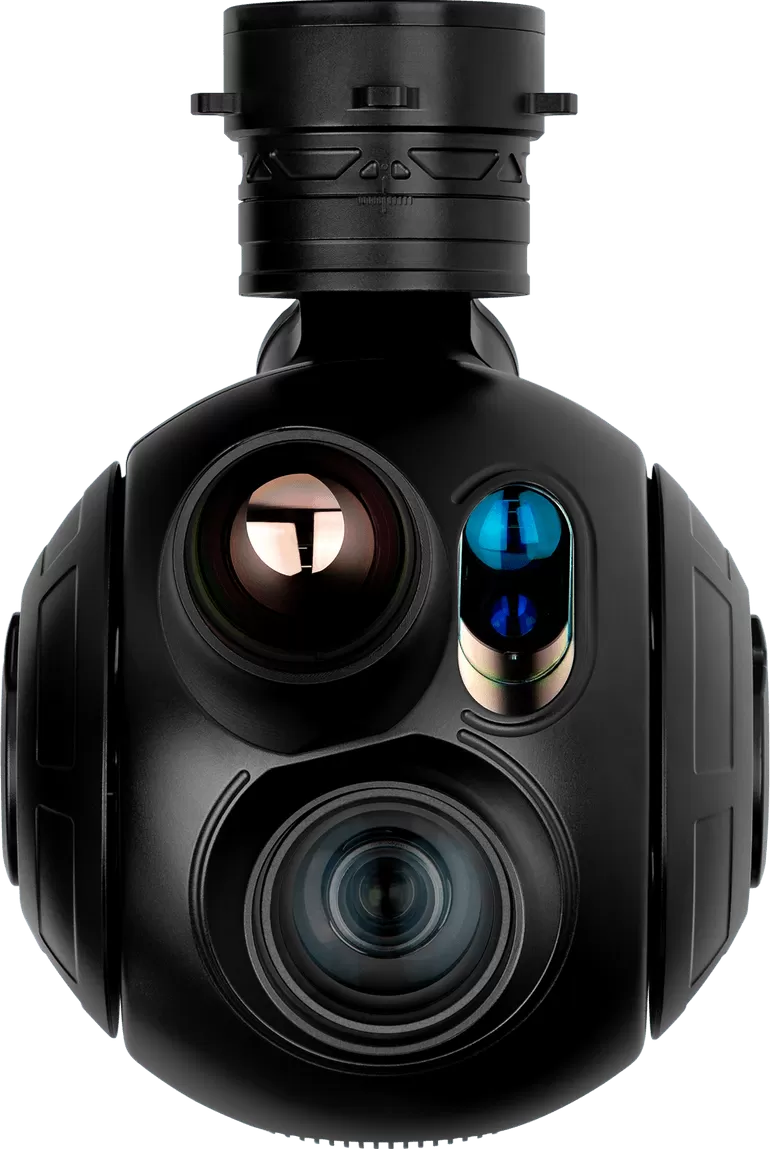
HQ series · 3-axis · EO + IR + LRF
HQ-135T UAV Gimbal Camera OEM
The flagship of the compact range: 40x zoom, thermal imaging and 3 km ranging on one stabilised cage.
- Weight
- ≤1.4 kg
- Visible
- 1920 × 1080, 40x zoom 4.25 – 170 mm
- Laser
- 15 m – 3 km (± 1 m)
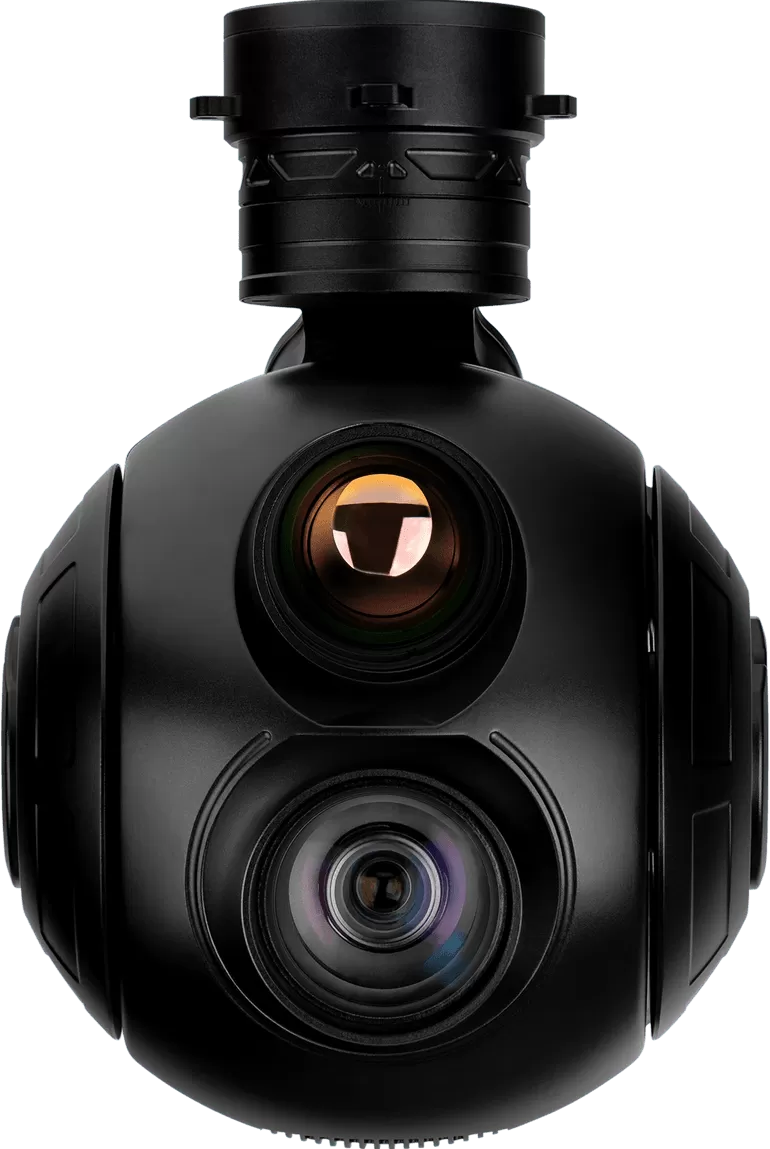
HQ series · 3-axis · EO + IR
HQ-135D customized Drone Camera Payload
The 40x optic with thermal imaging, for daylight and night identification at long range.
- Weight
- ≤1.4 kg
- Visible
- 1920 × 1080, 40x zoom 4.25 – 170 mm
- Thermal
- 640 × 512, 35 mm fixed
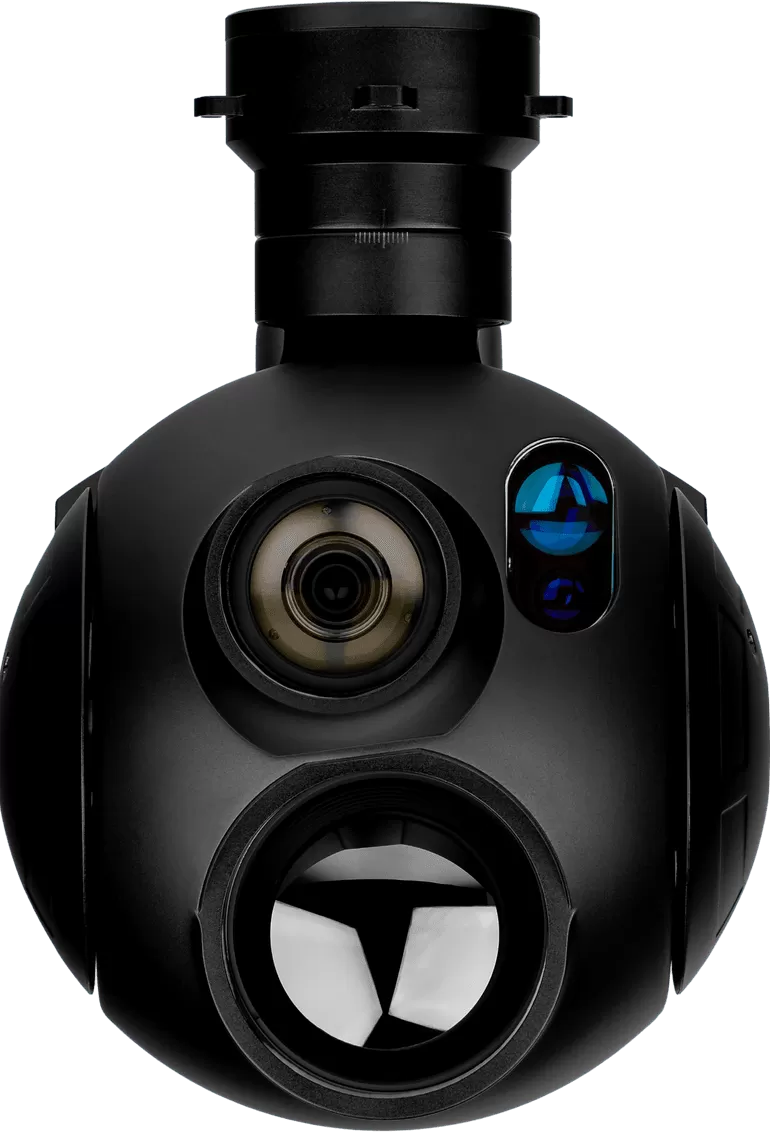
HQ series · 3-axis · EO + IR + LRF
HQ-135TA Stabilised UAV Camera Manufacturer
A 50 mm thermal lens gives the longest thermal reach in the compact range.
- Weight
- ≤1.5 kg
- Visible
- 1920 × 1080, 30x zoom 4.3 – 129 mm
- Laser
- 15 m – 3 km (± 1 m)
Questions engineers ask about the HQ-125S
How far does the HQ-125S detect a person or a vehicle?
1.4 km to a person and 6 km to a vehicle, from the 1280 × 1024 array behind its 50 mm lens, against the standard 1.7 m person and 2.3 m vehicle targets. This is a detection figure; recognition and identification come at closer range and are listed in the datasheet.
What is the minimum order, and when does a head ship?
Single units for a stock build, 100 for a custom one. Built heads go out as they stand, so only freight remains; a custom or volume batch takes its schedule from the quotation. Payment by T/T.
Why 1280 × 1024 instead of 640 × 512?
More samples in the same frame. On a 50 mm lens that means the picture is wide enough to search with and detailed enough to read into, which is what 1.4 km person and 6 km vehicle detection rests on. A 640 × 512 core of the same focal length puts fewer samples across the same ground, and buying the reach back with a longer lens gives up the context around the target.
Can it work in daylight without a visible channel?
Yes, on heat contrast. A body, a vehicle engine or a warm roof stands out from its background at any hour, and detection at 1.4 km and 6 km does not change with the light. What it cannot do is read a colour, a marking or a face; those need a visible channel, and this head does not have one.
Designed and manufactured by HITS
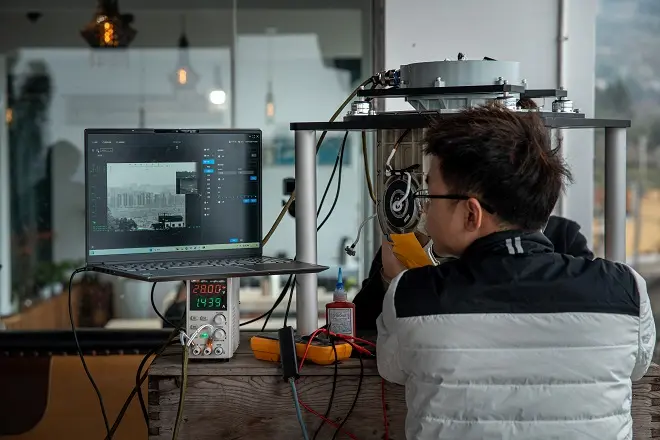
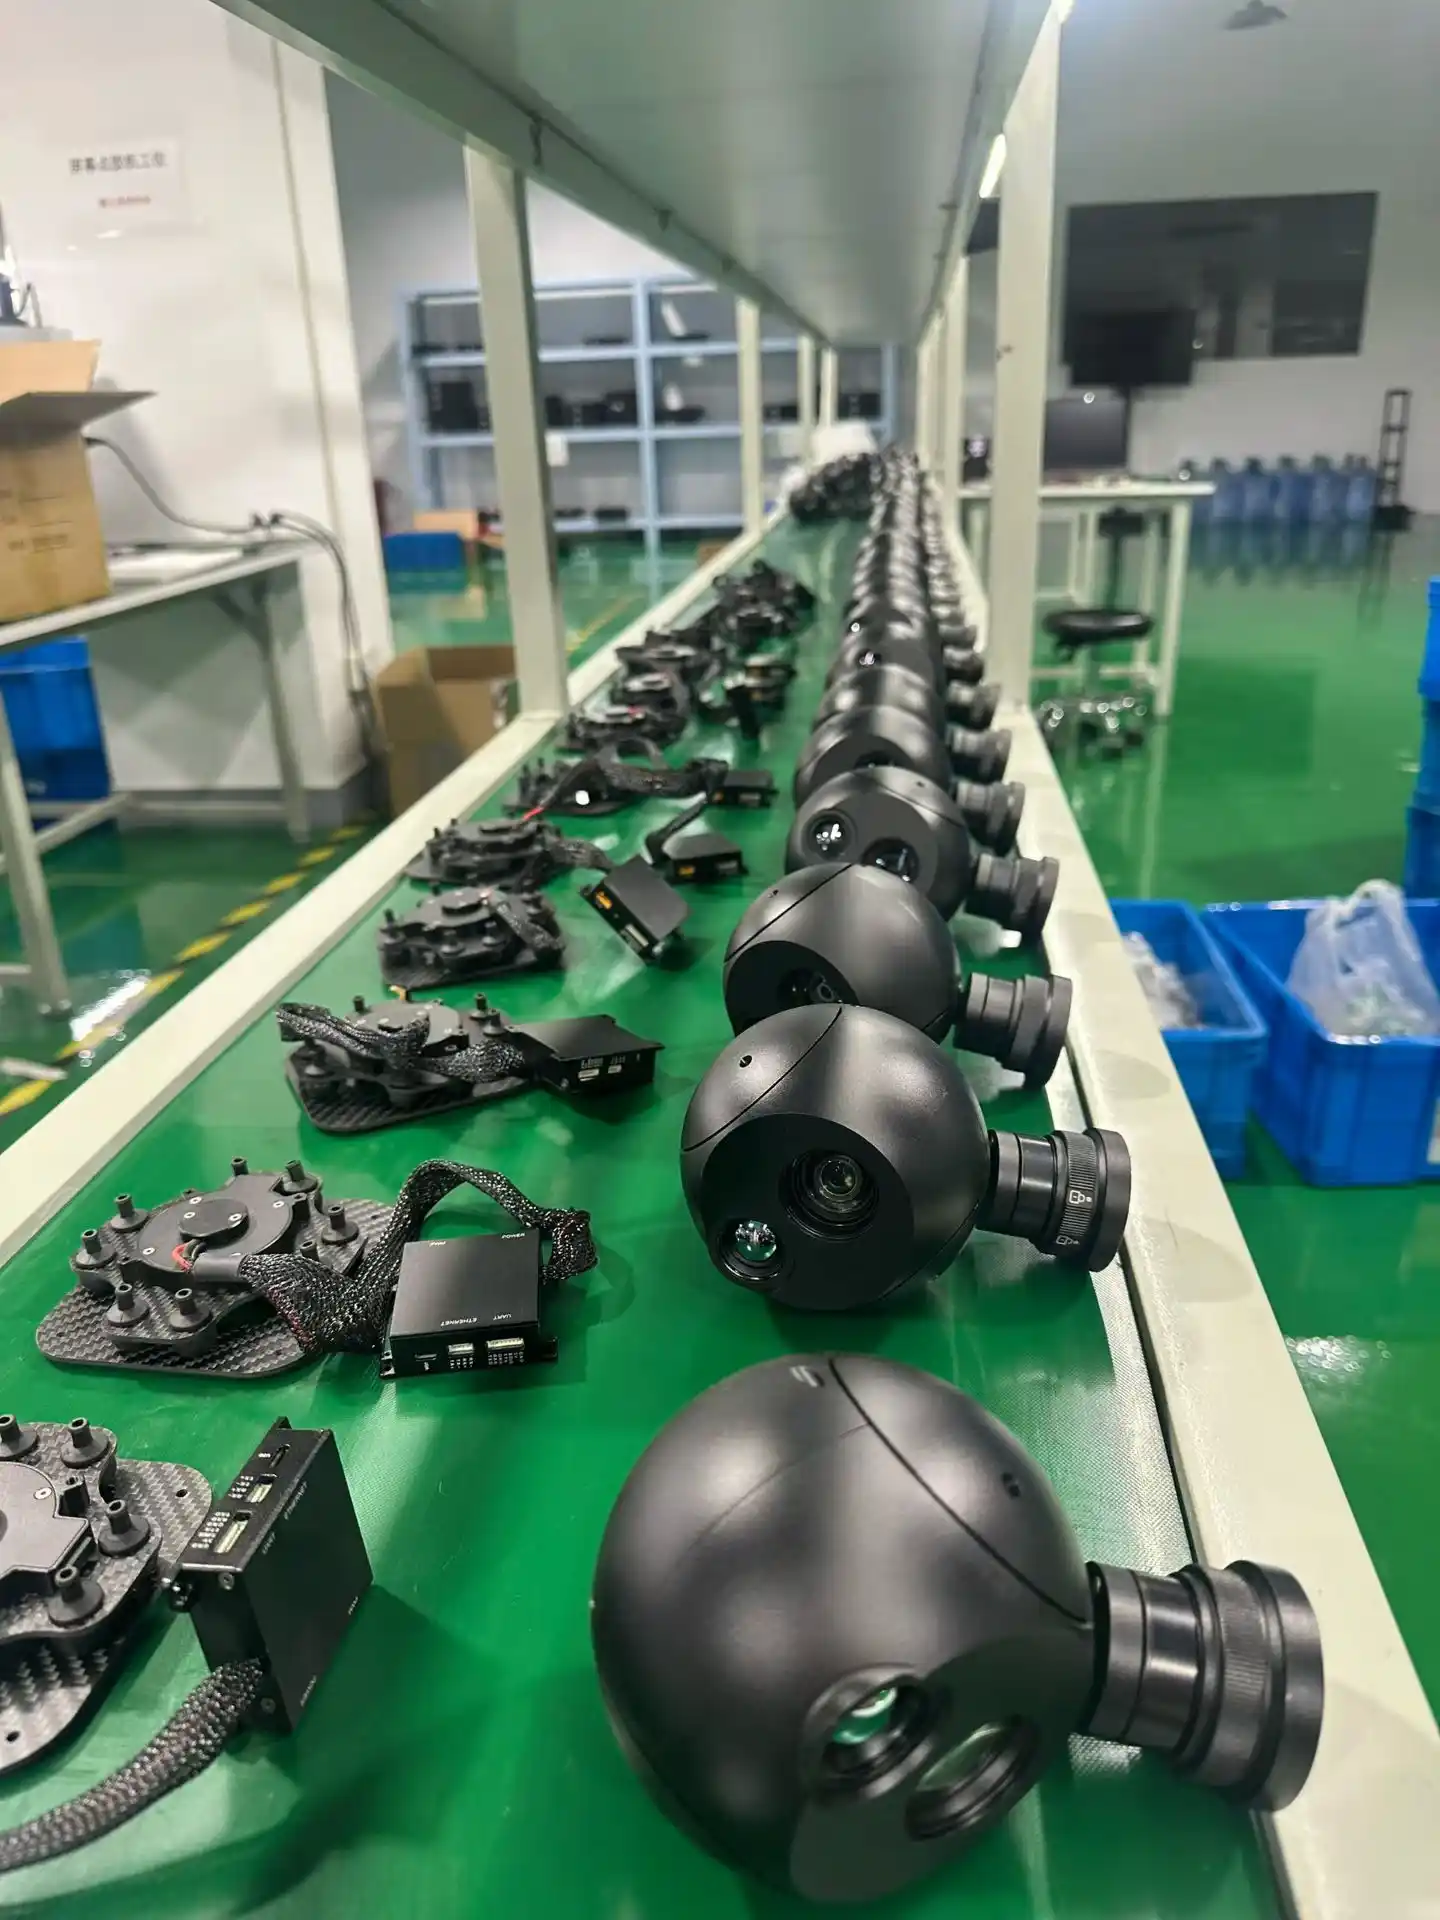
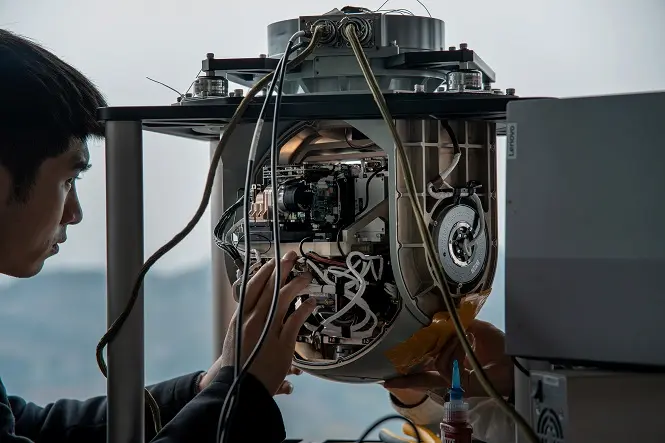
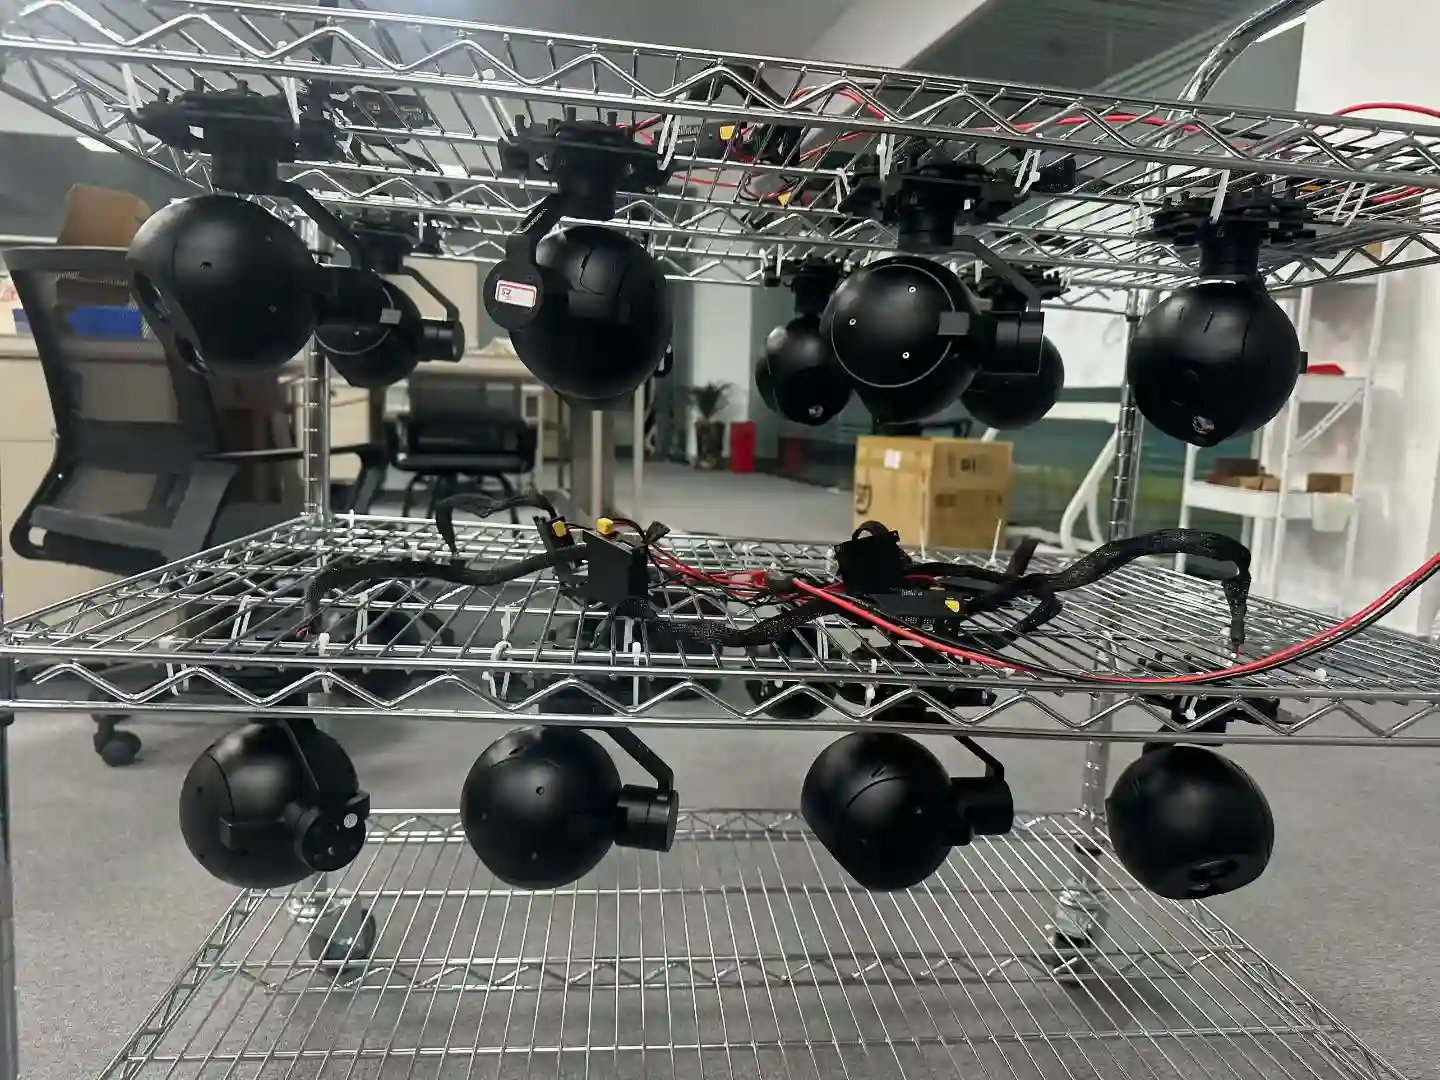
Optics, servo hardware, stabilisation firmware and the AI tracking module are developed in house, and every unit is assembled, calibrated and environmentally tested on our own line before it ships.
Request a quotation for the HQ-125S
Tell us the platform, the range you need to identify and how many units you are planning. Every configuration is quoted individually, so you get a written price against your own requirement rather than a list figure that does not fit it. We answer within one working day.
Explore all product categories
Nine routes into the range: by stabilisation, by sensor set, or by payload class. Each category page compares the models and links to the full specification.
15 models · 240 g – 5 kg
Gimbal Cameras
Two- and three-axis stabilised heads with EO, thermal and laser options.
View category →
3 models · 240 – 500 g
2-Axis Gimbal Cameras
The lightest HQ heads: fixed or dual-FOV optics on a compact two-axis mount.
View category →
12 models · 400 g – 5 kg
3-Axis Gimbal Cameras
Roll-stabilised heads with longer zoom ranges and heavier payload capacity.
View category →
8 models · 1.6 – 10 kg
EO/IR Pod Systems
Larger multi-sensor pods with 30x–55x zoom, thermal imaging and laser ranging to 15 km.
View category →
4 models · 2.5 – 22 kg
Laser Designator Pods
Targeting pods that add 1064 nm designation to the same imaging and stabilisation architecture.
View category →
Sensor guide
Thermal Cameras
Detector, lens and range: how uncooled LWIR payloads are specified for UAVs.
View category →
Sensor guide
Infrared Cameras
How to match an IR detector, lens and interface before choosing a gimbal.
View category →
Sensor guide
EO Cameras
Visible-channel sensors, zoom lenses and the resolution needed at range.
View category →
Sensor guide
EO/IR Cameras
Boresight, sensor pairing and the trade-offs of a dual-sensor head.
View category →