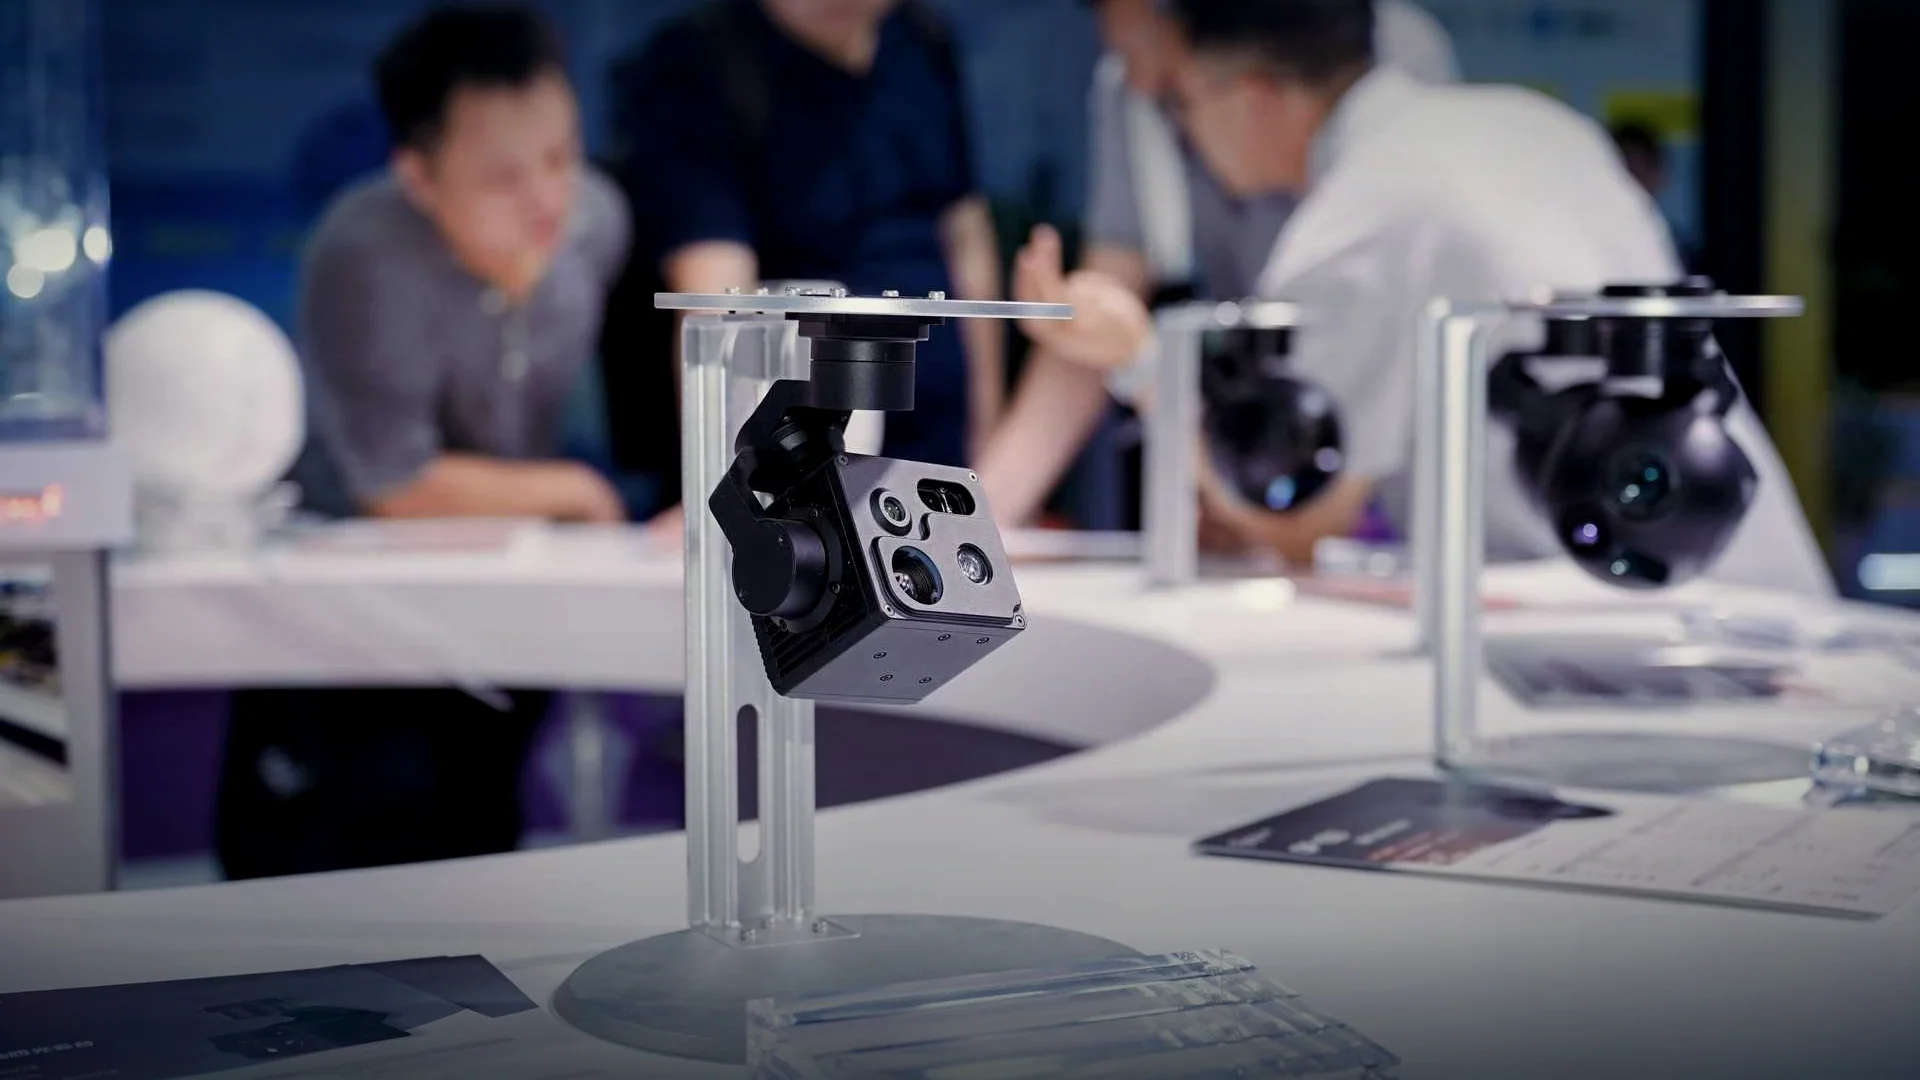
HQ-125TB three-axis gimbal camera with 3 km LRF
A three-axis gimbal camera for multirotors, fixed-wing aircraft and small helicopters. Balanced mid-range turret: 30x zoom, a long thermal lens and 3 km ranging.
- Weight 1.2 kg
- Three-axis stabilised
- EO 1920 × 1080
- Thermal 640 × 512
- LRF 15 m – 3 km (± 1 m)
- AI detection & tracking
- CE / RoHS documentation available on request
- Export compliance statement available on request
- Calibration and test report supplied with every unit
What the HQ-125TB is
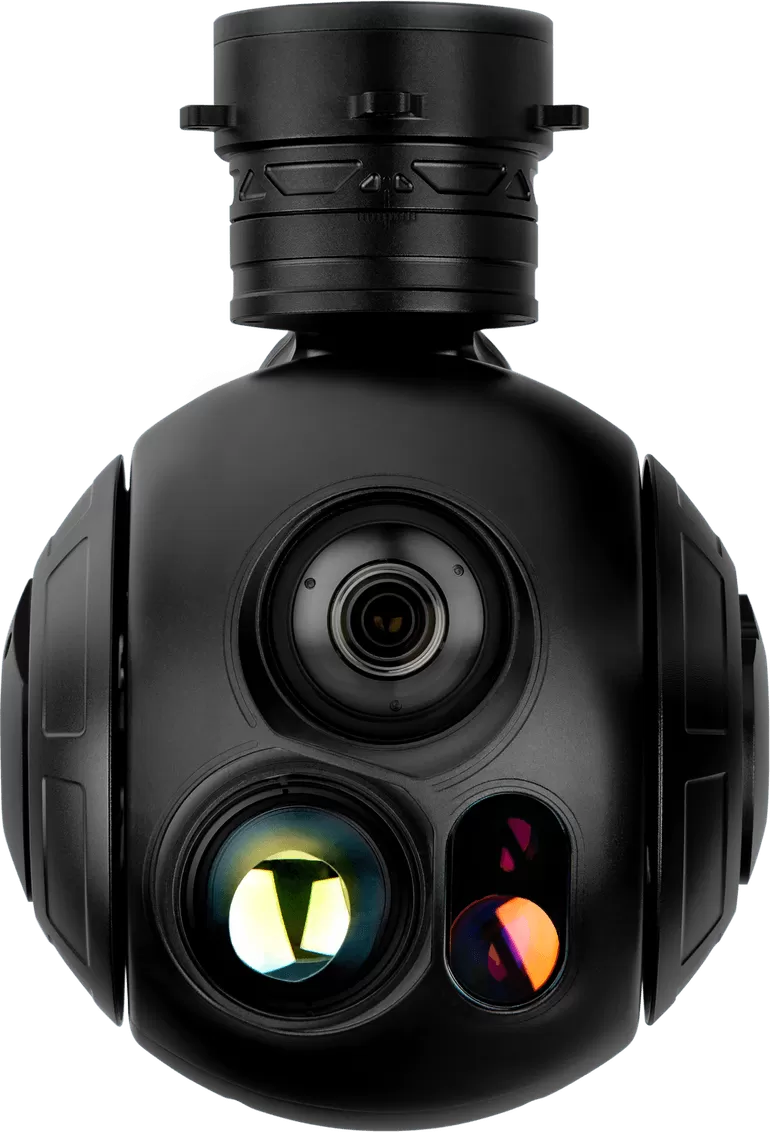
Configured as EO plus IR plus LRF, the HQ-125TB sits at 1.2 kg with a Φ125 × 180 mm envelope, which places it with multirotors, fixed-wing aircraft and small helicopters. Balanced mid-range turret: 30x zoom, a long thermal lens and 3 km ranging.
Core capabilities
The features that decide whether imagery is usable in the air, in the order an integrator usually checks them.
- Gyro-stabilised line of sight
Direct-drive brushless axes with high-resolution encoding hold the line of sight to ≤ 100 μrad (1σ), and the stabilisation loop reacts at ≥ 60°/s angular velocity so imagery stays steady in turbulence and rotor wash.
- Continuous optical zoom
The visible channel is 1920 × 1080, 30x zoom 4.3 – 129 mm. Continuous zoom keeps a wide search field and a tight identification field available without changing lenses, with autofocus and electronic image stabilisation at sub-pixel level.
- Uncooled thermal channel
640 × 512, 35 mm fixed, long-wave infrared with NETD ≤ 40 mK, boresighted to the visible channel so both sensors point at the same target with no re-alignment in flight.
- Laser rangefinding
The rangefinder measures 15 m – 3 km (± 1 m) at an eye-safe 1535 nm, which turns video into a distance measurement and feeds the target coordinate calculation.
- Onboard AI detection
Person, vehicle, vessel and aircraft detection runs on the payload itself, with no dependency on the data link and no frames sent to a ground station for processing.
- Multi-target tracking
Lock and follow up to 20 targets at once, with anti-occlusion logic that re-acquires a target after it passes behind terrain, a mast or another object.
Stabilisation and mechanical design
Three axes, direct drive
Yaw, pitch and roll are each driven directly by brushless motors with high-resolution encoding, so there is no gear backlash or step noise in the video. The loop is specified at ≥ 60°/s angular velocity and holds the line of sight to ≤ 100 μrad (1σ).
1.2 kg in Φ125 × 180 mm
The complete head weighs 1.2 kg and measures Φ125 × 180 mm, with 11–28 VDC input and power consumption of 20 W / 50 W. That envelope lets multirotors, fixed-wing aircraft and small helicopters carry the payload without a bespoke mount.
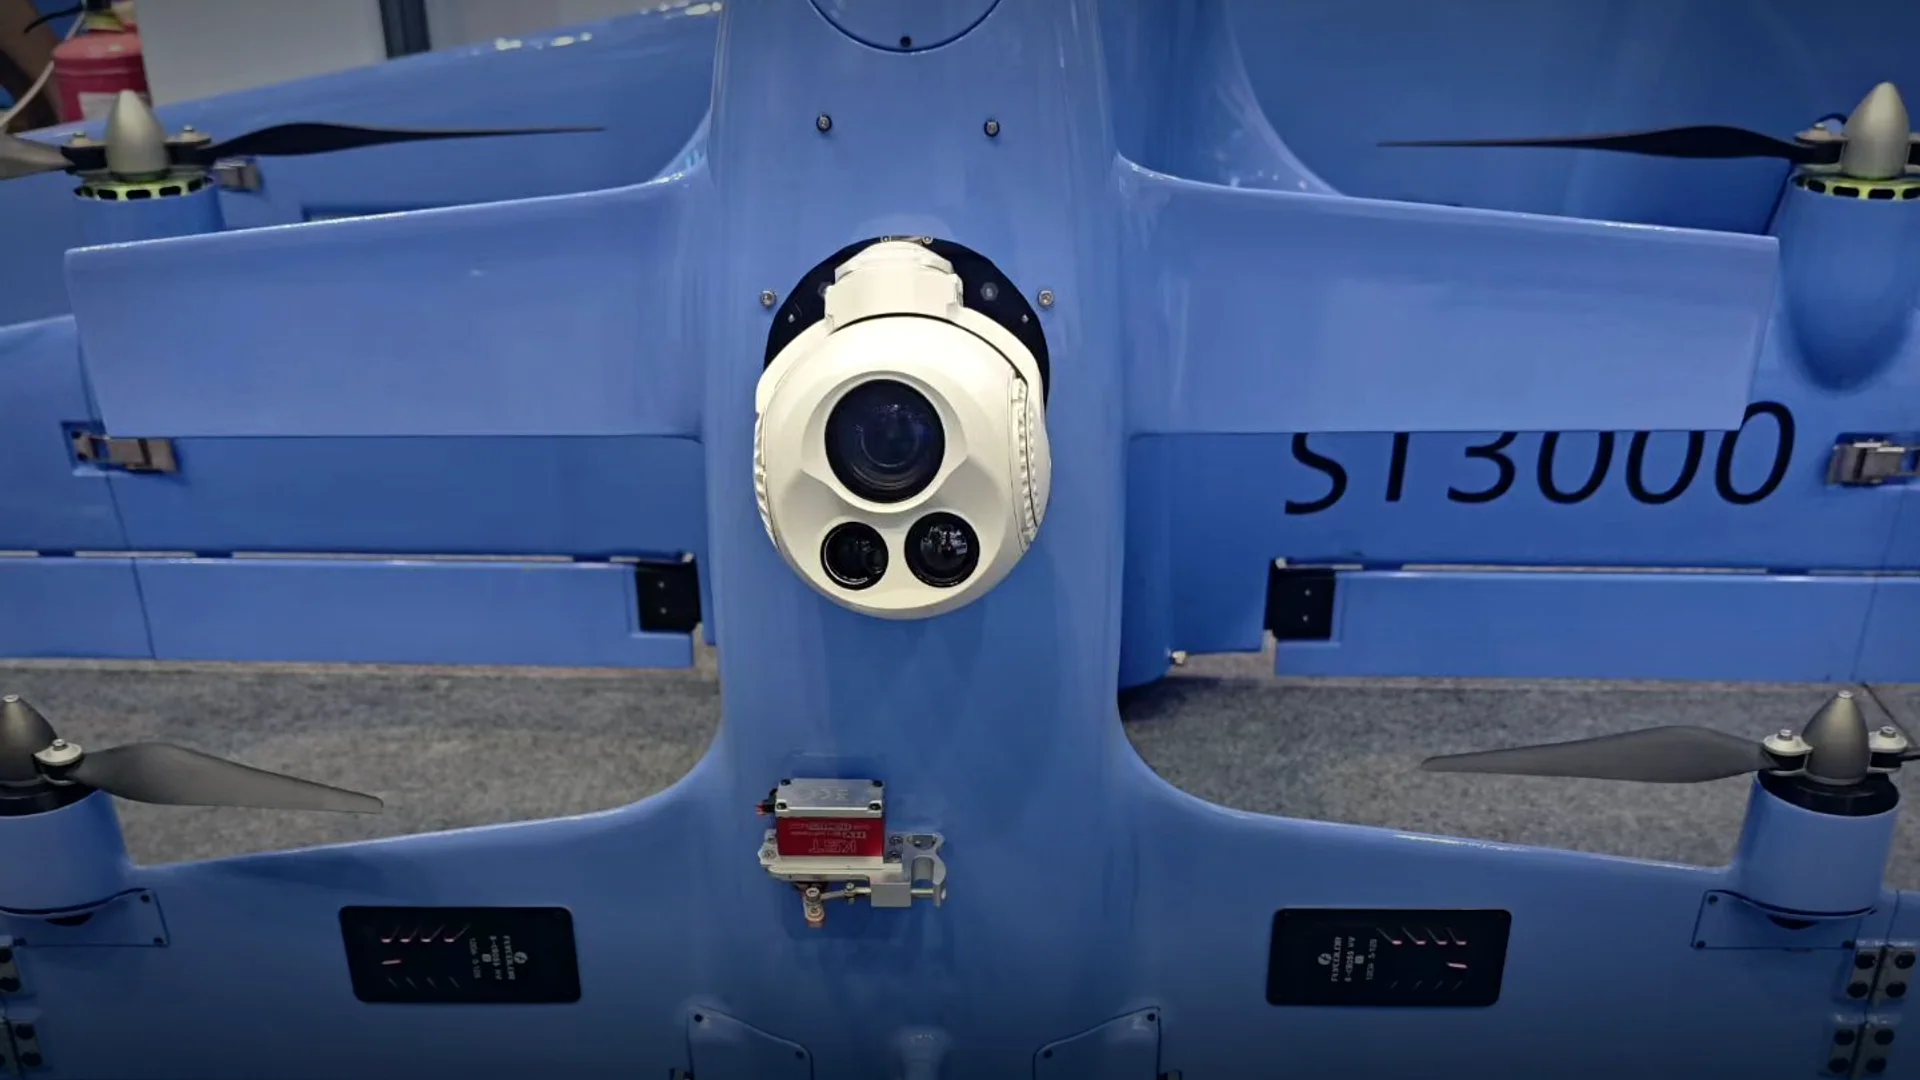
On the aircraft
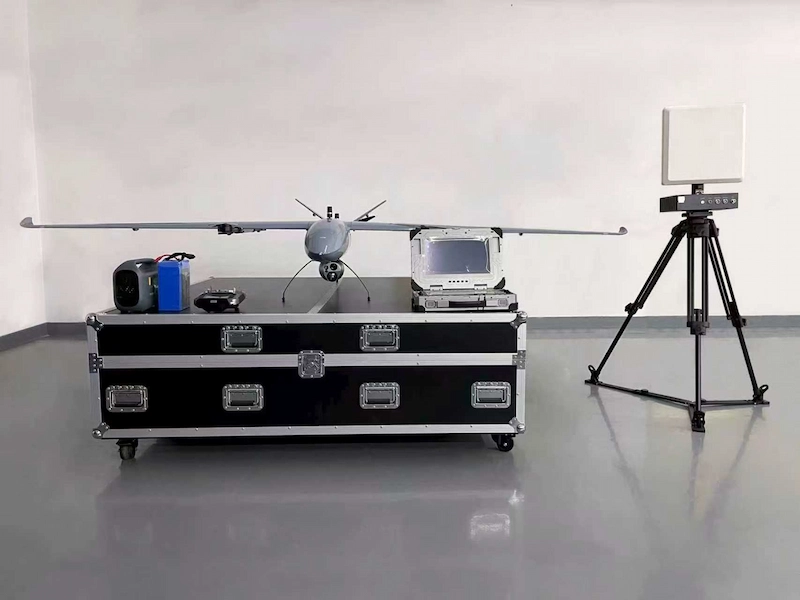
Mounting, cable routing and vibration isolation are agreed with the platform integrator, so the payload drops into an existing airframe interface instead of needing a bespoke mount.
Multi-sensor payload
Configured as EO plus IR plus LRF. Each channel is boresighted to the others, so one target sits in the same place on every screen.
EO / visible
1920 × 1080, 30x zoom 4.3 – 129 mm
Detection 6 km person / 15 km vehicle.
Thermal / IR
640 × 512, 35 mm fixed
Detection 1 km person / 4.6 km vehicle.
Laser rangefinder
15 m – 3 km (± 1 m)
Eye-safe 1535 nm, feeding target coordinates.
Channel detail
A sensor specification on its own rarely answers the operational question, so each channel is described here with the distance it actually supports.
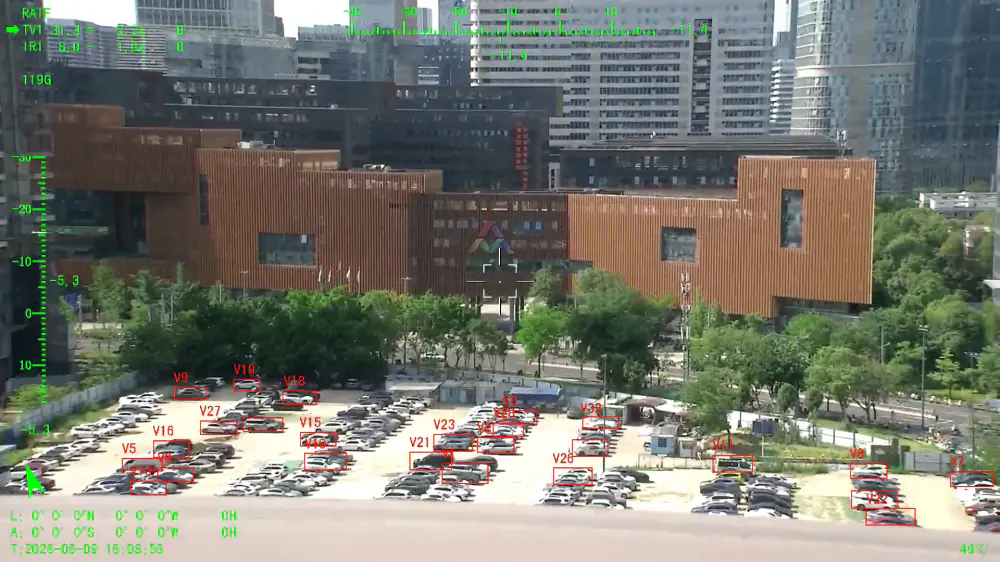
EO / visible
The visible channel is specified at 1920 × 1080, 30x zoom 4.3 – 129 mm. Detection distances for the visible channel are quoted at 6 km person / 15 km vehicle using the standard 1.7 m person and 2.3 m vehicle targets; recognition and identification distances are shorter and appear in the datasheet.
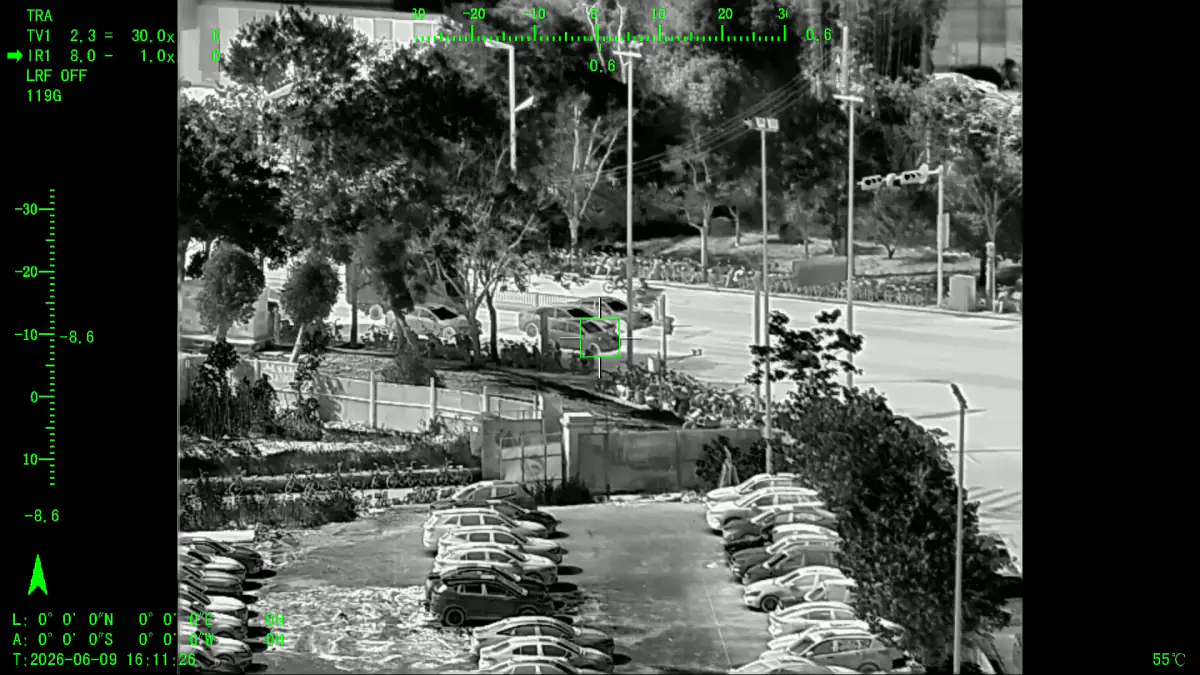
Thermal / IR
The thermal channel is 640 × 512, 35 mm fixed, uncooled long-wave infrared with NETD ≤ 40 mK. Thermal detection is quoted at 1 km person / 4.6 km vehicle. Performance does not depend on daylight, which is what makes the channel useful for night operations and for scenes obscured by smoke or dust.
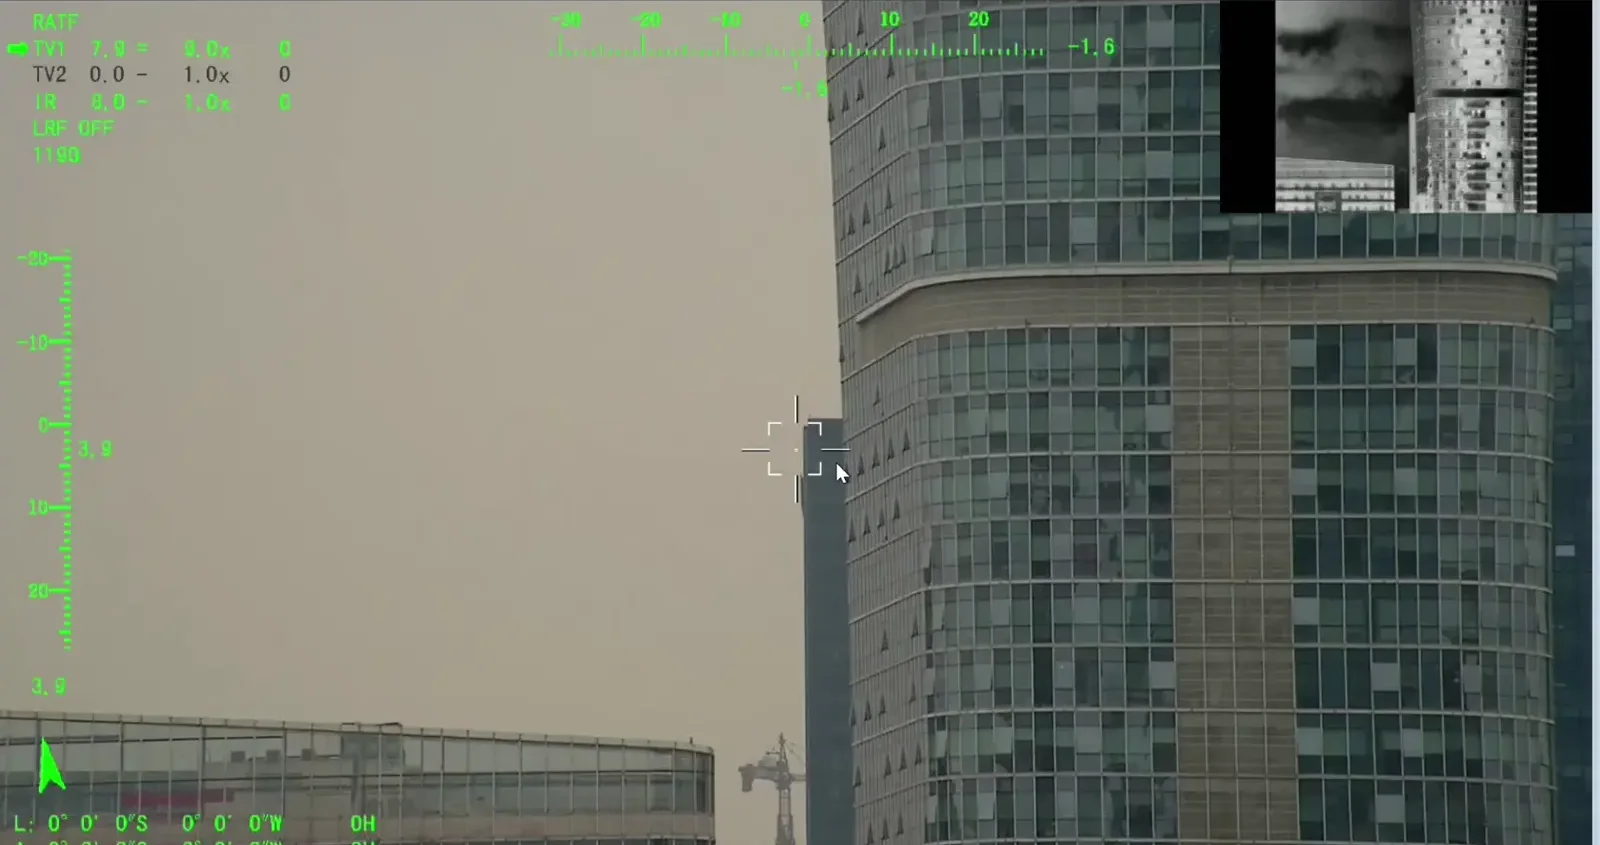
Laser rangefinder
The laser rangefinder measures 15 m – 3 km (± 1 m) at an eye-safe 1535 nm. Range readings feed the target coordinate calculation, so the ground station receives a georeferenced position instead of a range bar in the video.
Detection and tracking at the edge
Onboard AI module
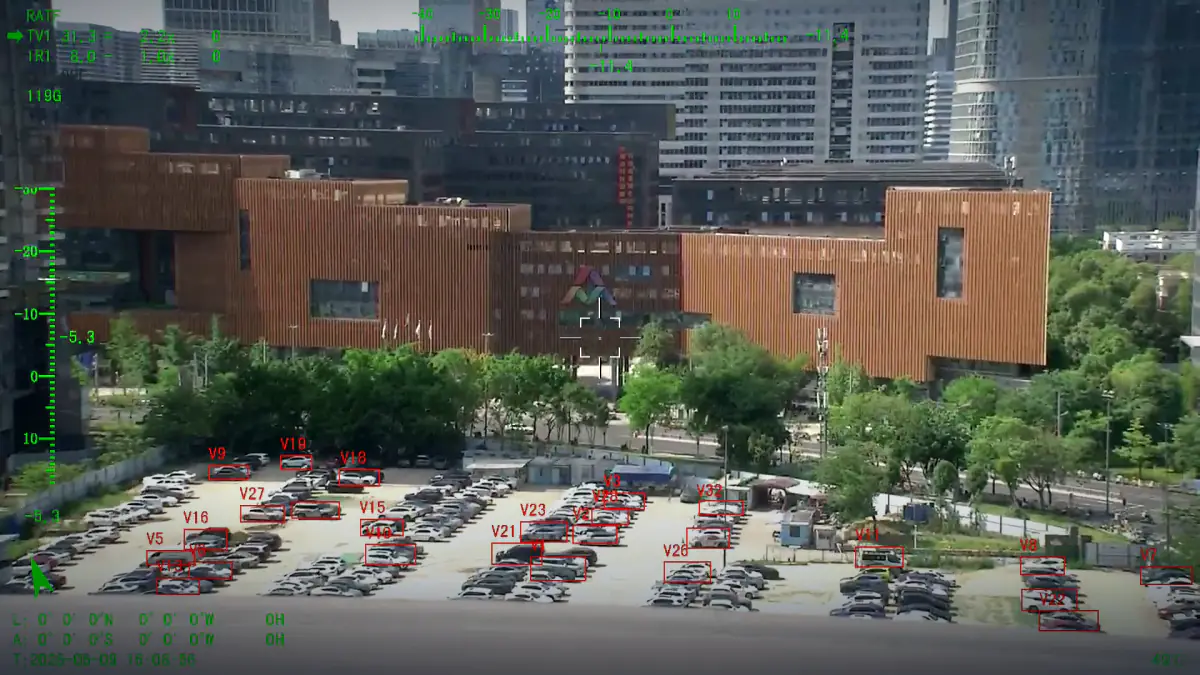
The onboard module detects people, vehicles, vessels and aircraft and hands a target to the tracker for a stable lock. Because processing happens at the edge, latency is low and nothing leaves the aircraft unless you choose to transmit it.
What that means in the air
The operator sees a boxed target and a lock that survives occlusion rather than a raw feed. Because the module is common across the family, tracking behaviour does not change when the payload changes.
Tracking demonstration
Targets are boxed automatically as they appear, and the lock is held on the selected target even when it passes behind an obstruction.
Integration
One control protocol across the family
Every head in the range speaks the same control set, so moving from a two-axis to a three-axis payload, or adding a laser rangefinder, does not change the aircraft-side integration. The protocol document and video pipeline notes are supplied with the first unit.
Video, control and power
Video is carried as Ethernet in H.264 or H.265. The gimbal is controlled over RS-422, RS-232 or TTL with SBUS and MAVLink supported on the aircraft side, and power input is 11–28 VDC. Recording is handled on board, so the file exists even if the link drops.
Interface protocol document, video pipeline description and outline drawing are supplied with the first unit — ask the engineering team if you need them earlier for evaluation.
Full specifications
| Model | HQ-125TB |
| Series | Gimbal Camera Series (HQ series) |
| Stabilisation | Three-axis gyro-stabilised, ≤ 100 μrad |
| Sensor configuration | EO + IR + LRF |
| Visible channel | 1920 × 1080, 30x zoom 4.3 – 129 mm |
| Thermal channel | 640 × 512, 35 mm fixed |
| Laser rangefinder | 15 m – 3 km (± 1 m) |
| Weight | ≤1.2 kg |
| Dimensions | ≤Φ125 × 180 mm |
| Power consumption | 20 W / 50 W |
| Detection (EO) | 6 km person / 15 km vehicle |
| Detection (IR) | 1 km person / 4.6 km vehicle |
Detection distances follow the standard 1.7 m person / 2.3 m vehicle convention. Rows marked as shared are common across the HQ series.
Shared across the HQ series
- Video output: Ethernet, H.264 / H.265
- Gimbal control: RS-422 / RS-232 / TTL, SBUS, MAVLink
- Input voltage: 11–28 VDC
- Operating temperature: −20 °C to +60 °C
- Sealing: Sealed housing for dust, wind and rotor wash
- Recording: On-board recording, imagery retained if the link drops
- AI module: Onboard detection, classification and multi-target tracking
- Mounting: Quick-release interface, adapters available for OEM airframes
Three-view outline drawing with connector pinout, available on request.
Mounting, interfaces and environment
Airframe integration is the part of a payload programme that is easiest to get wrong, so these are the numbers engineers ask for first. Everything below applies to the HQ-125TB.
Mechanical interface
The head mounts on a quick-release interface with a vibration-isolated gimbal base, and adapter plates are available for OEM airframes that do not share our bolt pattern. Mass and envelope are the catalogue limits for this head, so the aircraft-side budget can be checked before a prototype is built.
Electrical and data interface
Power, control and video are separated so the head can be flown from most autopilots: 11–28 VDC input, serial control on RS-422 / RS-232 / TTL, and video over Ethernet. On-board recording keeps the imagery even if the downlink drops.
| Payload mass | ≤1.2 kg |
| Envelope | ≤Φ125 × 180 mm |
| Power consumption | 20 W / 50 W |
| Input voltage | 11–28 VDC |
| Data interfaces | Serial (RS-422 / RS-232 / TTL), Ethernet, SBUS |
| Video output | Ethernet, 100 Mbps, H.264 / H.265 |
| On-board storage | Up to 128 GB |
| Operating temperature | −20 °C to +60 °C |
| Storage temperature | −40 °C to +70 °C |
| Mounting | Quick-release interface, adapter plates for OEM airframes |
| Sealing | Sealed housing for dust, wind and rotor wash |
Input voltage, data interfaces, video output, temperature limits and on-board storage are common across the range. The released three-view drawing with the connector pinout is supplied with the datasheet — ask the engineering team if you need it for an airframe review before quotation.
Where the HQ-125TB is used
Three mission profiles that match this weight class and sensor set.
- Persistent surveillance
A stabilised multi-sensor head on a long-endurance aircraft keeps one target under observation through weather, day and night.
- Camera on helicopter
Vibration isolation matters more on a rotorcraft, and the stabilisation loop is specified for exactly this environment.
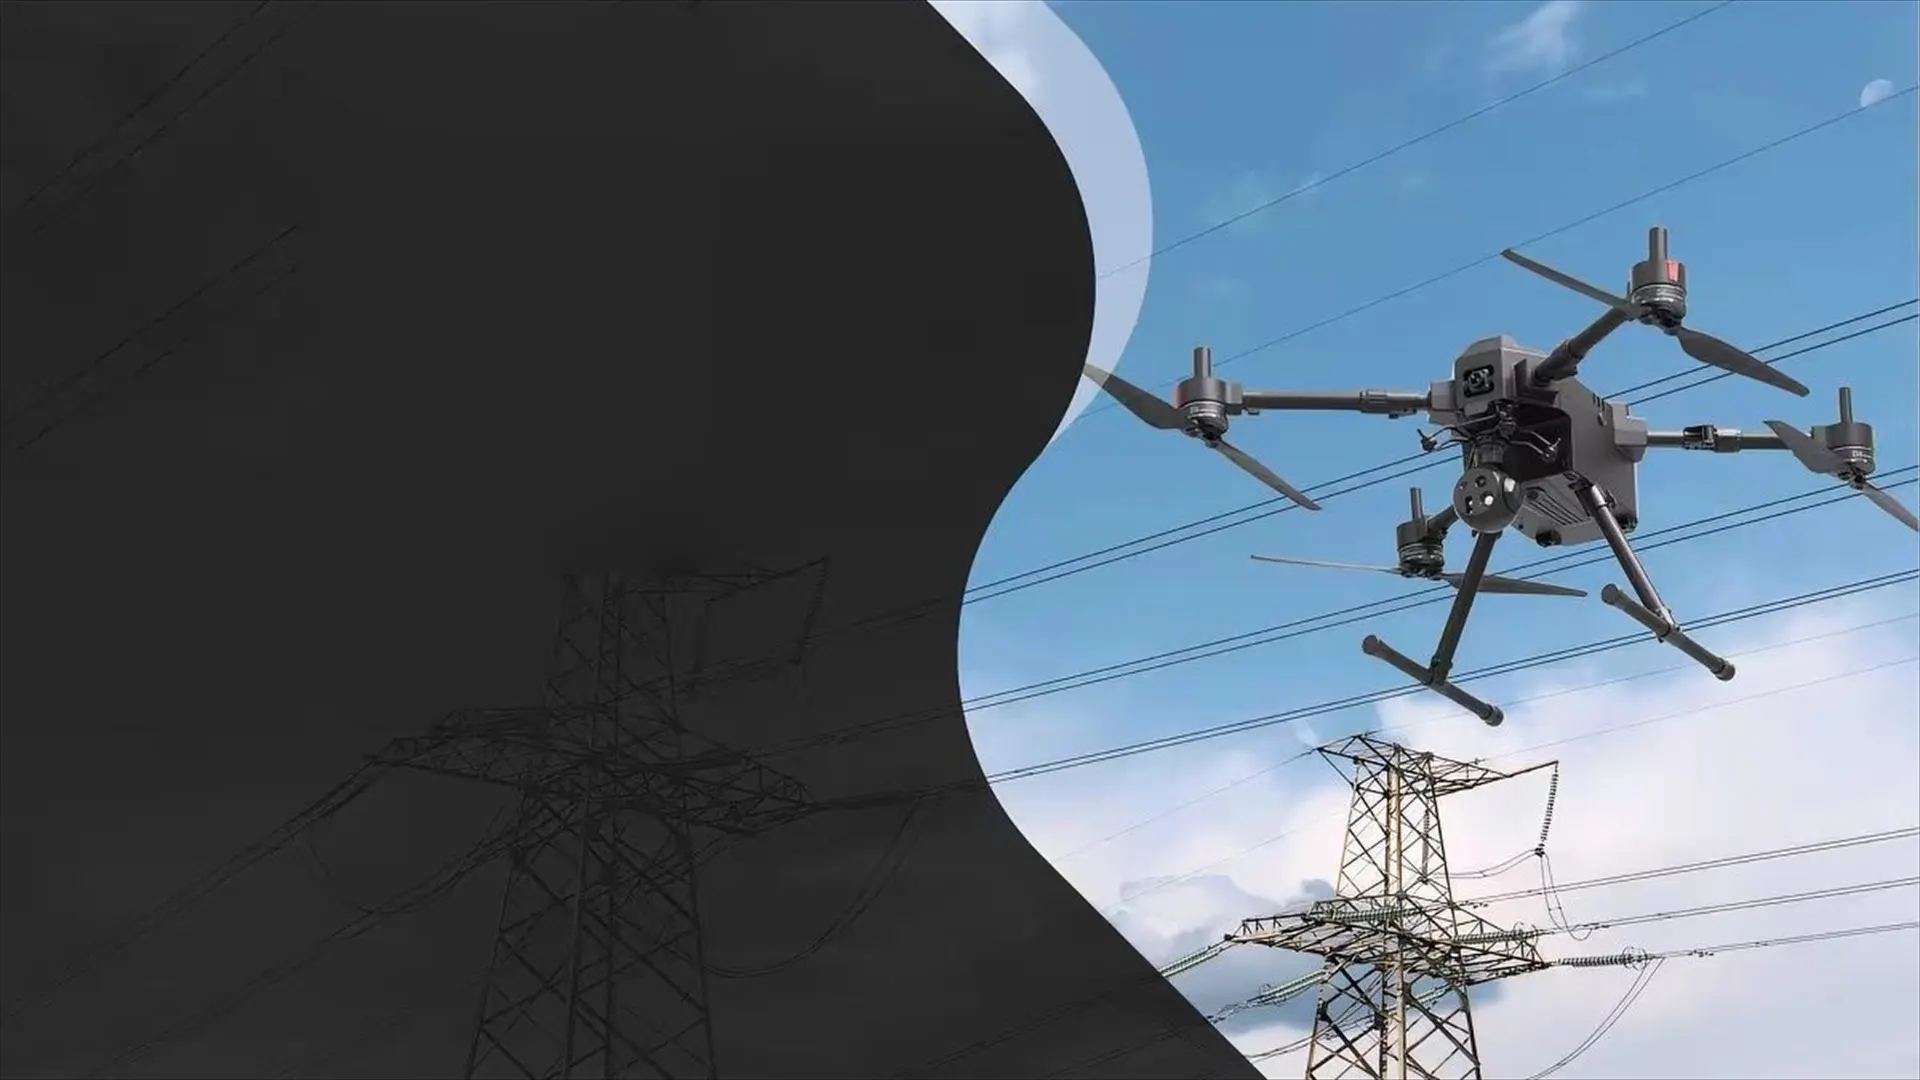
- Corridor and route survey
Thermal and visible imagery in one pass, georeferenced by the rangefinder, shortens the time between flight and report.
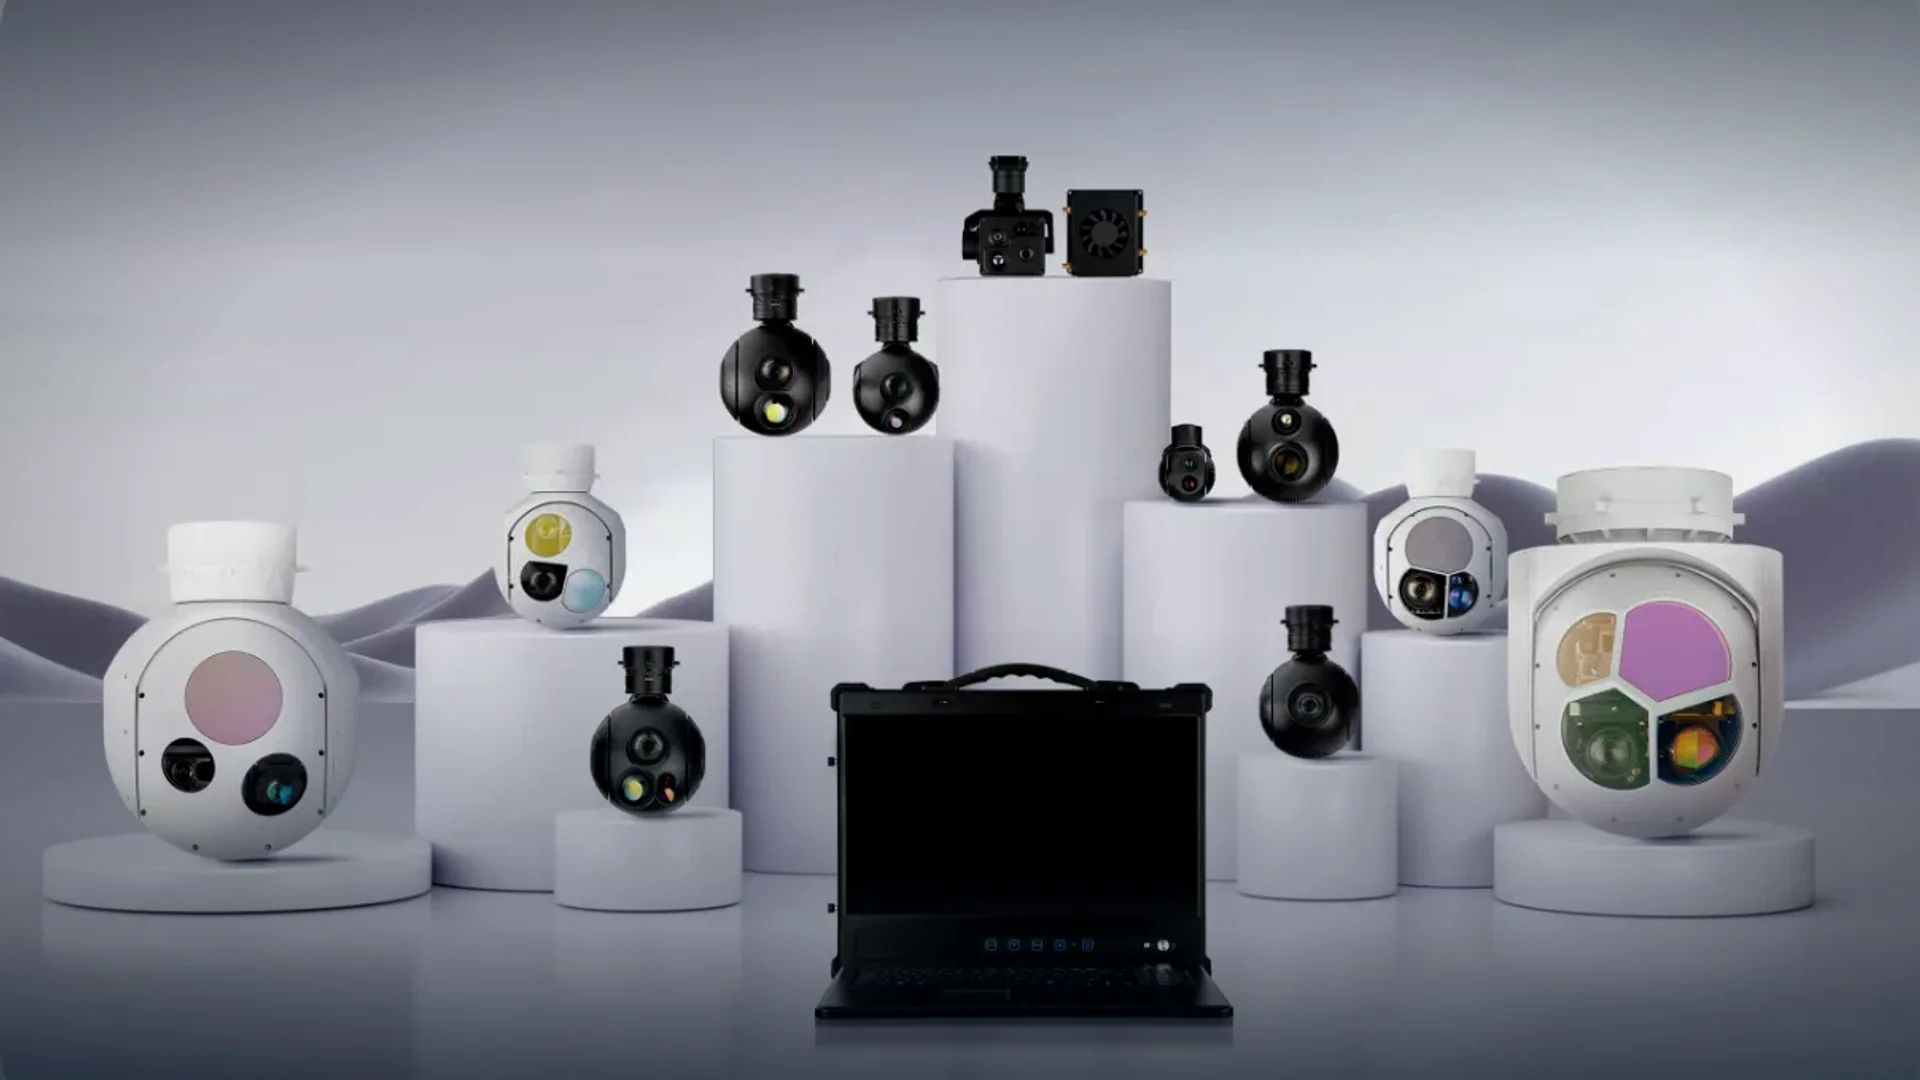
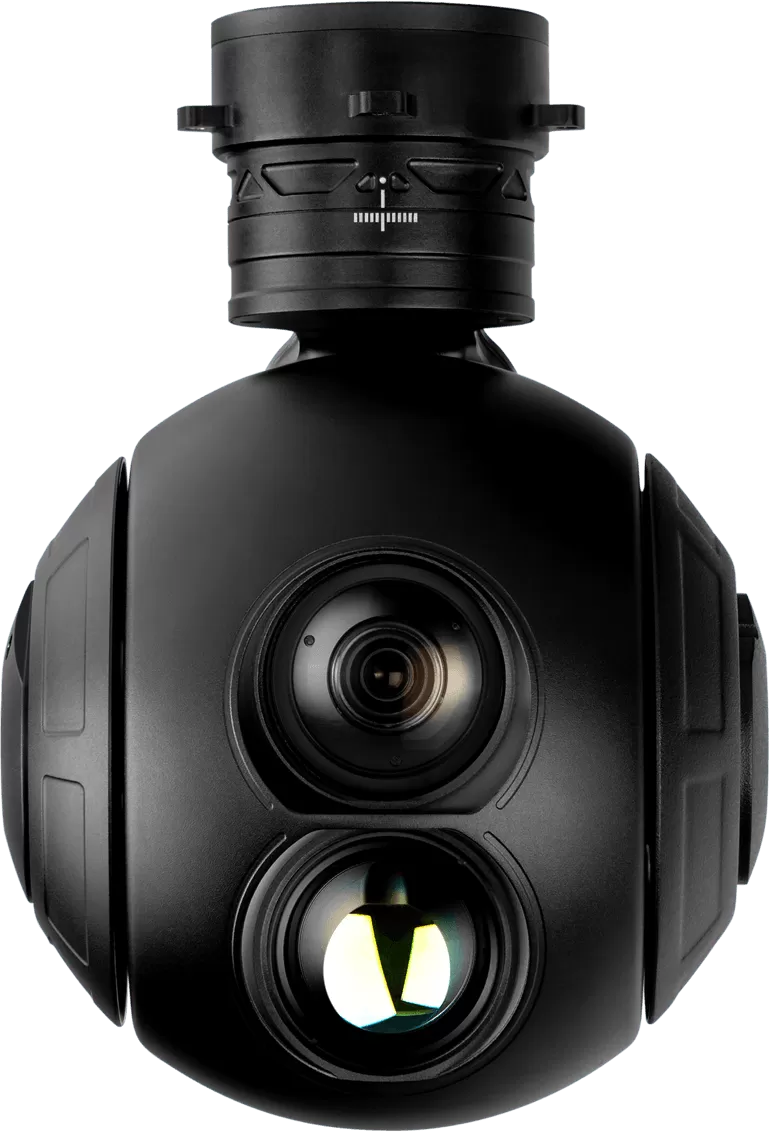
Other heads in the range
Every model shares the same control protocol, video pipeline and AI module, so moving between them does not change the aircraft-side integration.
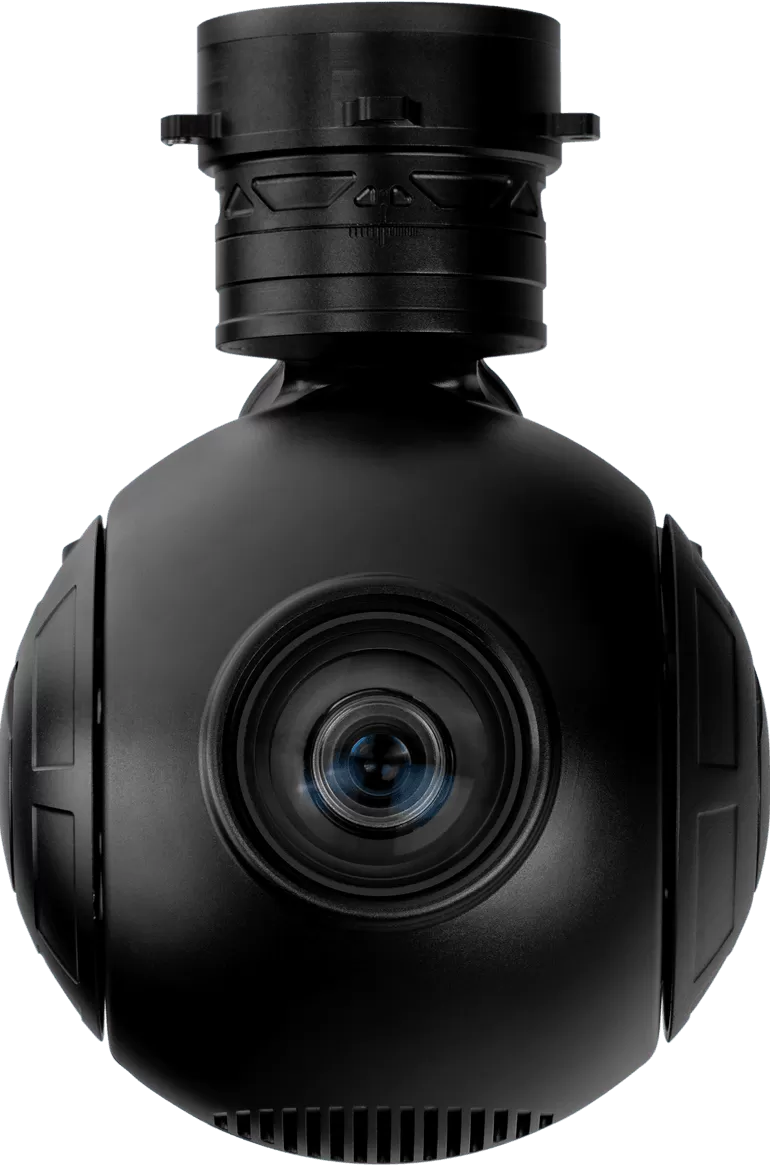
HQ series · 3-axis · EO + IR
HQ-125DB UAV Camera Gimbal ODM
The longer 35 mm thermal lens paired with 30x zoom, without the rangefinder.
- Weight
- ≤1.1 kg
- EO
- 1920 × 1080
- IR
- 640 × 512
HQ series · 3-axis · EO
HQ-115S Drone Camera Gimbal Direct Factory
A 40x daylight optic alone, for daylight-only surveillance where the weight budget rules out a thermal channel.
- Weight
- ≤1 kg
- EO
- 1920 × 1080
- IR
- —
HQ series · 3-axis · EO + IR
HQ-115D UAV Gimbal Camera OEM
30x zoom and thermal imaging on a one-kilogram head with no ranging requirement.
- Weight
- ≤1 kg
- EO
- 1920 × 1080
- IR
- 640 × 512
Questions engineers ask about the HQ-125TB
Which figures are shared across the HQ series?
Control protocol, video format, recording, input voltage, temperature range and sealing are common across the family, so one aircraft-side integration covers a two-axis head and a larger turret alike. Confirm the exact figures against the datasheet.
Which sensors does the HQ-125TB carry?
The configuration is EO plus IR plus LRF: a visible channel at 1920 × 1080, 30x zoom 4.3 – 129 mm, a thermal channel at 640 × 512, 35 mm fixed, a laser rangefinder measuring 15 m – 3 km (± 1 m).
How is the HQ-125TB integrated with the flight controller?
Video is Ethernet in H.264 or H.265, gimbal control runs over RS-422, RS-232 or TTL, and SBUS and MAVLink are supported on the aircraft side, with 11–28 VDC power input. The control protocol document is supplied with the first unit.
Can the HQ-125TB be adapted for an OEM programme?
Optics, servo hardware, stabilisation firmware and the AI module are developed in house, so the optical set, laser module, mounting interface and control protocol can be adapted. OEM and ODM projects normally start from an existing head.
What are the order terms for the HQ-125TB?
One unit for a stock configuration, custom builds from 100 units. A head held in stock ships from inventory, so the lead time is transit rather than a production slot; payment is by T/T with the schedule on the quotation, and the warranty is one year from delivery with support from our own engineers online.
Designed and manufactured by HITS
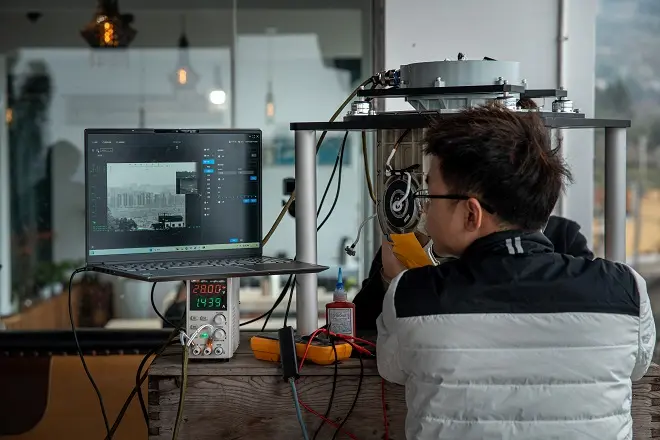
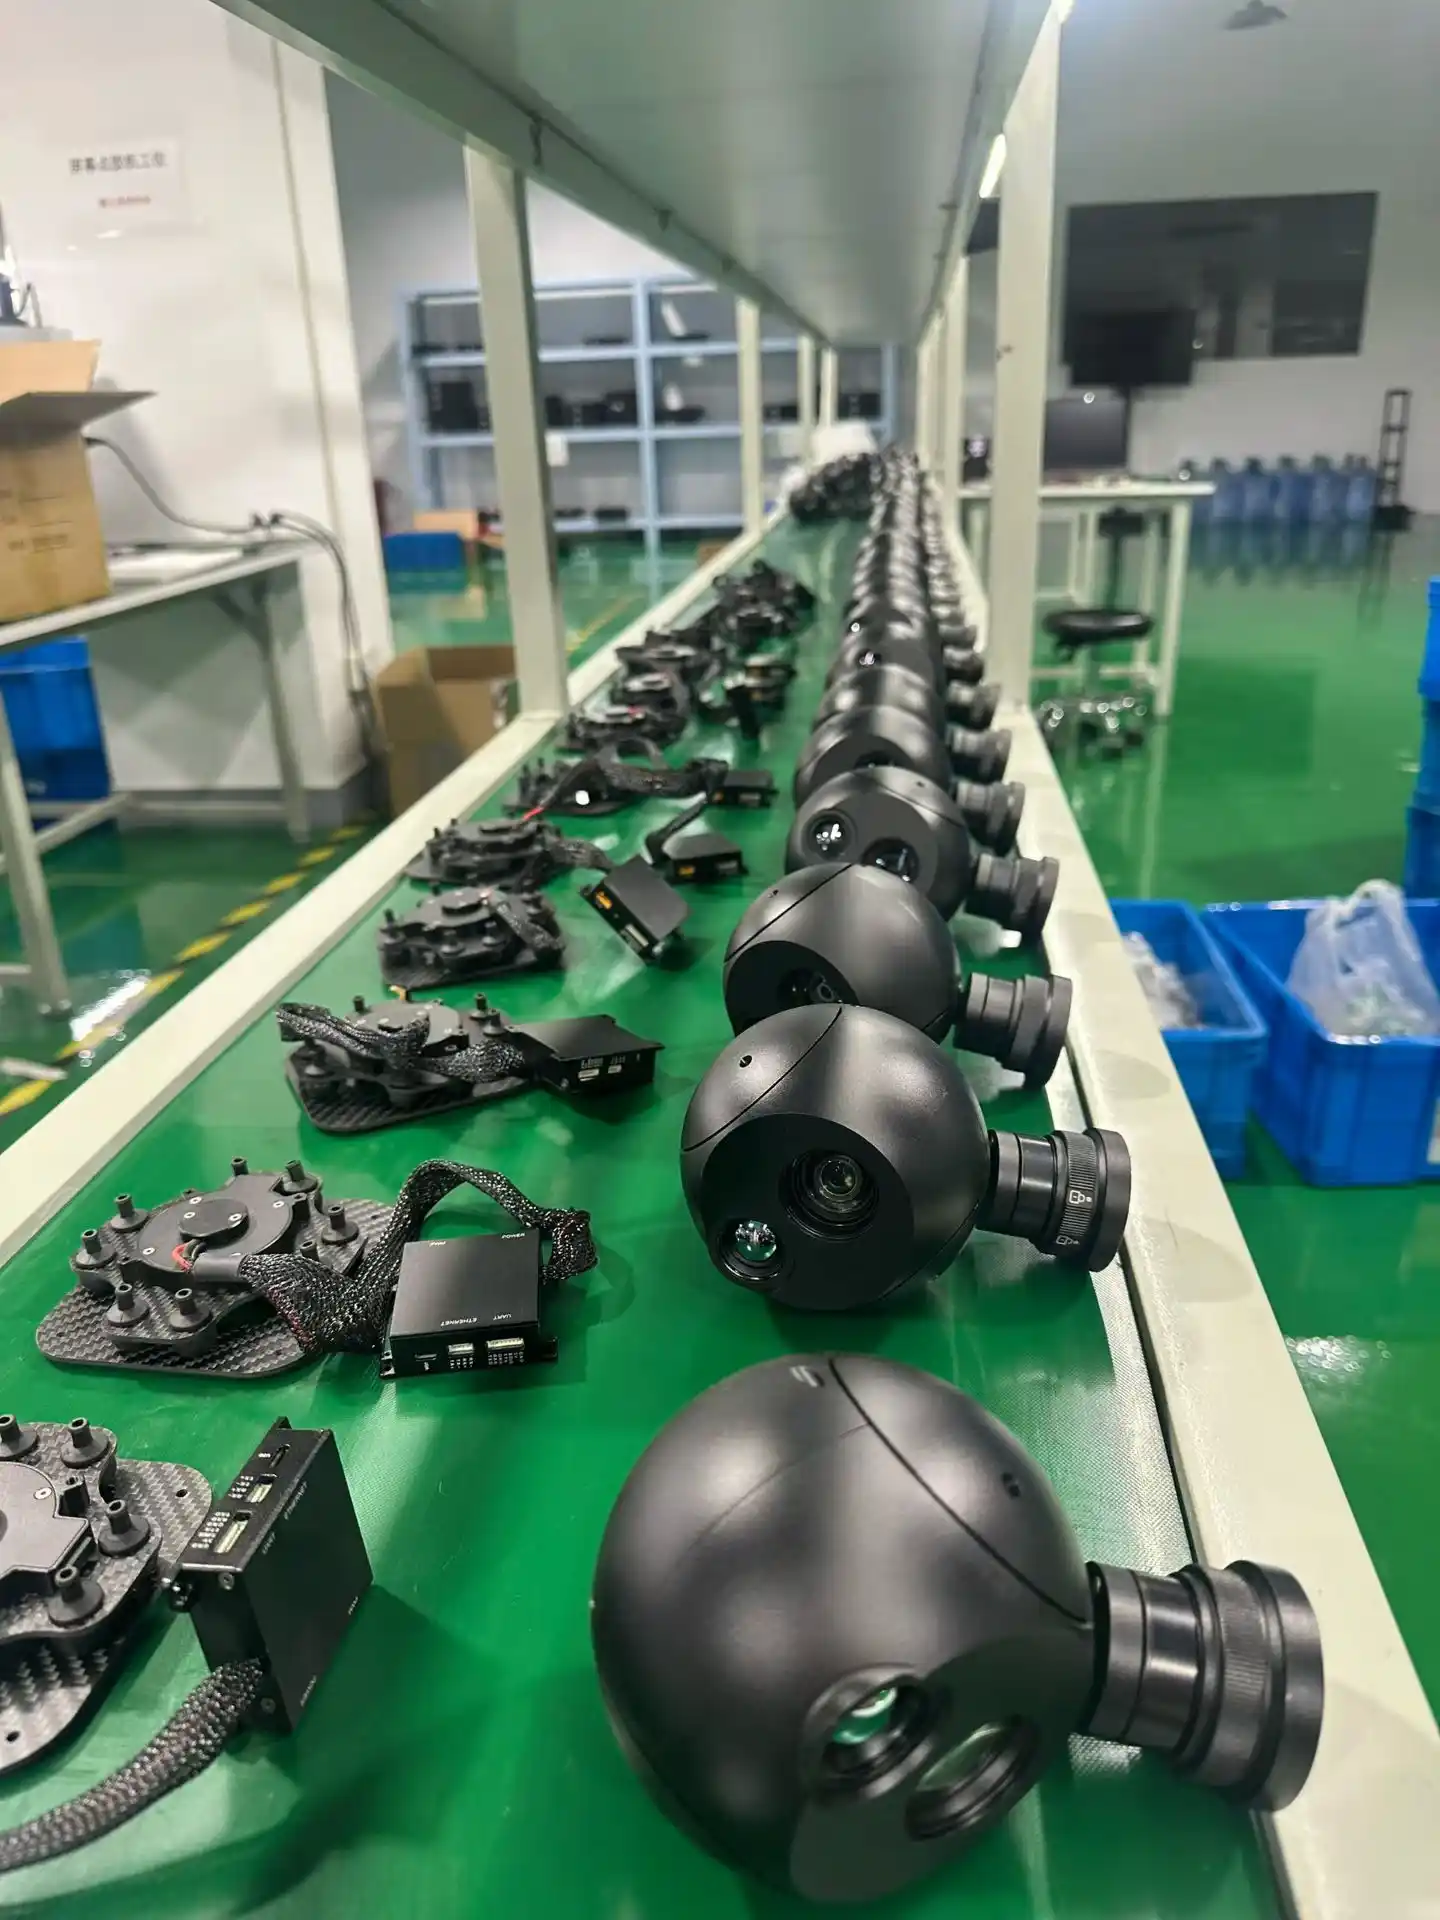
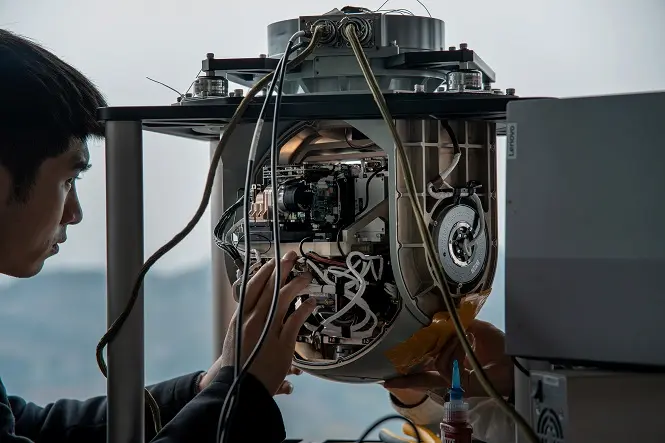
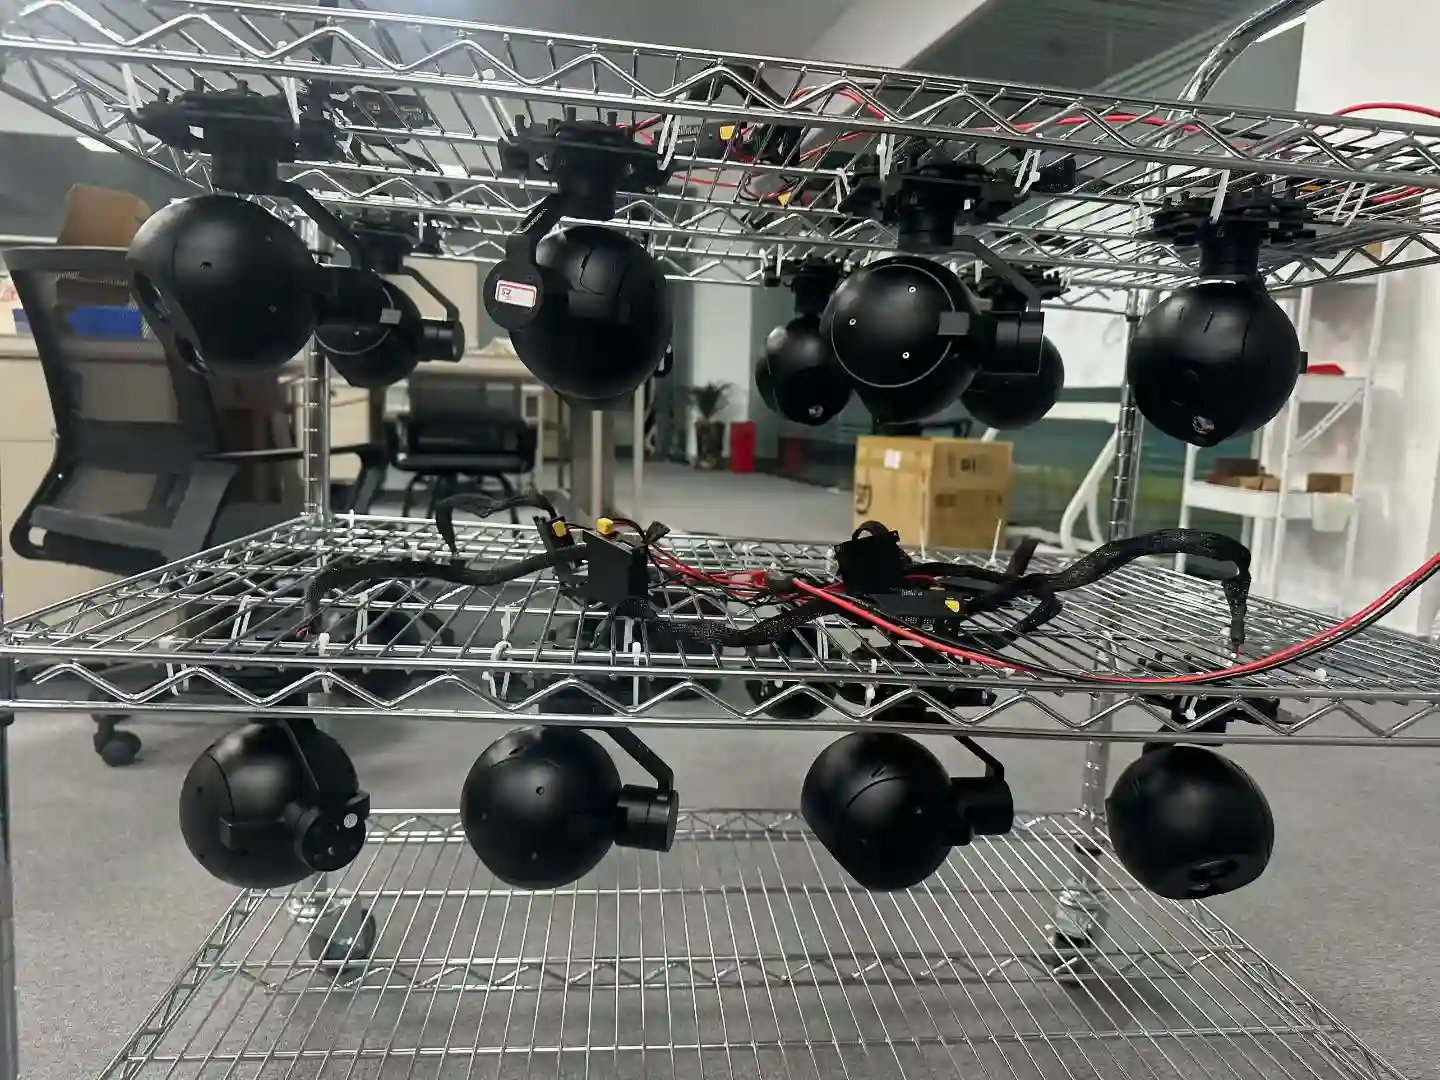
Optics, servo hardware, stabilisation firmware and the AI tracking module are developed in house, and every unit is assembled, calibrated and environmentally tested on our own line before it ships.
Request a quotation for the HQ-125TB
Send the platform, the operating altitude and the identification range you need and we will confirm the configuration. Contact us with your requirements.